
Components
Search component names, models or companies
Showing 221 components models
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Maximum weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
 DexKitDexKit V0 | Carnegie Mellon University | United States | Prototype | Not released | 5 fingers | — | 12 DOF | — | — | — | Not disclosed | 2026-09-12 | |
 Revo 2Revo 2 Basic | BrainCo | China | Commercial | Not disclosed | 5 fingers | — | 11 DOF | 0.38 kg | — | — | Not disclosed | 2026-09-12 | |
 GaoshanGaoshan S1 | Botyard Intelligence | China | Commercial | Not disclosed | — | — | 18 DOF | — | — | — | — | 2026-09-13 | |
 BiDexHandBiDexHand V4 | BiDexHand Project | — | — | Not disclosed | 5 fingers | 21 joints | 16 DOF | — | — | — | — | 2026-09-12 | |
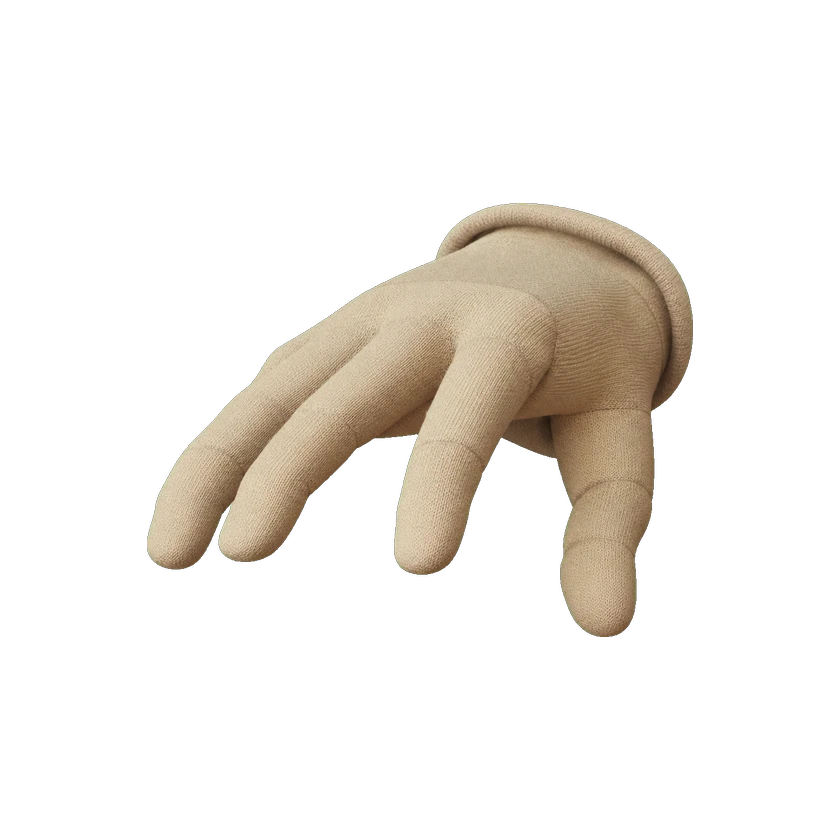 NEO HandsNEO Hands | 1X Technologies | United States | — | Not disclosed | — | 25 joints | 25 DOF | — | — | — | — | 2026-09-13 | |
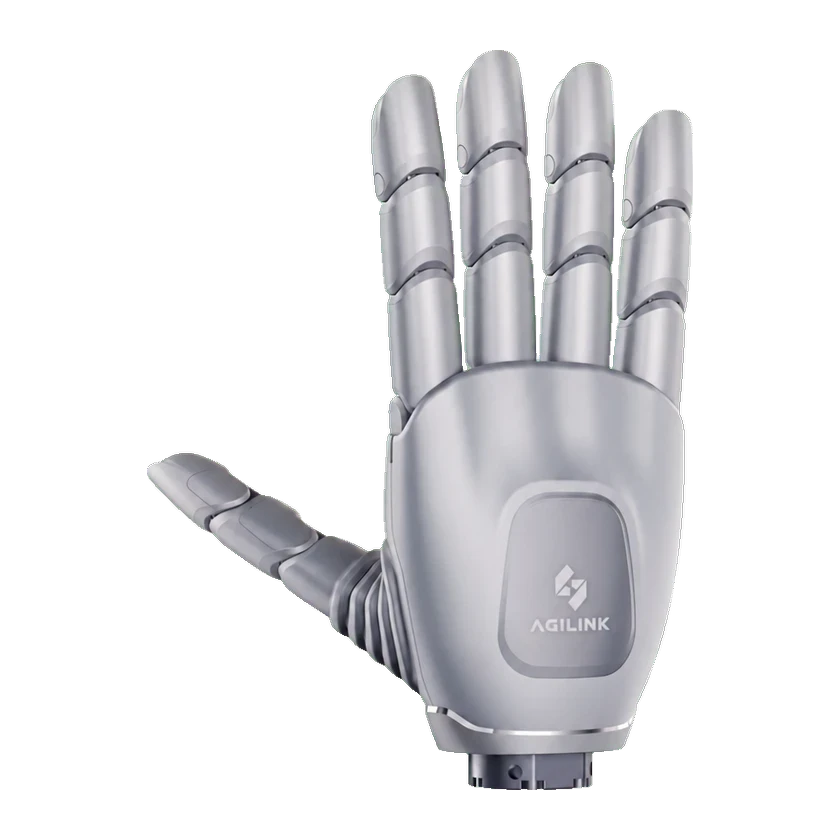 OmniHand 3OmniHand 3 Ultra-M | AGILINK | China | — | Not disclosed | — | — | 20 DOF | 0.63 kg | — | — | — | 2026-09-12 | |
 KAIST HandKAIST Hand | KAIST | South Korea | Prototype | Not released | 3 fingers | — | — | — | — | — | — | 2026-09-13 | |
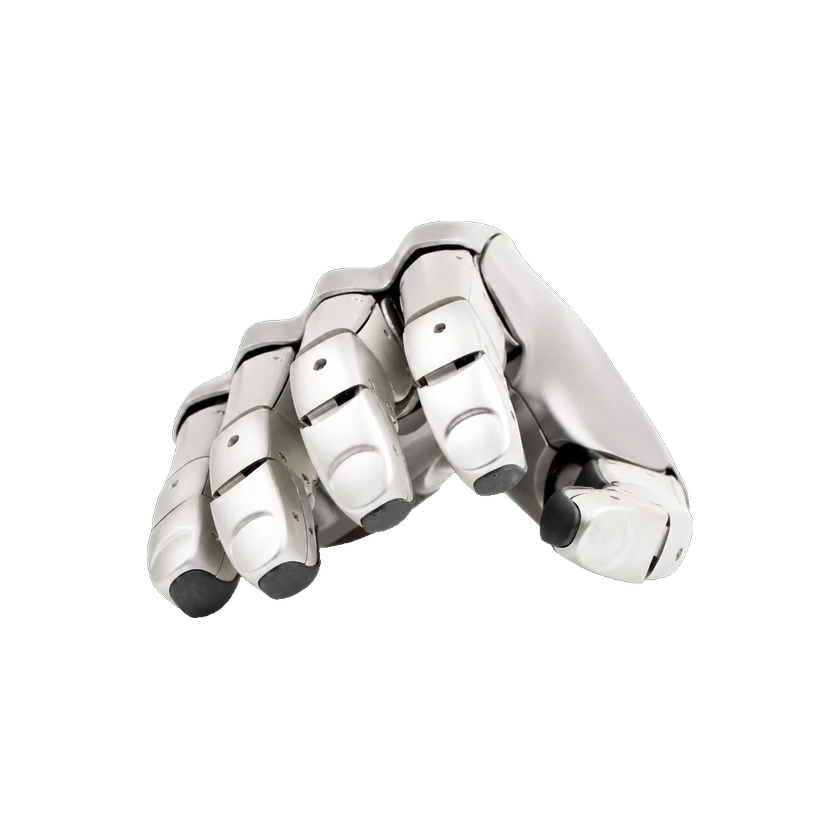 DLR-HIT HandDLR-HIT Hand II | Harbin Institute of Technology | — | Prototype | Not disclosed | 5 fingers | 20 joints | 15 DOF | 1.5 kg | — | — | — | 2026-09-12 | |
 Utah/M.I.T. Dextrous HandVersion I Utah/M.I.T. Dextrous Hand | MIT | United States | Prototype | Not disclosed | 4 fingers | 16 joints | 16 DOF | — | — | — | — | 2026-09-13 | |
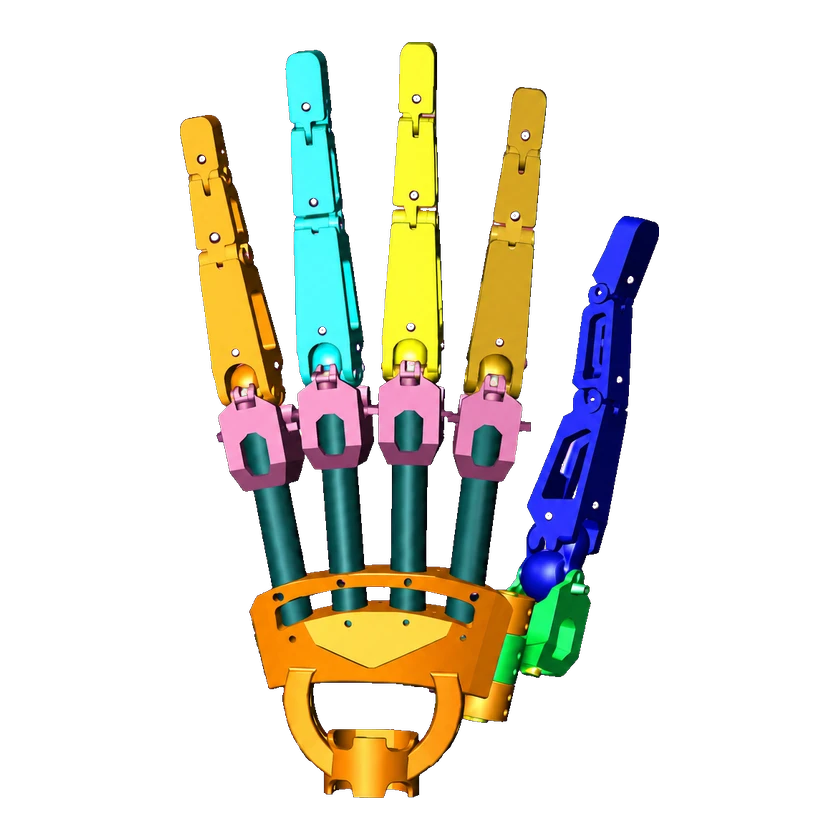 UW HandUW Hand | University of Washington | United States | — | Not disclosed | 5 fingers | — | 20 DOF | — | — | — | Unknown | 2026-09-13 | |
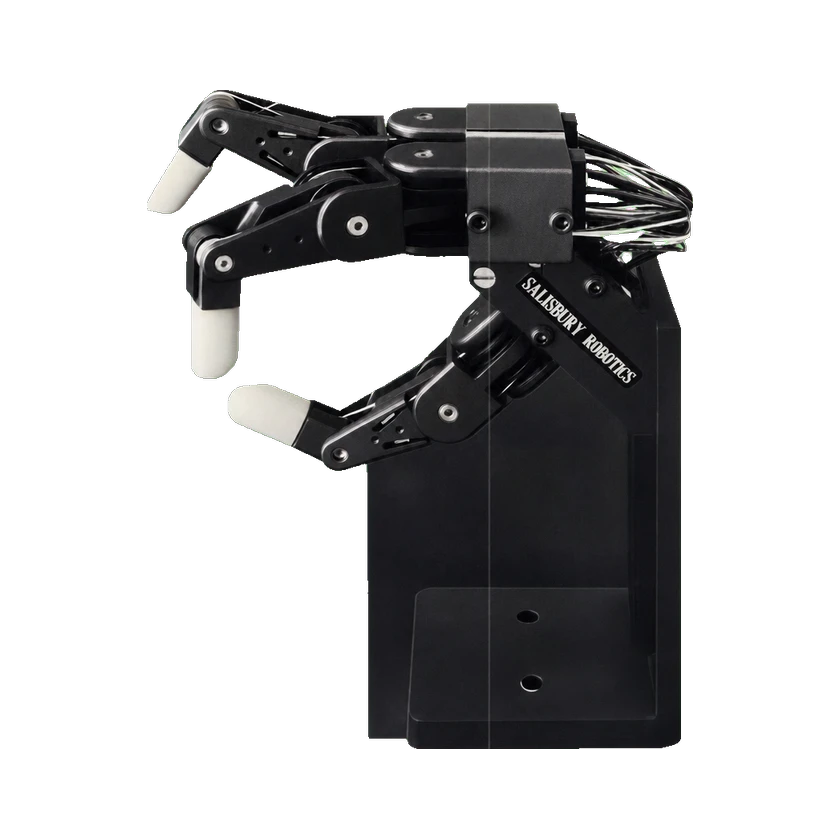 Stanford/JPL Robot HandStanford/JPL Robot Hand | Stanford University | United States | — | Not disclosed | 3 fingers | 9 joints | 9 DOF | — | — | — | — | 2026-09-13 | |
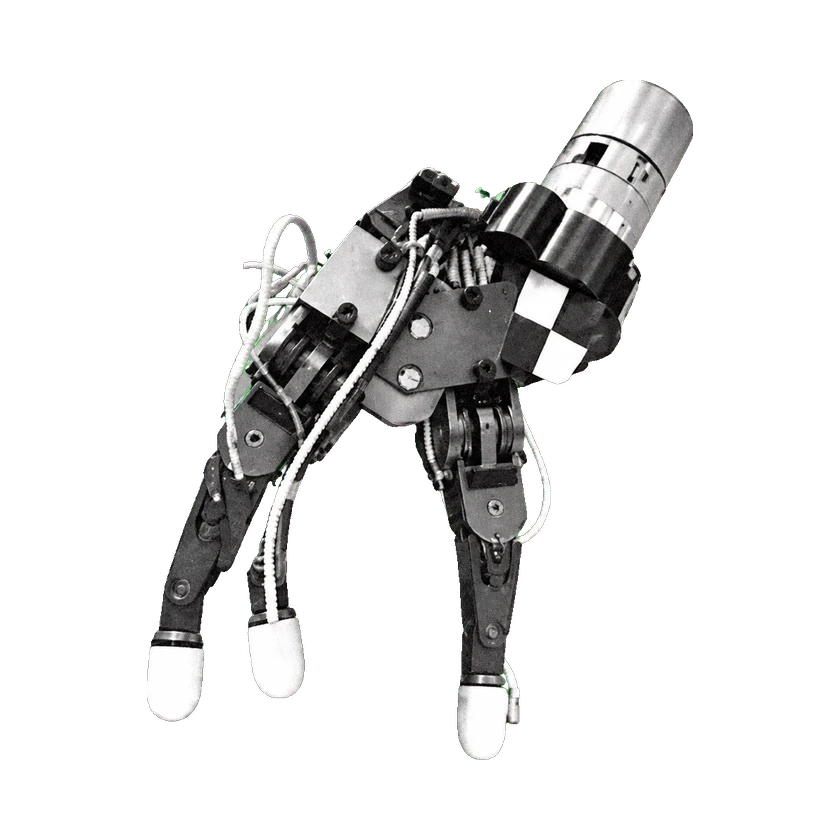 Stanford HandStanford/JPL Hand | Stanford University | United States | — | Not disclosed | 3 fingers | 9 joints | 9 DOF | — | — | — | Historical 1984 Sandia purchase: USD 32,265 | 2026-09-13 |
Submit a source or correction