
Carnegie Mellon University logoCarnegie Mellon University

DexKit V0

CMU research platform; not a commercial product listing.

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Prototype
Availability
Not released
Release Date
Unknown
Country/Region
United States
Latest parameter verification
2026-09-12
12 DOF
Active degrees of freedom
5
Finger count

DexKit V0 is a self-contained dexterous-manipulation research platform from Carnegie Mellon University. It combines a compliant anthropomorphic hand with 12 actuated degrees of freedom and a 4-DoF gantry. The underactuated, tendon-driven foam hand supports tabletop grasping, manipulation research, and educational experiments. The hand and motor bank cost about USD 800 to build, while the complete system costs about USD 2,000. It is a prototype and has not been publicly released for sale.
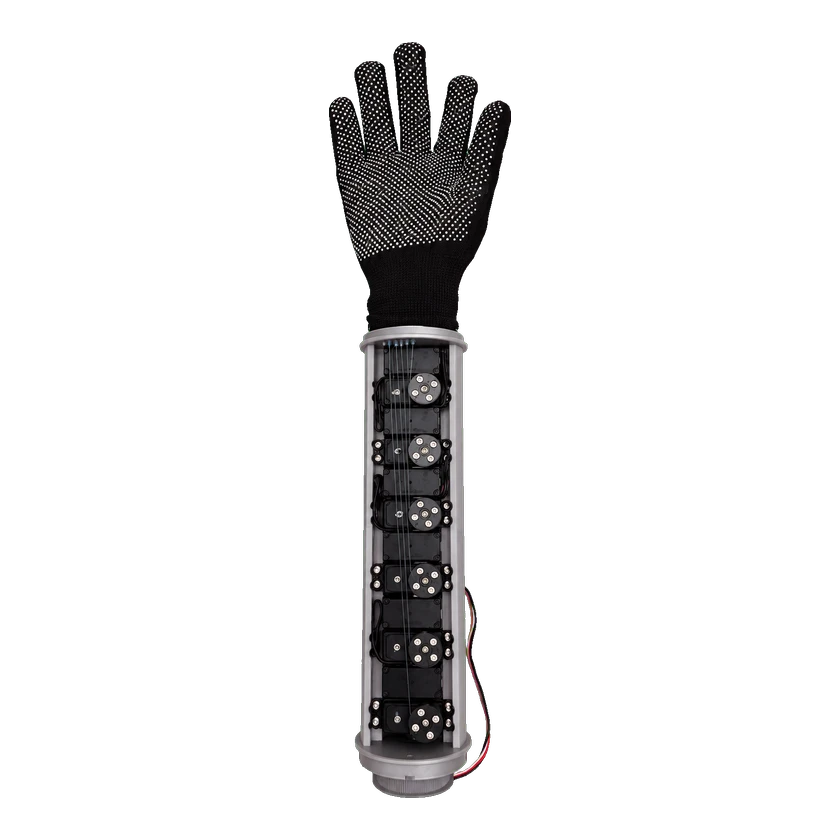
1 / 1DexKit V0

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Actuator count
Hand motor bank, excluding gantry: 12

Hand motor bank only; excludes gantry motors.

Actuator technology
Electric servo motors
Active degrees of freedom
12 DOF
Materials
FlexFoam-iT! X two-part urethane foam; cotton gloves; PTFE tubing; EVA retention bridges
Materials
3M Super 77 adhesive bonds the inner glove to the foam
Surface Fabric
Two cotton glove layers; outer glove covers tendons and tubing
Total degrees of freedom
Complete kit, hand plus gantry: 16

Complete kit: hand 12 plus gantry 4; not hand-only DOF / 整套平台:手部 12 加龙门架 4,非仅手部自由度 / キット全体:手12+ガントリー4、手部のみの自由度ではない

Transmission mechanism
Tendon-driven underactuated foam hand
Actuator Model
Hand: 12 × FeeTech HL-3620-C002; forearm roll: FeeTech HL-3640-C001

Motion and coordination

Coordination architecture
Four-axis gantry with X, Y and Z translation plus forearm roll

Mechanical and mounting

Mounting interface
3D-printed perforated wrist insert bonds to foam and guides tendons to the motor bank

Mechanical Structure

Internal Wiring
PTFE tendon guide tubes: 2 mm outer diameter, 1 mm inner diameter
Internal Wiring
Tendons are sewn into the inner glove and terminated with double constrictor knots
Joint Type
Compliant continuum foam structure

Development and Expansion

Configuration Options
Customizable hand shape and tendon paths; removable EVA tube-retention bridges

Commercial Status

Status
Prototype
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction