
 1X Technologies
NEO Hands
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Integrated NEO hand component; separate purchase availability undisclosed
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
United States
Last Verified
2026-09-13
25 active DOF per hand
Active degrees of freedom
25
Mechanical joint count
1X NEO Hands: tendon drive, 25 degrees of freedom, IP68 protection and tactile sensing.
1 / 1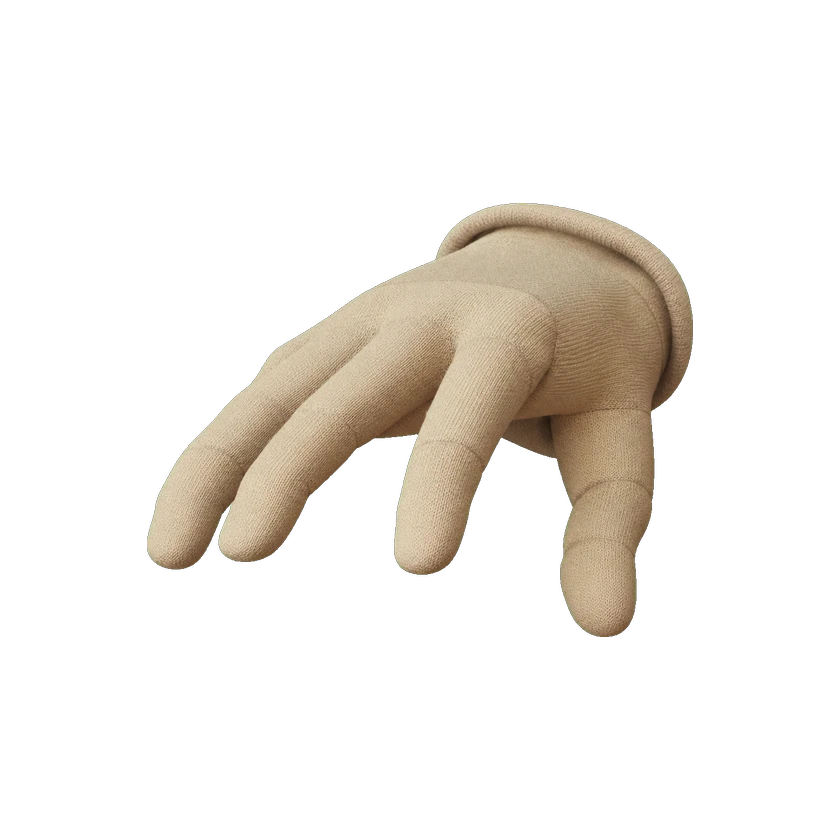
Hardware Specification
Degrees of freedom and drive
Actuator technology
Tendon drive
Active degrees of freedom
25 active DOF per hand
Ingress Protection (IP)
IP68 waterproof
Mechanical joint count
25
Materials
Food-safe materials
Total degrees of freedom
25 DOF
Transmission mechanism
Tendon drive
Mobility & Payload
Absolute Position Accuracy
±0.2 mm
Peak Joint Output Torque
17.75 N·m
Mechanical Structure
Dexterous Hand
Dexterous hand component for the NEO humanoid platform
Dexterous Hand Model
NEO Hands
Gear Ratio
5, 15
Joint Sensor Type
Closed-loop proprioception
Sensors
Force/Torque Sensor
Joint-level force sensing through force-transparent tendons
Sensors
Joint proprioception and high-resolution tactile sensing
Tactile Sensor
High-resolution tactile sensing: normal force, contact location and shear
Battery and Runtime
Cycle Life
2000000
Safety and Protection
Human-Robot Safety
Low gear ratios, tendon drive and low distal inertia enable safe backdriving under impact
Safety System
Compliant, fully backdrivable finger design for safe contact
Interaction and Communication
Tactile Feedback
Normal force, contact location and shear; real-time slip detection
Commercial Status
Status
Integrated NEO hand component; separate purchase availability undisclosed
Price
Price not disclosed
Release Date
Unknown
Related Entities
Robots related to “NEO Hands”
Submit a source or correction