
Components
Search component names, models or companies
Showing 221 components models
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Maximum weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
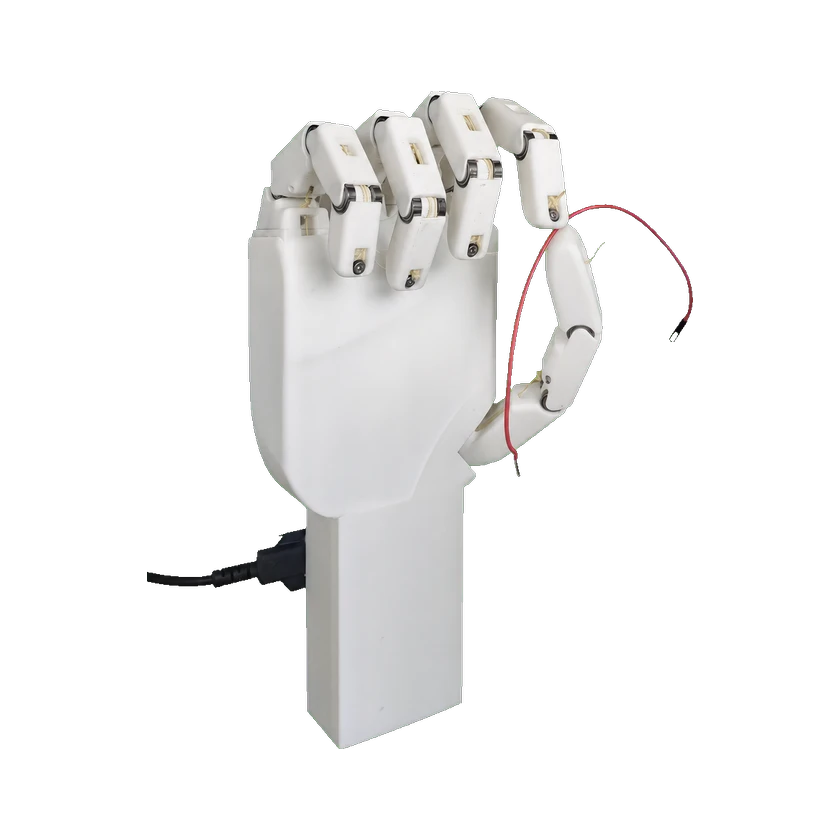 PHANTOM HandPHANTOM Hand | The Hong Kong University of Science and Technology (Guangzhou) | China | Prototype | Not released | 5 fingers | 15 joints | 6 DOF | — | — | — | Price unknown | 2026-09-14 | |
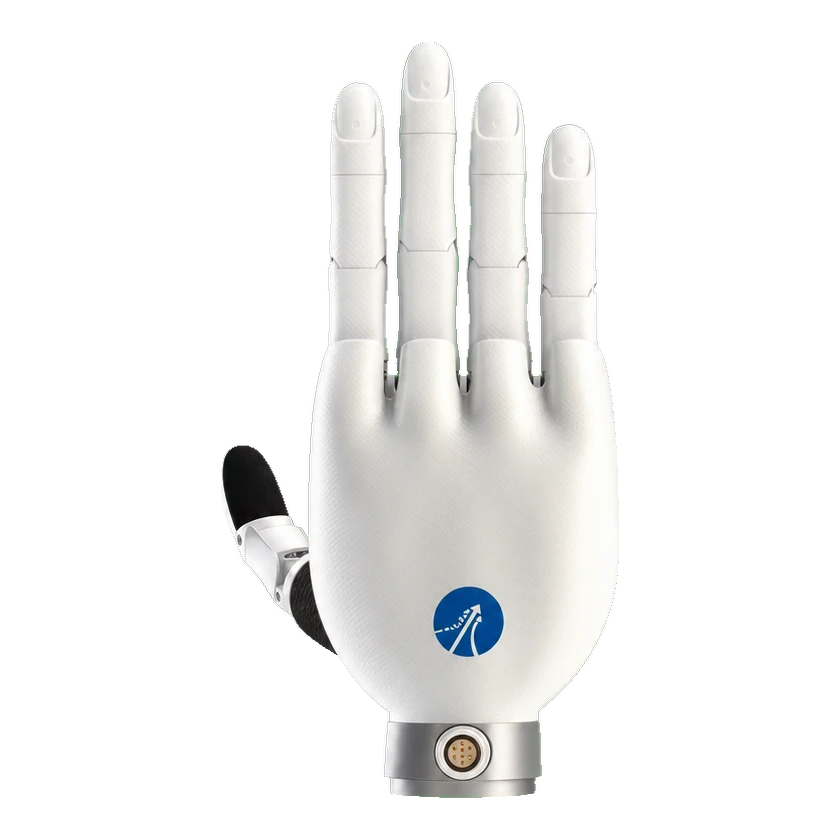 DH2015DH2015 | Leadshine | China | Prototype | Not disclosed | 5 fingers | 20 joints | 15 DOF | 0.67–0.68 kg | — | — | — | 2026-09-15 | |
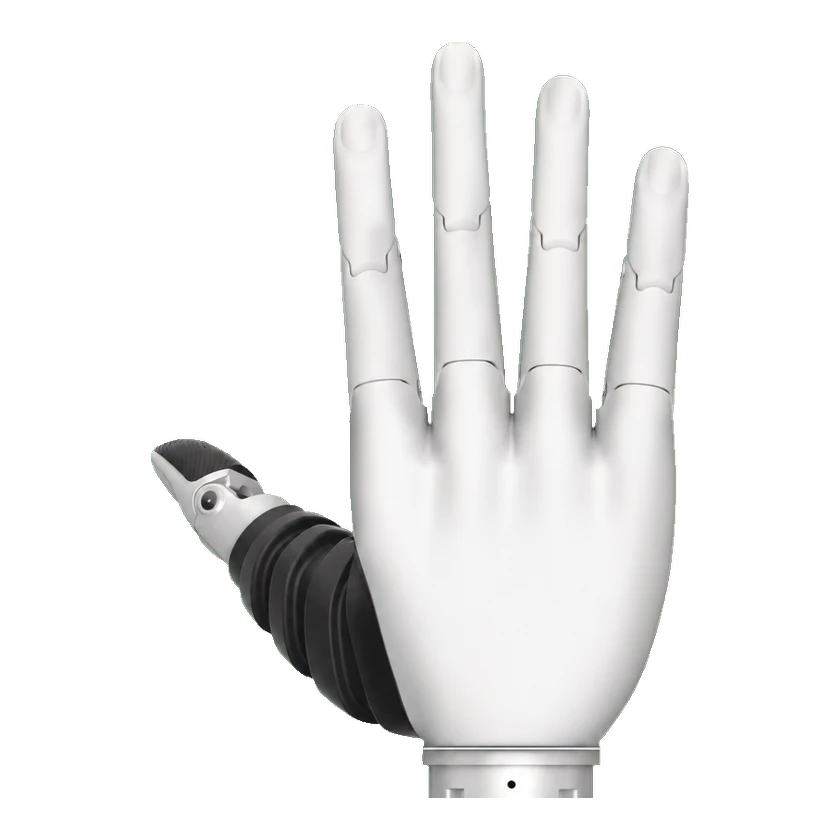 DH116S Mini Dexterous HandDH116S Mini Dexterous Hand | Leadshine | China | Commercial | On sale | 5 fingers | — | 6 DOF | — | — | — | From USD 2,299 | 2026-09-15 | |
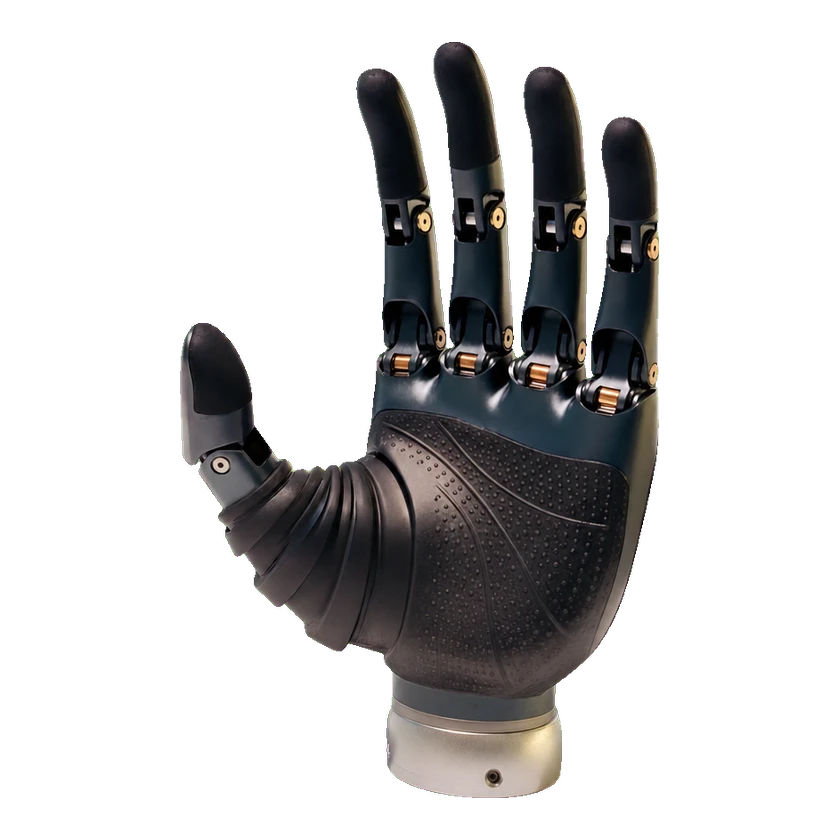 DH116P Force-Enhanced Dexterous HandDH116P Force-Enhanced Dexterous Hand | Leadshine | China | Pilot | Pilot only | 5 fingers | — | 6 DOF | — | — | — | Not disclosed | 2026-09-15 | |
 Linker HandLinker Hand L10 | LinkerBot | China | — | Not disclosed | — | — | 10 DOF | 0.75 kg | — | — | — | 2026-09-12 |
Submit a source or correction