
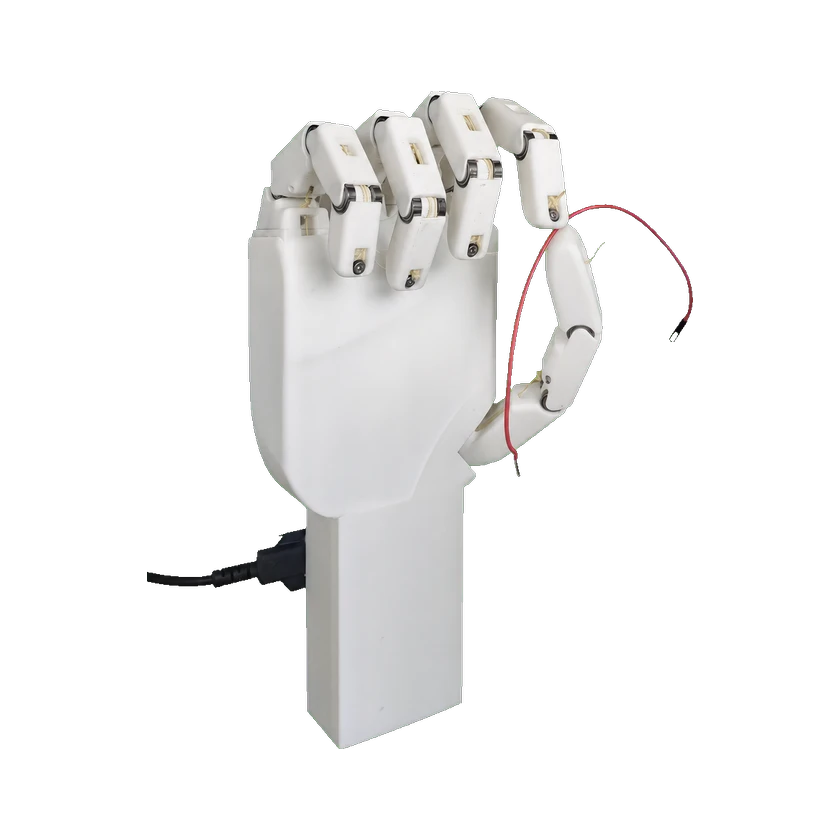
Research prototype v1
Communication and control
Control mode
Servo-space PD control
Paper v1, Section IV-A4: servo-space PD, target clipping to the admissible workspace, and driver-level velocity/torque saturation. No control-loop frequency is specified.
Software and resources
CAD availability
Available
The paper reports CAD and URDF/ROS2 release with the research prototype. This source review confirms that statement, not an independently tested download or integration.
ROS compatibility
ROS 2
The paper reports CAD and URDF/ROS2 release with the research prototype. This source review confirms that statement, not an independently tested download or integration.