
Dexterous hand database
Browse source-backed dexterous hand products by specifications, availability, company, and commercial status.
193 product families · 292 models
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Hand weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
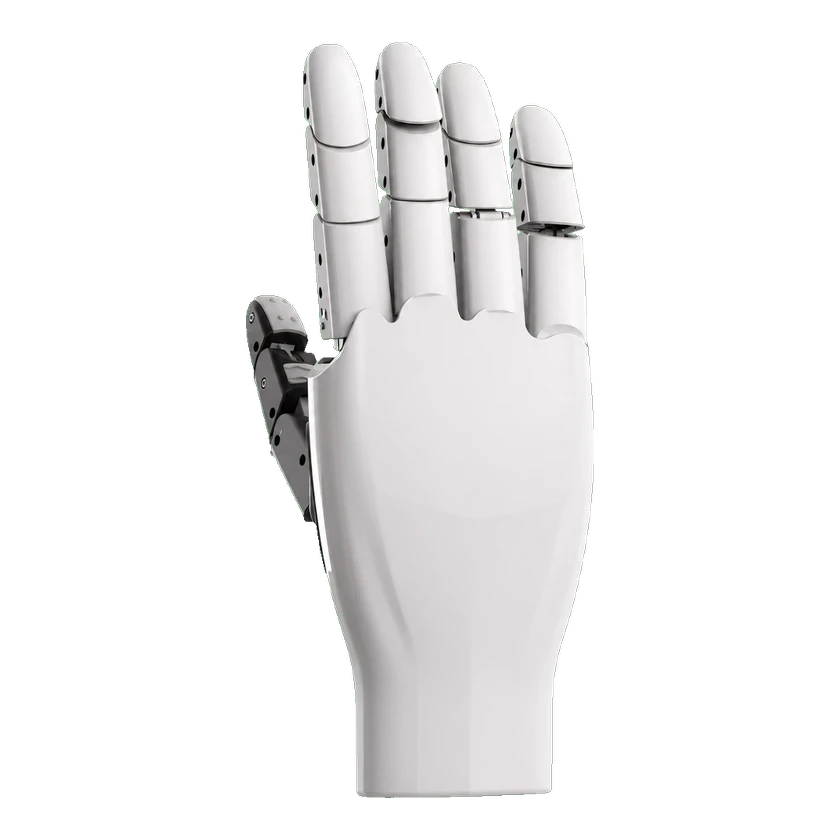 Pantheon Hand 20Pantheon Hand 20 | Shenzhen Stellar Robot Technology Co., Limited | China | Commercial | Not disclosed | — | — | — | 0.29 kg | — | — | — | 2026-09-15 | |
 Pantheon Hand 01Pantheon Hand 01 | Shenzhen Stellar Robot Technology Co., Limited | China | Pilot | Pilot only | 5 fingers | — | 15 DOF | ≤0.35 kg | — | — | Not disclosed | 2026-09-15 | |
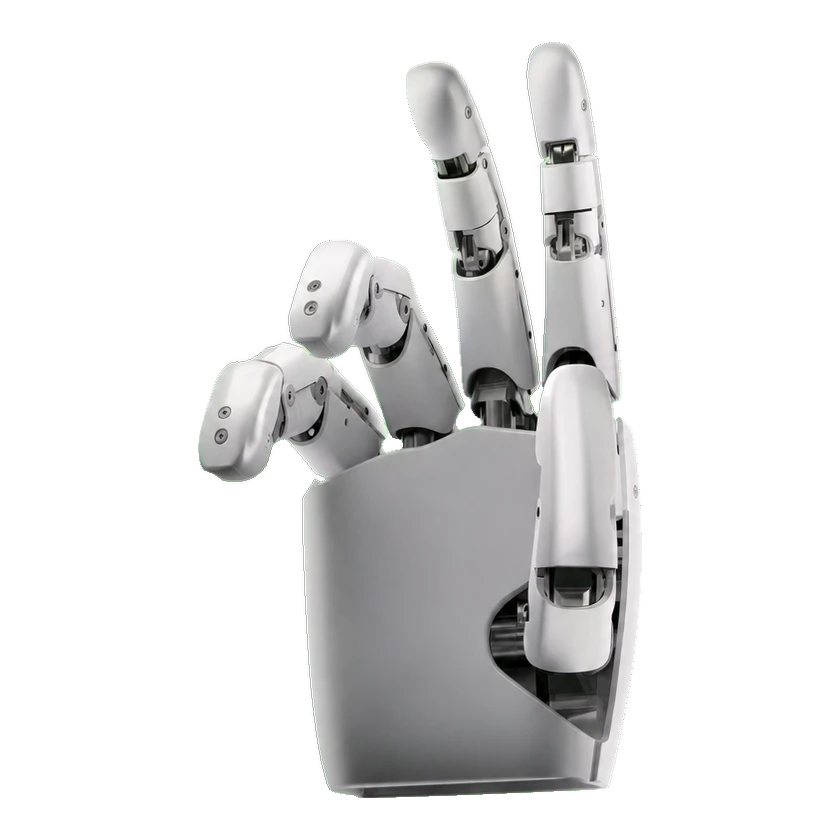 Gaia Hand 20Gaia Hand 20Gaia 20 — Base edition (2025) | Shenzhen Stellar Robot Technology Co., Limited | China | Commercial | Not disclosed | 5 fingers | — | 16 DOF | — | — | Not included | Not disclosed | 2026-09-15 | |
| OSOR HandOSOR Hand | Southern University of Science and Technology | China | Prototype | Not released | 5 fingers | 12 joints | 12 DOF | — | — | — | Not disclosed | 2026-09-15 | |
| PDSR3-Tac HandPDSR3-Tac HandPDSR3-Tac — 2026 paper prototype | Southeast University | China | Prototype | Not disclosed | 3 fingers | — | — | — | — | Included | Price not disclosed | 2026-09-15 | |
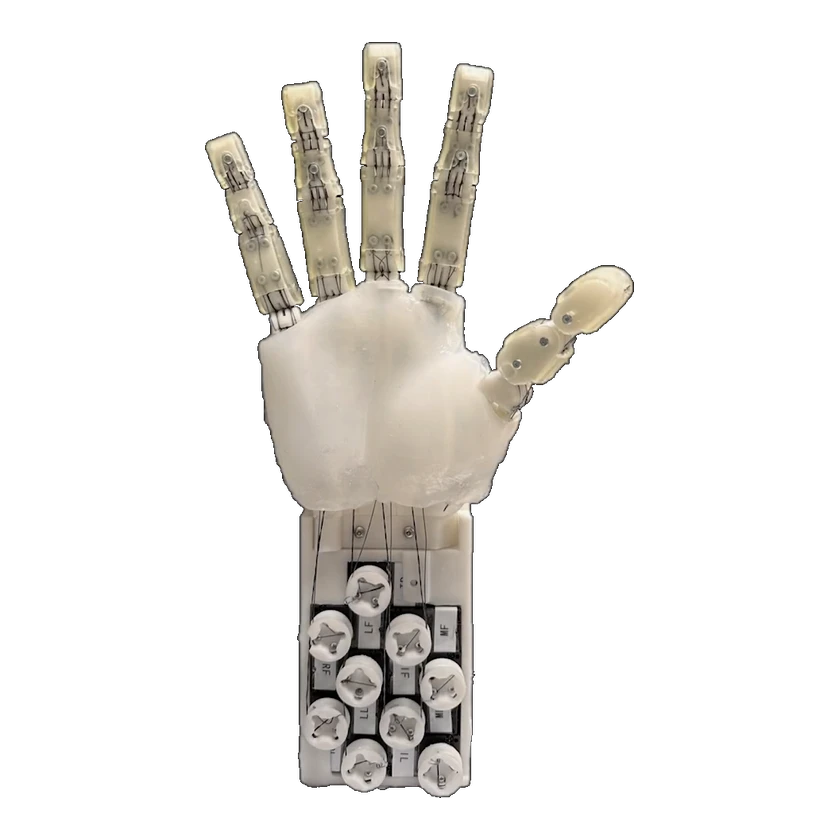 RIM HandRIM Hand | Sogang University | South Korea | Prototype | Not disclosed | 5 fingers | — | — | 0.74 kg · 0.34 kg | — | — | — | 2026-09-15 | |
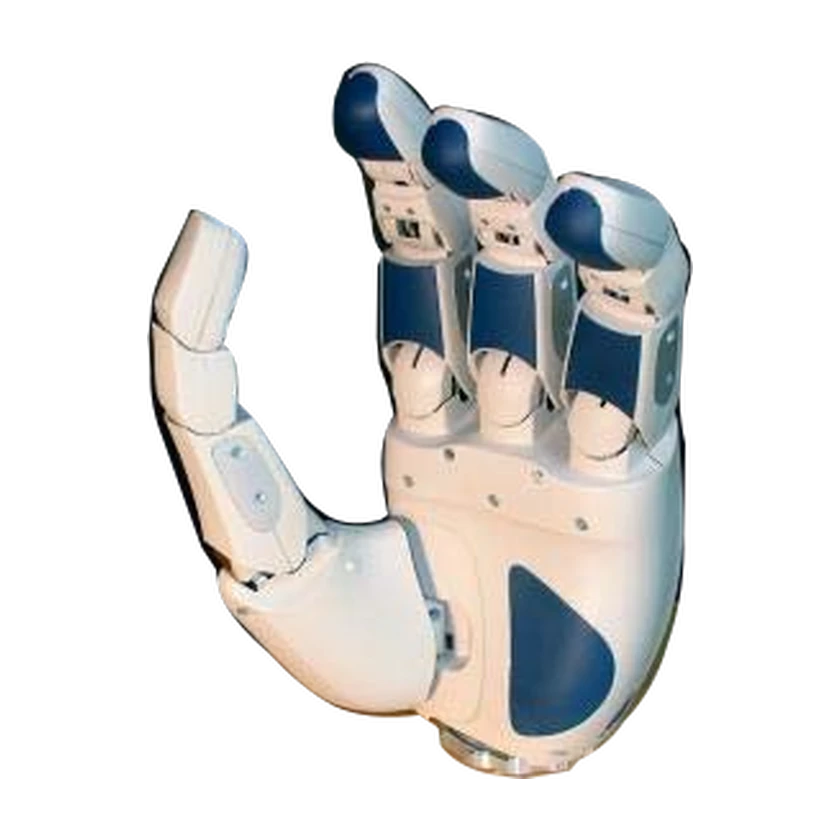 SAHSAHLeft hand | SCHUNK | Germany | Commercial | Not disclosed | 4 fingers | 17 joints | 13 DOF | 2.2 kg | Serial interface | — | — | 2026-09-15 | |
 Apex HandApex HandRight hand | Rysen Robotics | China | Commercial | On sale | 5 fingers | 21 joints | — | 1.2 kg | Ethernet | — | Contact sales for a quote | 2026-09-15 | |
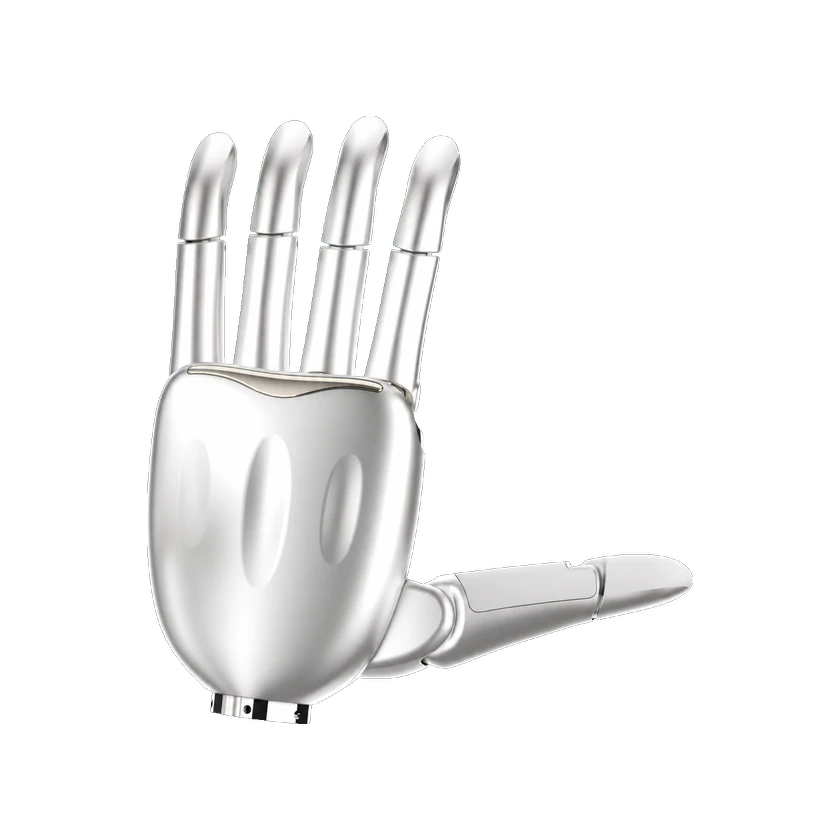 RY-H6RY-H6RY-H6 S611-C1-A0-00 | Ruiyan Intelligent Control | China | Commercial | On sale | 5 fingers | 11 joints | 6 DOF | 0.28 kg | CAN · CAN-FD · RS485 · EtherCAT | — | — | 2026-09-15 | |
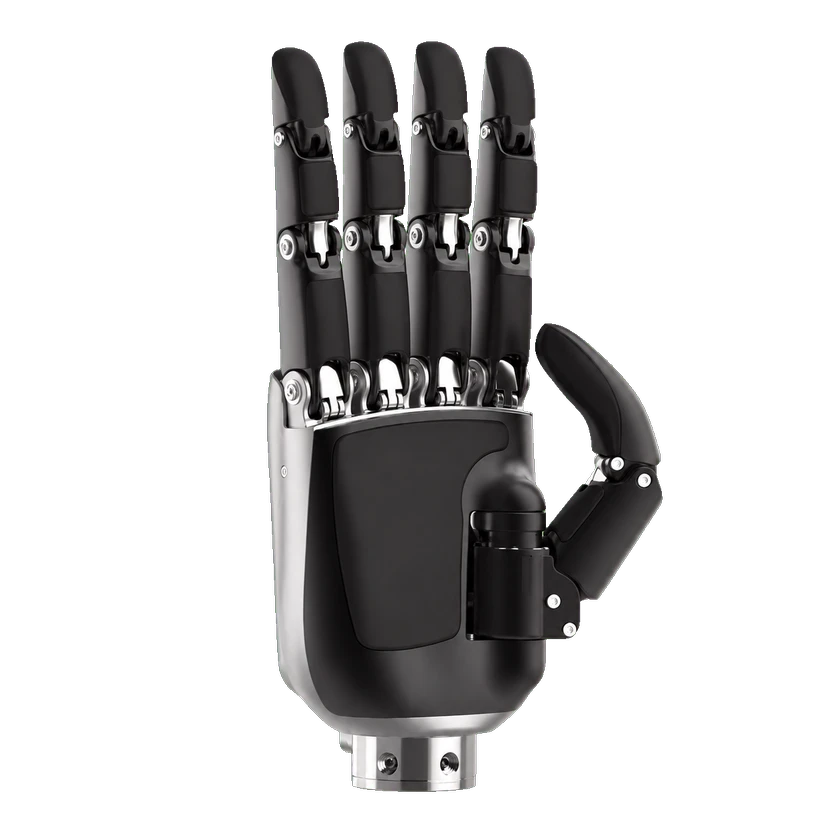 RY-H5RY-H5Standard | Ruiyan Intelligent Control | China | Commercial | On sale | 5 fingers | 15 joints | 6 DOF | 0.67 kg | CAN · CAN-FD · RS485 · EtherCAT | — | — | 2026-09-15 | |
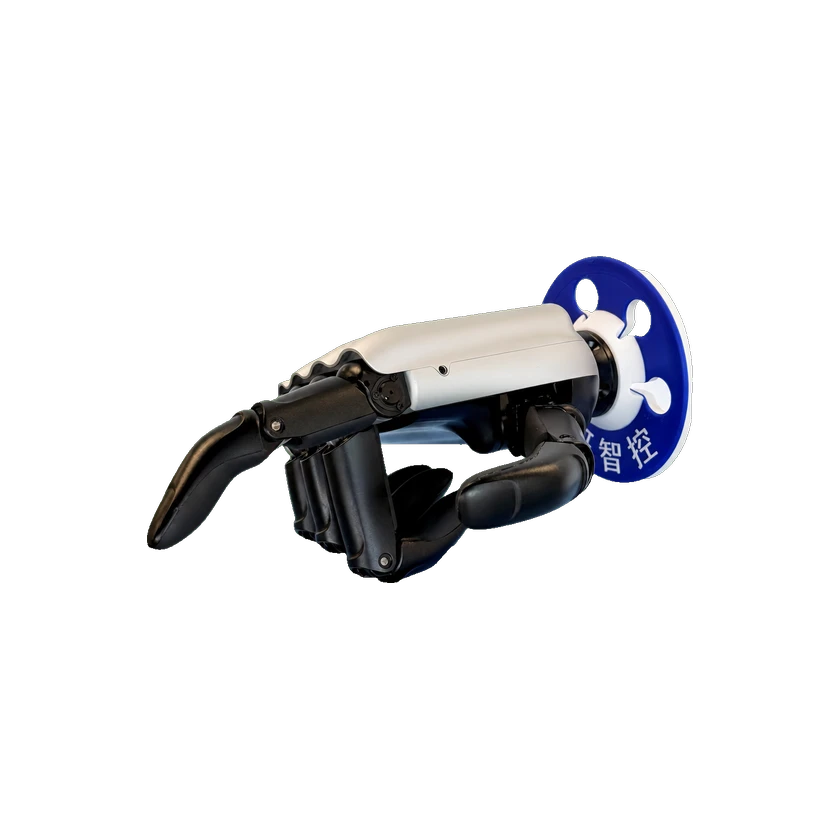 RY-H2RY-H2RY-H2 C1-A1 | Ruiyan Intelligent Control | China | Commercial | On sale | 5 fingers | 11 joints | 6 DOF | 0.56 kg | CAN · CAN-FD · RS485 · EtherCAT | — | Contact for a quote | 2026-09-15 | |
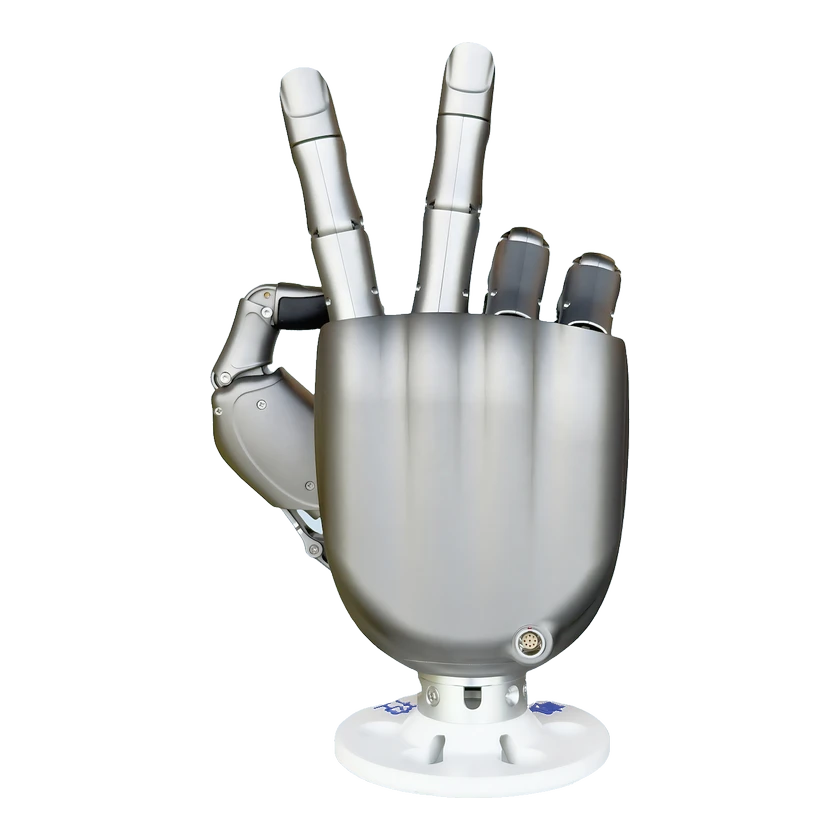 RY-H1RY-H1RY-H1L/R-1621-C0-A2-00 | Ruiyan Intelligent Control | China | Commercial | On sale | 5 fingers | 21 joints | 16 DOF | 0.85 kg | CAN · CAN-FD · RS485 · EtherCAT | Not included | — | 2026-09-15 | |
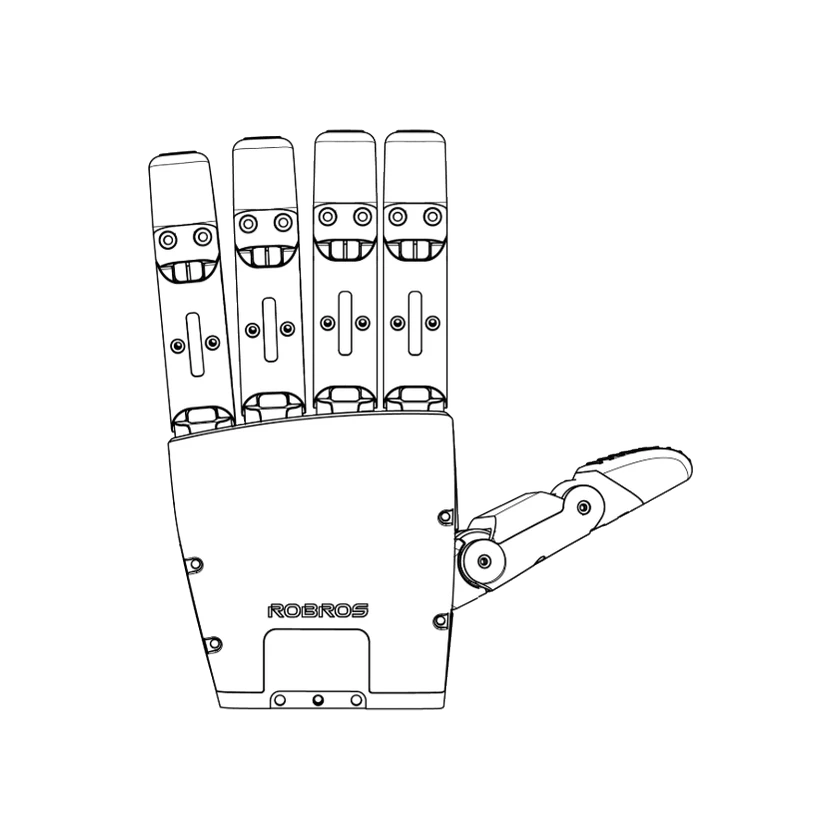 H5_CH5_CIGRIS-C2.1.1: five-finger hand API | ROBROS | South Korea | — | Not disclosed | 5 fingers | — | 6 DOF | — | — | — | — | 2026-09-15 | |
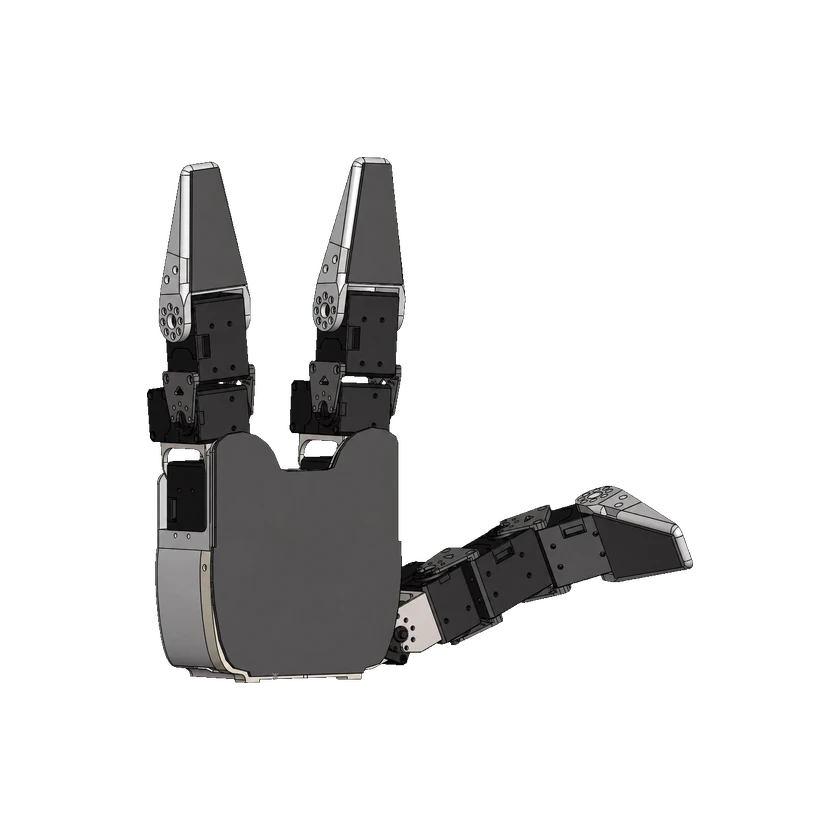 D'ManusD'ManusReSkin 10-DoF | ROBEL | — | Prototype | Not disclosed | 3 fingers | — | 10 DOF | — | USB serial bus · RS485 motor bus | Included | — | 2026-09-15 | |
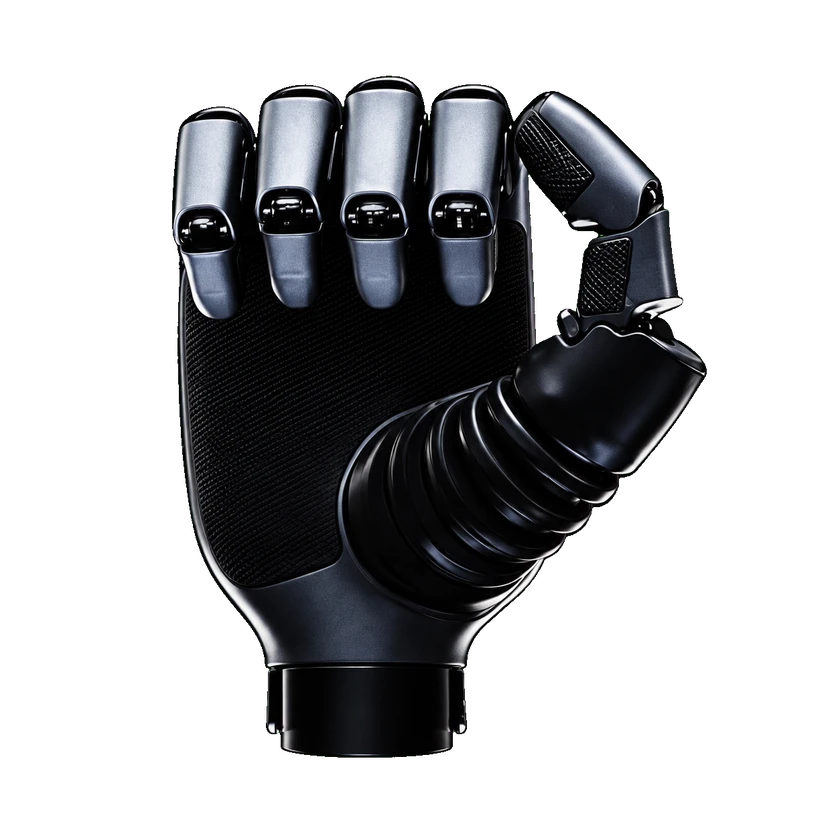 CHOHO HandCHOHO HandCHOHO Hand | Qingdao CHOHO Industrial Co., Ltd. | China | Commercial | On sale | 5 fingers | — | 7 DOF | 0.72 kg | — | — | Not disclosed | 2026-09-15 | |
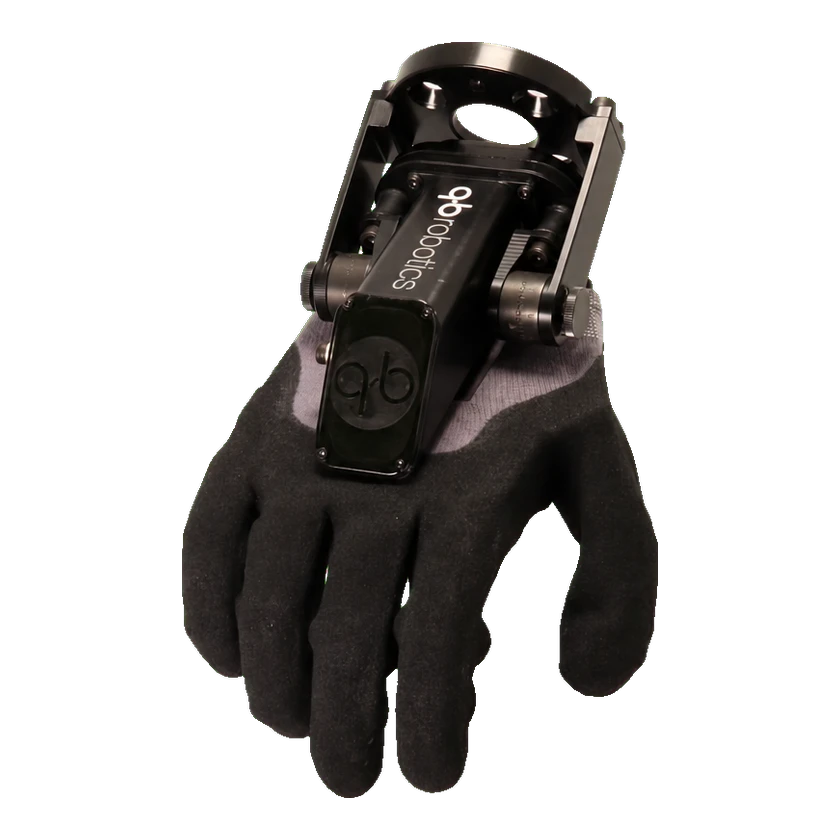 qb SoftHand Industryqb SoftHand IndustryRight hand | qbrobotics | Italy | Commercial | On sale | 5 fingers | — | 1 DOF | 0.99 kg | USB · RJ-45 Ethernet · Digital I / O · EtherCAT (compatible external driver) | — | On quotation | 2026-09-15 | |
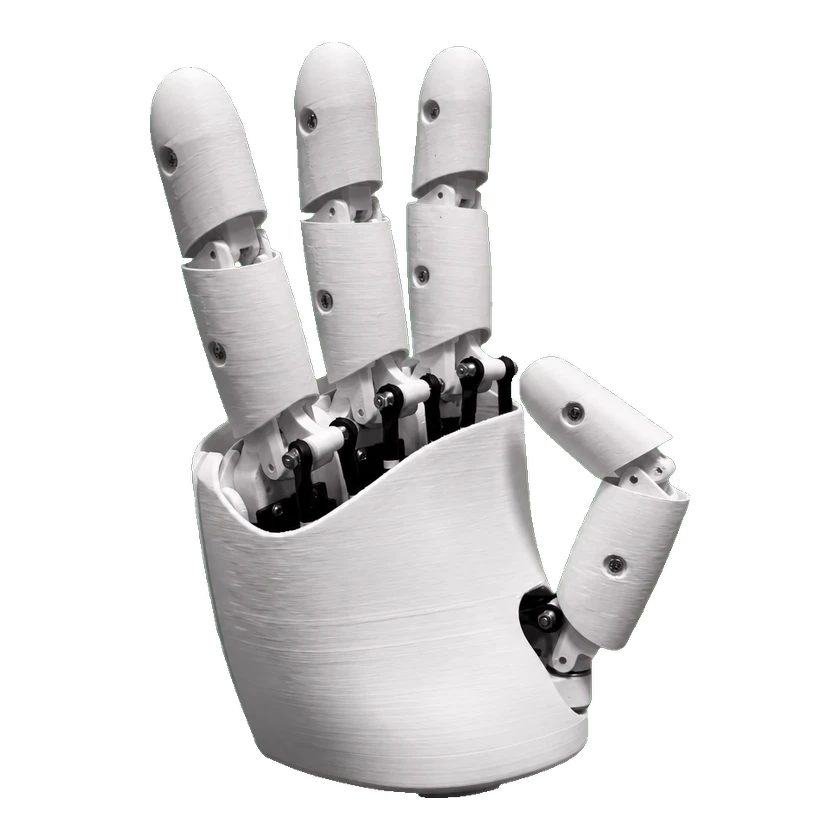 Amazing HandAmazing HandOriginal SCS0009 reference build | Pollen Robotics | France | Commercial | On sale | 4 fingers | — | 8 DOF | 0.4 kg | TTL serial bus via an external driver | — | Seeed right-hand kit: USD 99 | 2026-09-15 | |
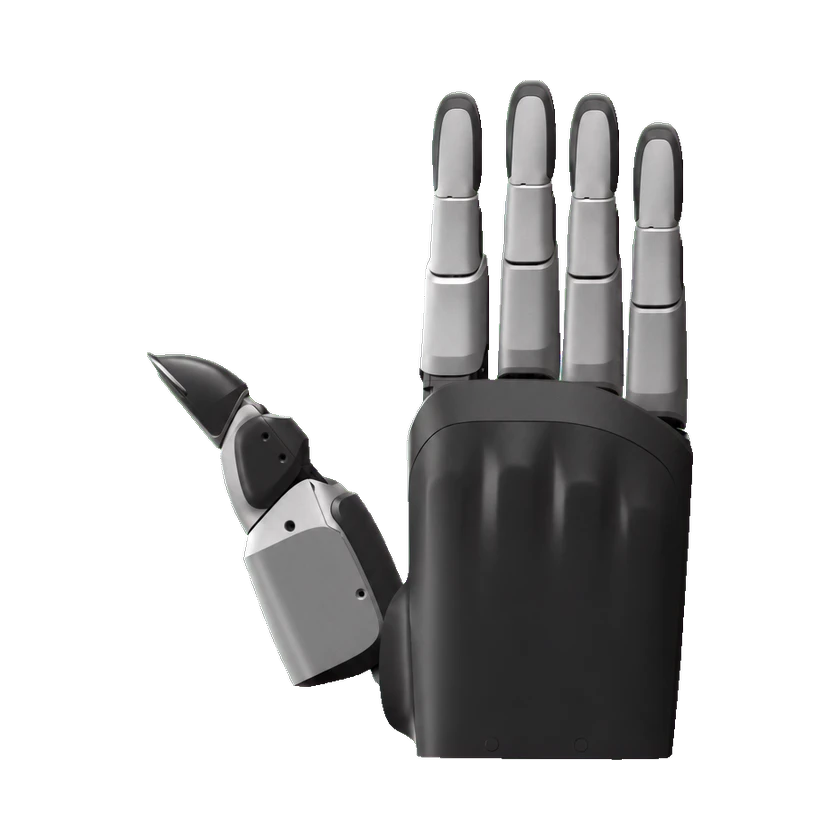 GMH18GMH18GMH18 | PaXini | China | — | Not released | 5 fingers | — | 11 DOF | — | USB · EtherCAT · Ethernet · CAN-FD | Included | Price not disclosed | 2026-09-15 | |
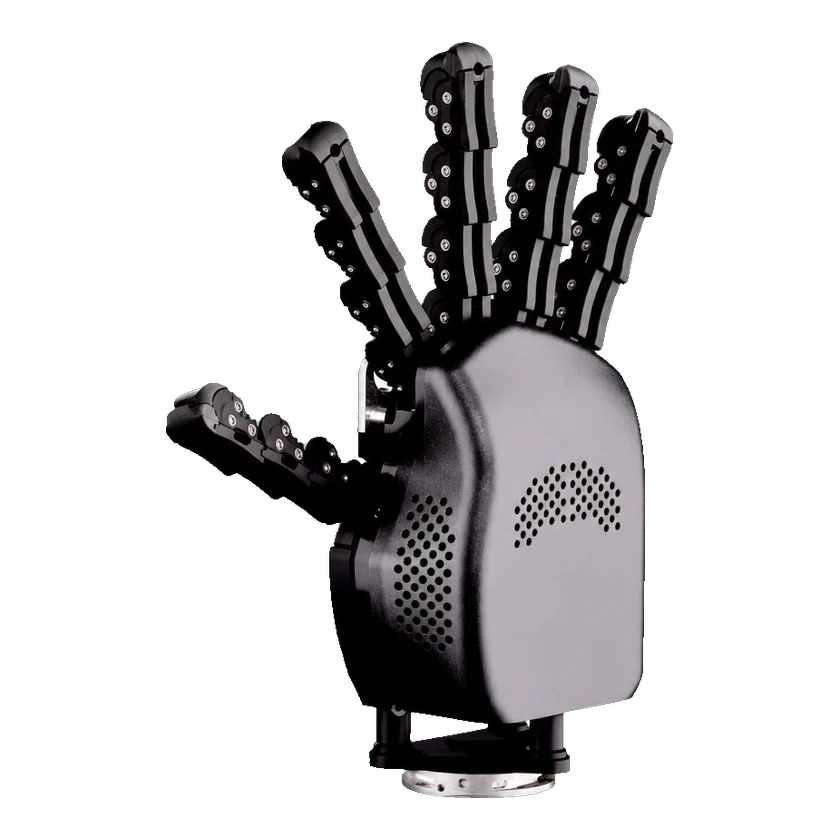 Hey5Hey5TIAGo paper: wrist CAN integration | PAL Robotics | Spain | Commercial | Not disclosed | 5 fingers | 19 joints | 3 DOF | 0.72 kg | CAN | — | — | 2026-09-15 | |
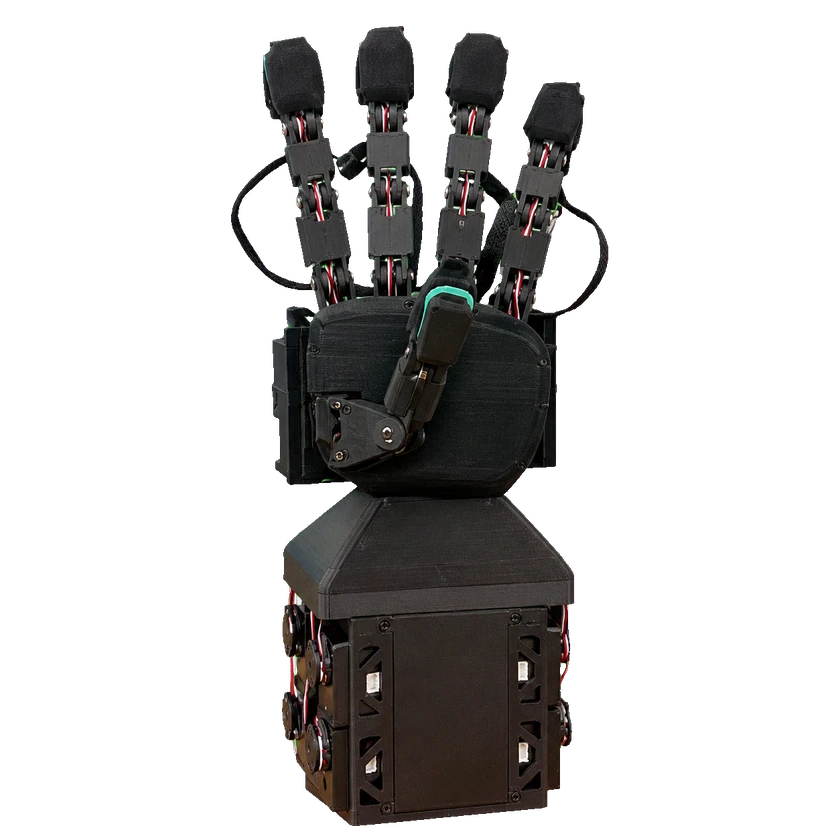 RUKARUKAOriginal paper evaluated build | New York University | United States | Prototype | Not disclosed | 5 fingers | — | 11 DOF | — | Host USB via a USB-to-serial bridge | — | — | 2026-09-15 | |
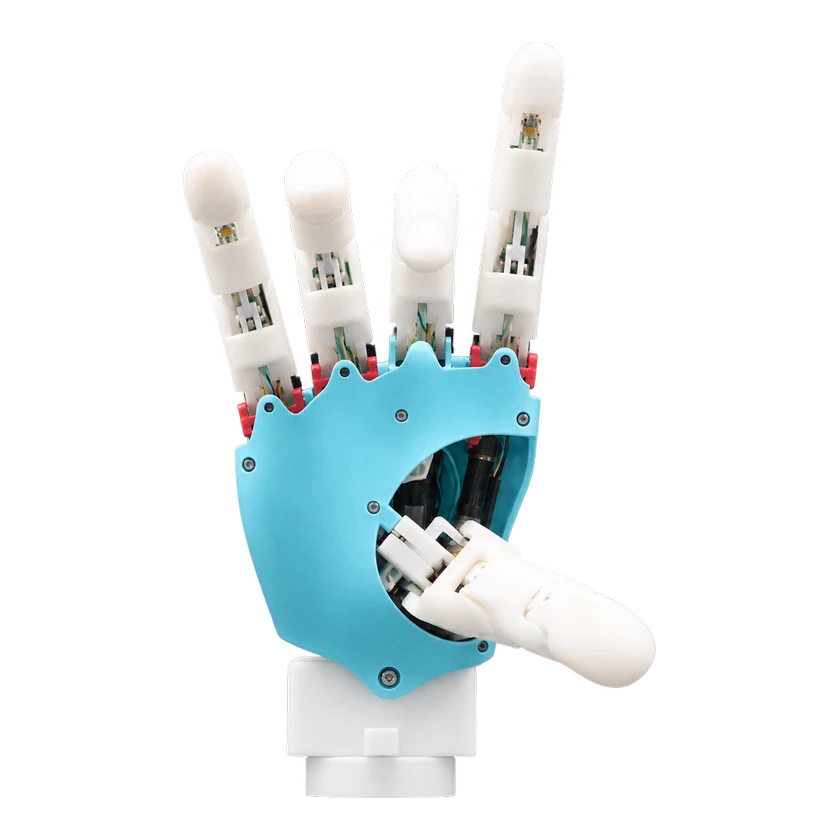 SyLink HandSyLink HandSyLink Hand | National University of Singapore | Singapore | Prototype | Not released | 5 fingers | 19 joints | 11 DOF | 0.52 kg | — | Included | — | 2026-09-15 | |
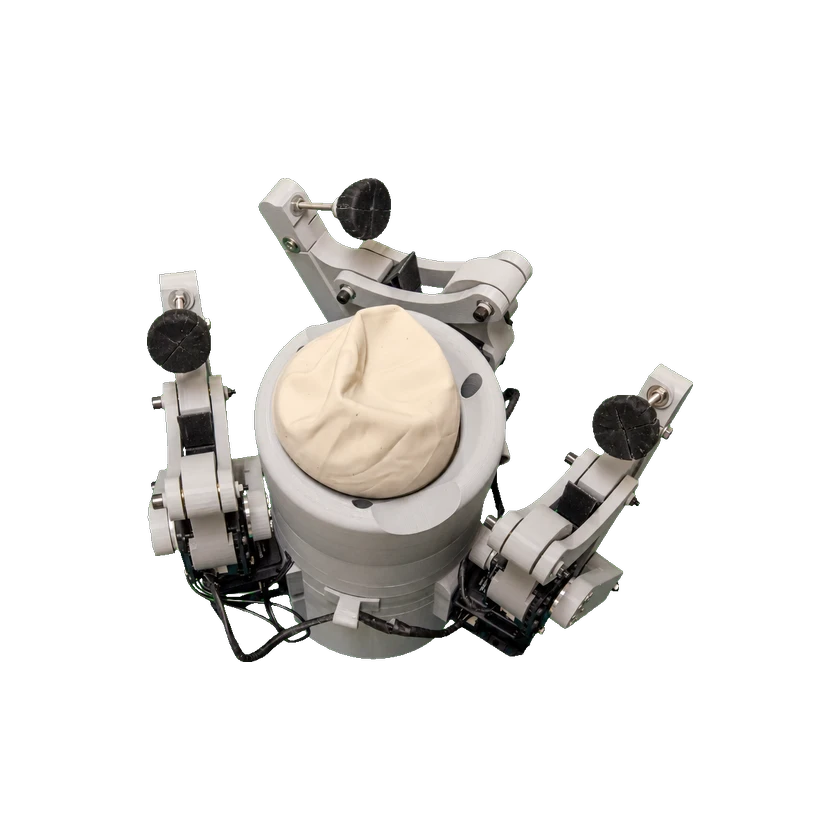 ARTiSARTiSControl-box setup | AIST | Japan | Prototype | Not disclosed | 3 fingers | — | 7 DOF | 2.83 kg | USB | — | — | 2026-09-15 | |
| Robonaut HandRobonaut HandRobonaut: design-paper control profile | NASA Johnson Space Center | United States | Prototype | Not disclosed | 5 fingers | — | 12 DOF | — | — | — | — | 2026-09-15 | |
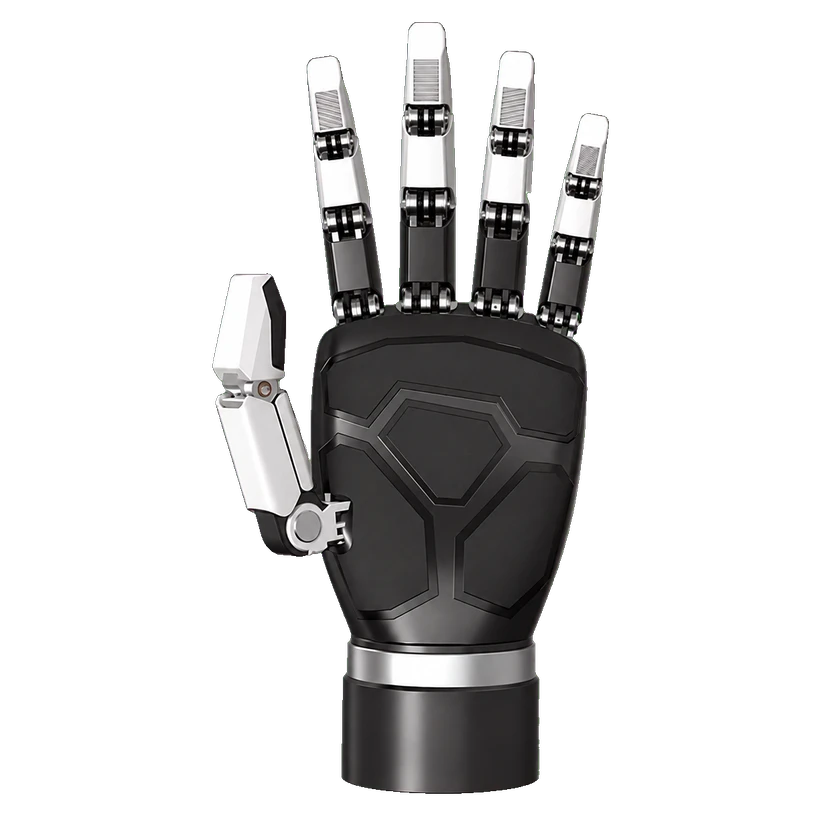 SQ-1503SQ-1503SQ-1503 | Mindsync Tech | China | Commercial | On sale | 5 fingers | — | 16 DOF | 3 kg | CAN | — | Distributor listed price: USD 16,500 | 2026-09-15 |
Submit a source or correction