qbrobotics logoqbrobotics

qb SoftHand Industry

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Commercially available
Availability
On sale
Release Date
2019
Country/Region
Italy
Latest parameter verification
2026-11-01
1 DOF
Active degrees of freedom
0.99 kg
Hand weight
5
Finger count

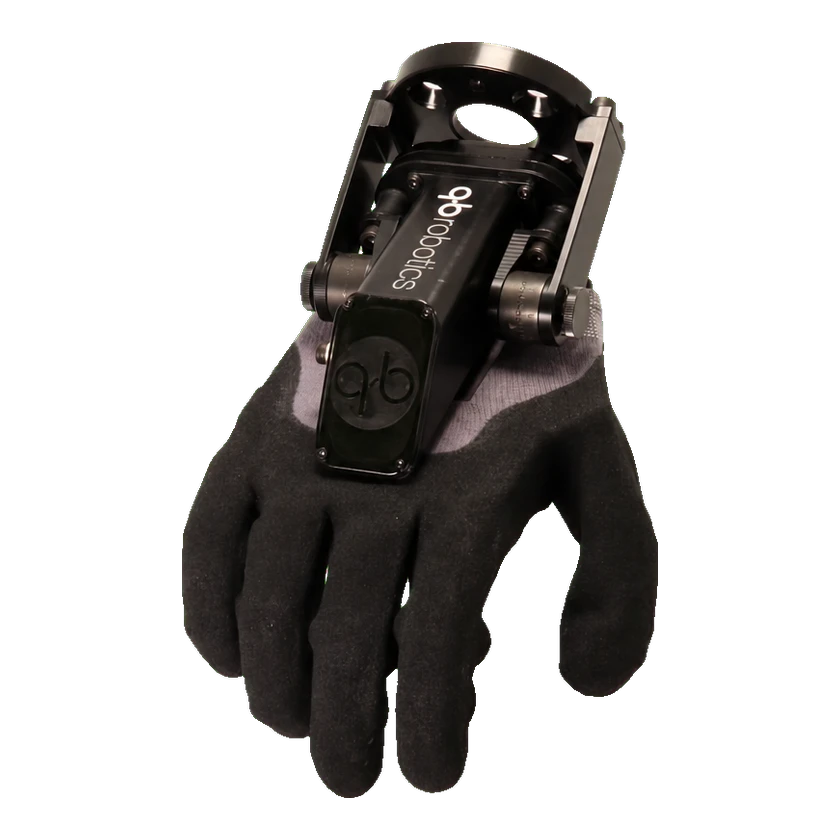
qb SoftHand Industry is an anthropomorphic robotic hand for industrial handling and testing. A single motor drives five fingers through tendons and one synergy, providing adaptive grasping with 19 mechanical degrees of freedom. It supports EtherCAT and UDP, integrates with collaborative robots and has IP65 protection.

1 / 1qb SoftHand Industry

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator count
1
Actuator technology
Electric motor
Active degrees of freedom
1 DOF
Total degrees of freedom
19 DOF
Transmission mechanism
Tendon driven

Motion and coordination

Energy domain
Electric
Synergy count
1

Mechanical and mounting

Depth
8.32 cm
Dimension included components
Hand including wrist mount
Dimension measurement pose
Open hand
Height
24.4 cm
Mounting flange standard
ISO 9409-1-50-4-M6
Mounting interface
ISO 9409-1-31.5-4-M5; ISO 9409-1-40-4-M6; SCHUNK SWS-007; SCHUNK SWS-011
Hand weight
0.99 kg
Width
18.5 cm

Electrical and integration

Operating voltage
23–26 V
Operating voltage
24 V
Rated power
13 W

Battery and Runtime

Max Power
≤15 W

Reliability and environment

Certifications
UR+ Approved
IP rating
IP65
Operating temperature
-5–50 °C

Development and Expansion

Configuration Options
Left and right versions; adjustable wrist mounting; interchangeable gloves
Workflow Integration
URCap; Doosan Mate

Configurations

Right hand

Right hand

Communication and control

Communication interface
USB

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication interface
RJ-45 Ethernet

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication interface
Digital I/O

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication interface
EtherCAT (compatible external driver)

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication protocol
EtherCAT with compatible driver

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication protocol
UDP

Software and resources

CAD availability
STEP
CAD availability
STL
ROS compatibility
ROS
ROS compatibility
ROS 2
SDK languages
C++

Left hand

Left hand

Communication and control

Communication interface
USB

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication interface
RJ-45 Ethernet

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication interface
Digital I/O

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication interface
EtherCAT (compatible external driver)

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication protocol
EtherCAT with compatible driver

These are system-integration interfaces through the external driver, not all native wrist connector signals. Datasheet release2.1.6 (March2024) shows M8 hand cable SSI/motor phases and external RJ45/DI/DO driver; EtherCAT requires a compatible driver. No tactile sensing follows from this interface list.

Communication protocol
UDP

Software and resources

CAD availability
STEP
CAD availability
STL
ROS compatibility
ROS
ROS compatibility
ROS 2
SDK languages
C++

Commercial Status

Status
Commercially available
Price
Price not disclosed
Release Date
2019
Submit a source or correction