
Dexterous hand database
Browse source-backed dexterous hand products by specifications, availability, company, and commercial status.
193 product families · 292 models
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Hand weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
 Xynova Flex 2Xynova Flex 2Flex 2 — product manual V1.2 specification | Xynova | China | Commercial | On sale | 5 fingers | — | 19 DOF | 0.4 kg | CAN-FD · EtherCAT | Included | CNY 128,000+ | 2026-09-26 | |
 MCR-Bionic HandMCR-Bionic Hand | University of Salford | United Kingdom | Prototype | Not released | 5 fingers | — | — | — | — | — | Not disclosed | — | |
 ARISTO HandARISTO HandResearch prototype | The University of Texas at Austin | United States | Prototype | Not released | 3 fingers | — | — | — | — | Included | Not disclosed | — | |
 HandroidHandroid | University of North Carolina at Chapel Hill | United States | Prototype | Not disclosed | 5 fingers | — | 20 DOF | 2.05 kg | — | — | Not disclosed | — | |
| CRAFT HandCRAFT Hand | University of Illinois Urbana-Champaign | United States | Prototype | Not disclosed | 5 fingers | — | 15 DOF | 0.8 kg | — | — | Not disclosed | — | |
| Karlsruhe Dextrous Hand IIKarlsruhe Dextrous Hand II | Karlsruhe Institute of Technology | Germany | Prototype | Not released | 4 fingers | 12 joints | 12 DOF | — | — | — | — | — | |
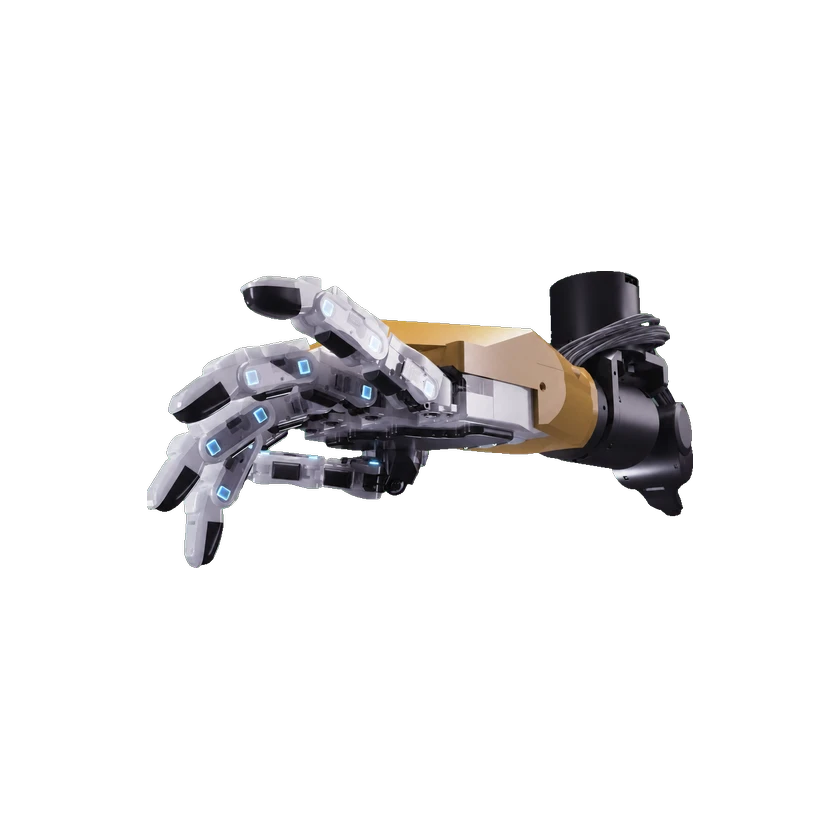 MM-Hand 1.0MM-Hand 1.0Standard | The University of Hong Kong | Hong Kong SAR China | — | Not disclosed | 5 fingers | — | 21 DOF | 0.35 kg | — | Included | Not disclosed | — | |
| SoftHand Model-WSoftHand Model-W | University of Bristol | United Kingdom | — | Not disclosed | 5 fingers | — | 4 DOF | — | — | — | Not disclosed. | — | |
| DIST-HandDIST-Hand | University of Genoa | Italy | Prototype | Not released | 4 fingers | — | 16 DOF | — | — | — | Not disclosed | — | |
| TUAT/Karlsruhe Humanoid Hand Version 2 (2013)TUAT/Karlsruhe Humanoid Hand Version 2 (2013) | Karlsruhe Institute of Technology | Germany | Prototype | Not released | 5 fingers | — | 7 DOF | 0.49 kg | — | — | — | — | |
| UB Hand IIIUB Hand III | University of Bologna | Italy | Prototype | Not released | 5 fingers | — | 20 DOF | — | — | — | Not disclosed | — | |
| Belgrade/USC Hand Model IIBelgrade/USC Hand Model II | University of Southern California | United States | Prototype | Not disclosed | 5 fingers | 14 joints | 4 DOF | — | — | — | Not disclosed | — | |
| MIDAS HandMIDAS HandMIDAS Hand | RoMeLa | United States | — | Not disclosed | 4 fingers | — | 13 DOF | 0.7 kg | — | Included | — | — | |
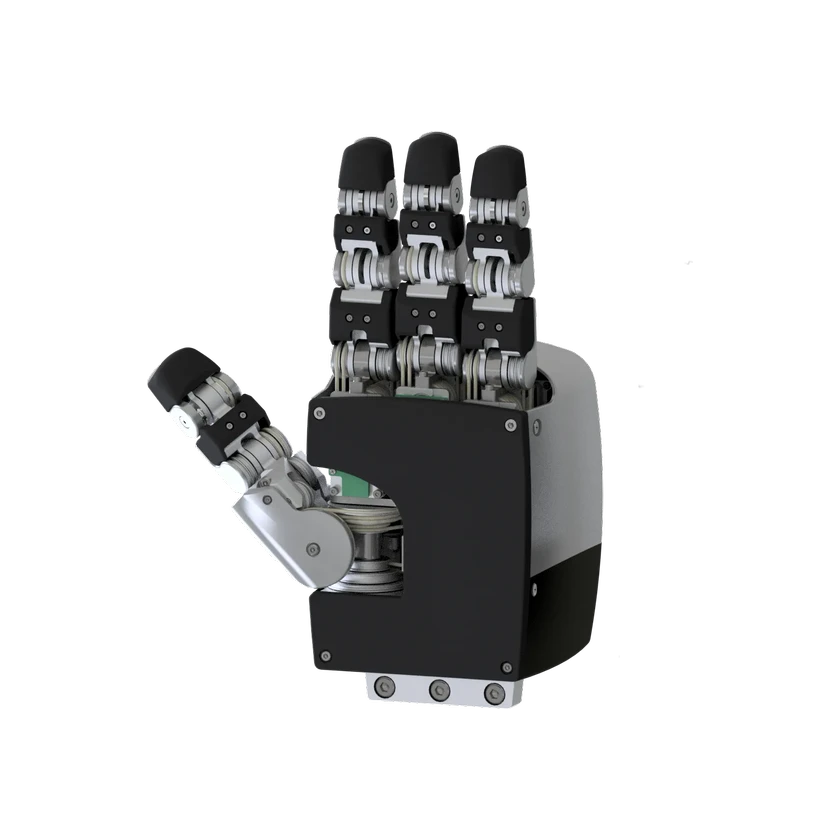 Torobo HandTorobo HandTorobo Hand | Tokyo Robotics | Japan | Commercial | On sale | 4 fingers | 16 joints | 12 DOF | 2 kg | — | Included | Price on request | — | |
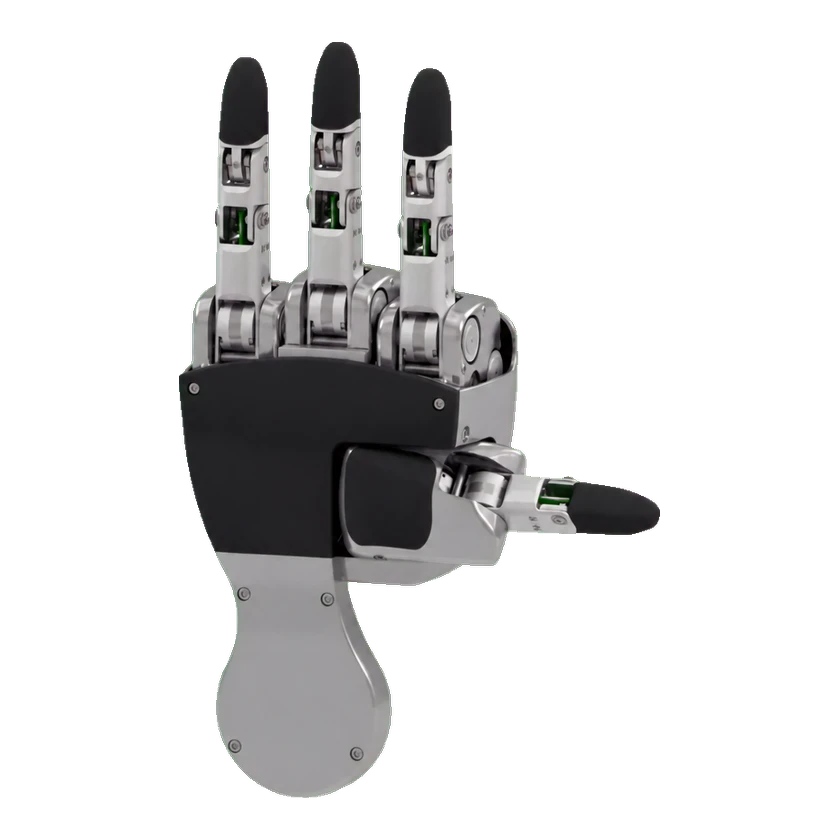 Torobo Hand Four-Finger Version 1Torobo Hand Four-Finger Version 1Standard ten-axis | Tokyo Robotics | Japan | Commercial | Not disclosed | 4 fingers | — | 10 DOF | 2.5 kg | — | Included | Not disclosed | — | |
| Tilburg HandTilburg Hand | Tilburg Robotics | Netherlands | Commercial | Pre-order | 4 fingers | — | 16 DOF | — | — | — | EUR 5,000 including EU VAT | — | |
| Eco12Eco12Eco12 Standard | Wanna Robotics (Beijing) Co., Ltd. | China | Commercial | On sale | 5 fingers | — | 7 DOF | ≤0.50 kg | RS485 · EtherCAT | — | Price not disclosed | — | |
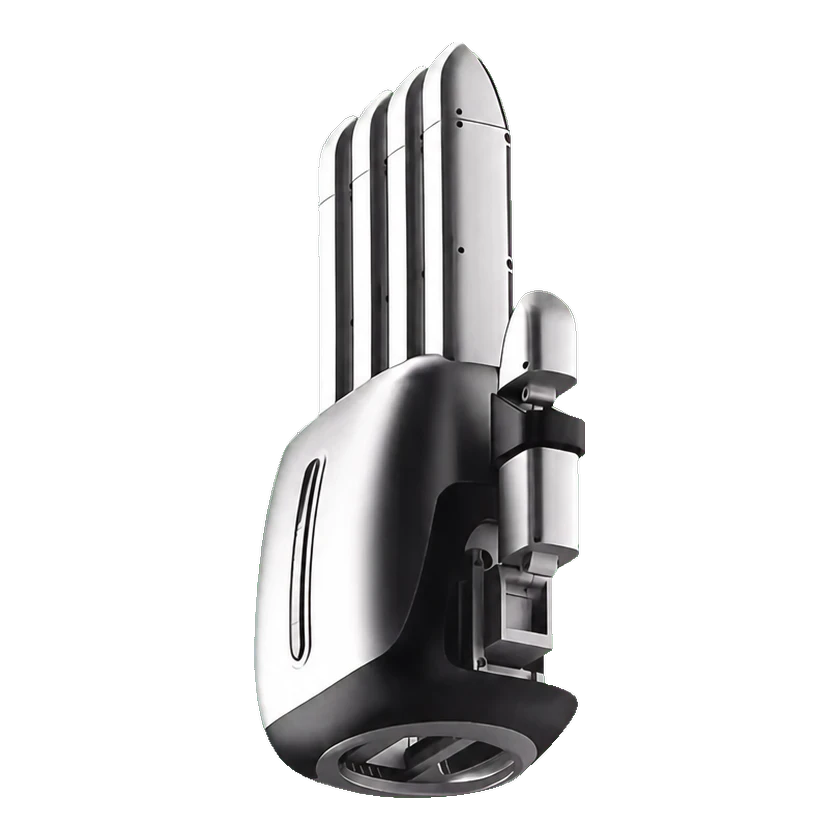 Std16AStd16AStd16A — Standard version | TheoHand | China | Commercial | Not disclosed | 5 fingers | — | 16 DOF | ≤1.10 kg | RS485 · EtherCAT | — | Price not disclosed | — | |
| Pantheon Hand 22Pantheon Hand 22 | Shenzhen Stellar Robot Technology Co., Limited | China | Commercial | Not disclosed | 5 fingers | — | 15 DOF | 2.26 kg | — | — | Not disclosed | — | |
| Kappa HandKappa Hand | Technical University of Munich | Germany | Prototype | Not disclosed | — | — | 16 DOF | — | — | — | Not disclosed | — | |
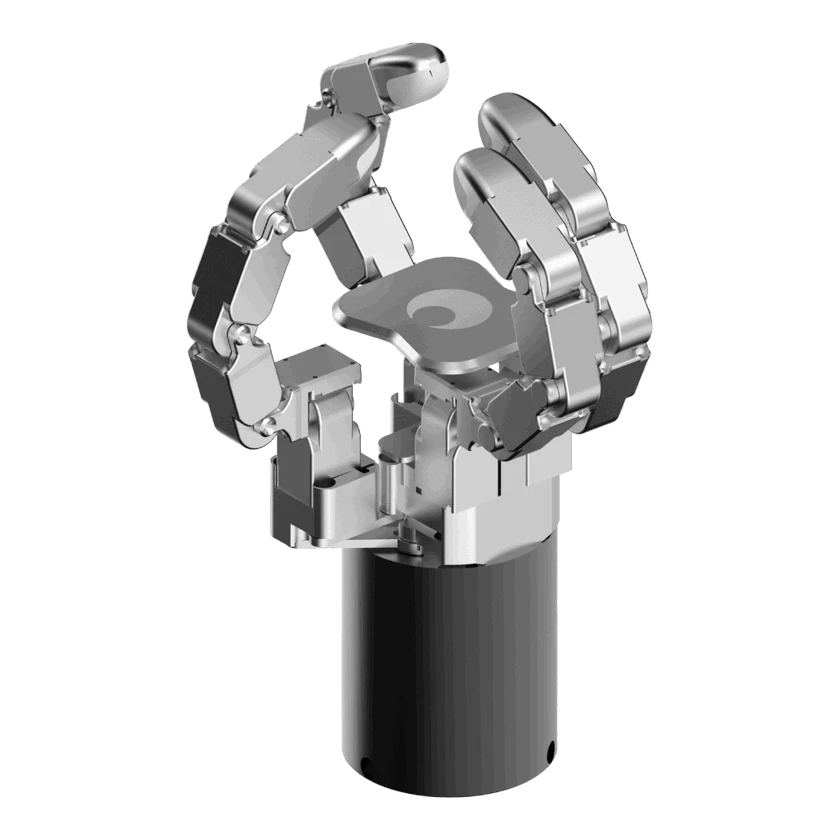 DG-4FDG-4FDG-4F — Manufacturer specification | Tesollo | South Korea | — | Not disclosed | 4 fingers | — | — | 1.49 kg | Ethernet (TCP / IP) | — | — | — | |
| SKK Robot Hand ISKK Robot Hand I | Sungkyunkwan University | South Korea | Prototype | Not disclosed | 3 fingers | — | — | — | — | — | Not disclosed | — | |
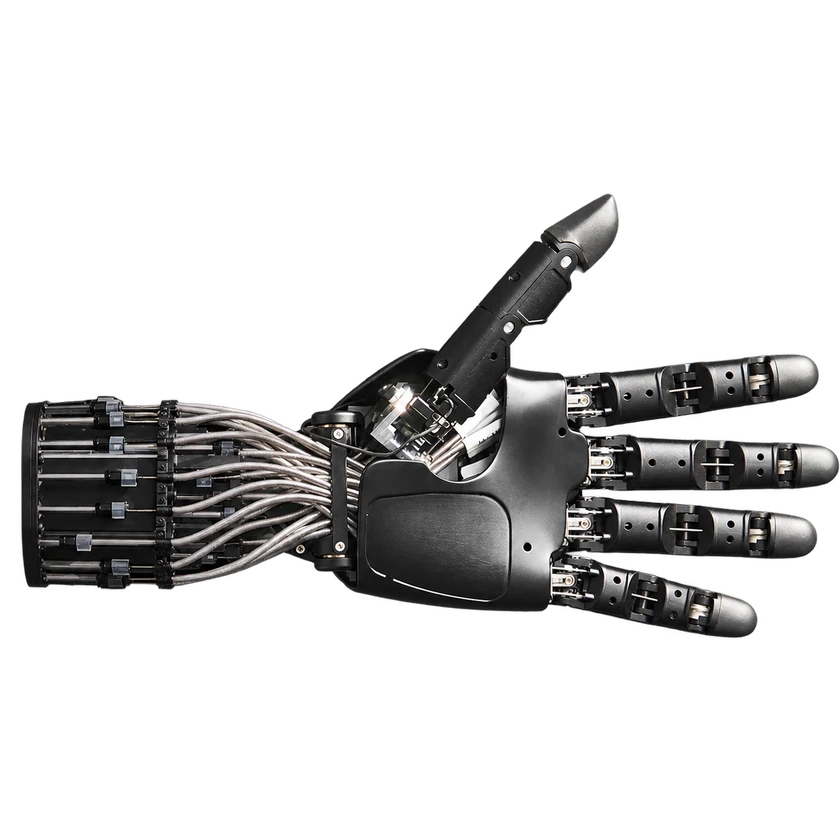 OctoH-HandOctoH-HandOctoH-Hand | SynapX | — | Commercial | Not disclosed | 5 fingers | — | 20 DOF | — | — | Included | Not disclosed | — | |
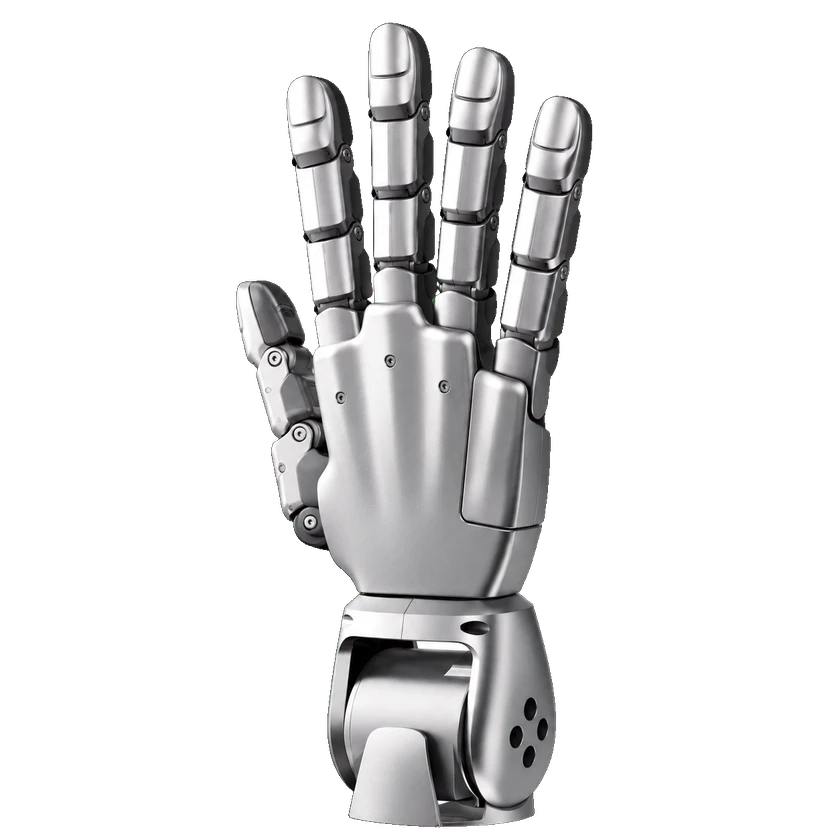 Dex5-SDex5-SDex5-S — Ethernet interface option | Unitree Robotics | China | Commercial | On sale | 5 fingers | — | 22 DOF | 0.62 kg | Ethernet | — | CNY 39,900+ | — |
Submit a source or correction