
DG-4F — Manufacturer specification
Communication and control
Communication interface
Ethernet (TCP/IP)
Official DG-4F specification. Tactile fingertips are optional, not asserted as standard equipment.
 Tesollo
DG-4F
DG-4F is Tesollo’s four-finger, 18-DoF multi-joint robotic gripper. Four independently controlled fingers and a flexible base-joint structure enable left-hand-like, right-hand-like, and conventional gripper configurations. Official specifications list 24 V input, a 10 A maximum current, absolute encoders, and optional fingertip sensors.
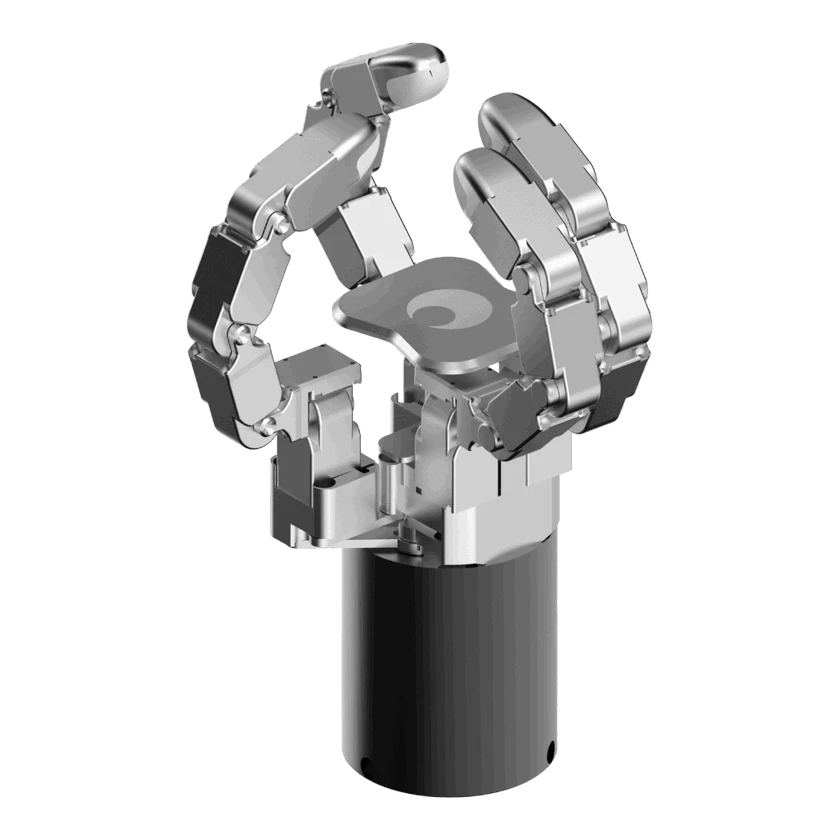
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Official DG-4F specification. Tactile fingertips are optional, not asserted as standard equipment.
Official DG-4F specification. Tactile fingertips are optional, not asserted as standard equipment.
Official DG-4F specification. Tactile fingertips are optional, not asserted as standard equipment.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
There is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | DG-4F official ROS 2 driver packages GitHub · tesollodelto/dg4f_ros2 BSD-3-Clause model-specific ros2_control, RViz, Gazebo and MoveIt 2 integration. Requires separate dg_hardware and dg_tcp_comm packages; initialize the correct submodules or standalone dependencies. External SDK binaries and firmware are not covered by this source-code claim. | BSD-3-Clause | DG-4F (18-joint official ROS 2/model package) | Open GitHub |
| Simulation | DG-4F official URDF and USD models GitHub · tesollodelto/tesollo_model BSD-3-Clause visual/collision meshes, URDF and Isaac Sim USD assets for DG-4F. The URDF and referenced mesh paths were checked; simulator runtime and physical fit were not tested. Simulation geometry is not a manufacturing drawing or complete parts list. | BSD-3-Clause | DG-4F (18-joint official ROS 2/model package) | Open GitHub |
| Guide | DG-4F ROS 2 integration and control guide tesollodelto.github.io Official setup for the 18-joint DG-4F, covering driver launch, position/effort controllers, MoveIt, mock hardware and optional sensor interfaces. Match delivered sensors and network settings. Documentation permission is unverified; programming guidance is not mechanical assembly or fabrication. | — | DG-4F (18-joint official ROS 2/model package) | Open documentation |
No related products recorded yet.