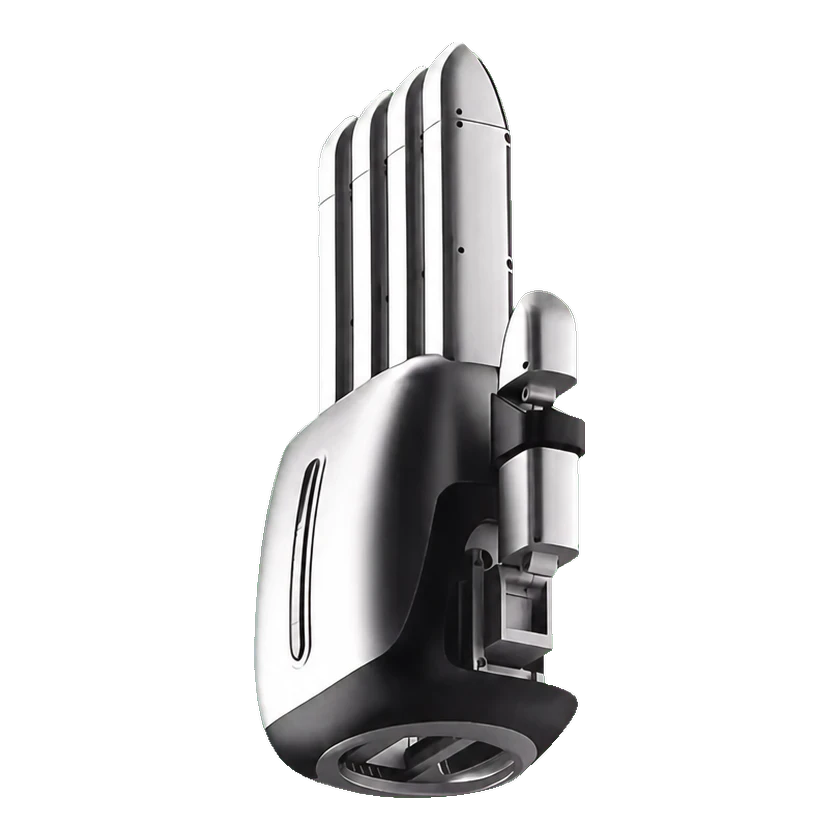
Std16A — Standard version
Communication and control
CAN FD is a customizable option, not confirmed as the standard interface supplied.
This record is for the non-tactile Std16A configuration only.
Std16A
TheoHand Std16A is a dexterous hand for industrial sorting, warehouse logistics, and precise manipulation. Its official page states 16 active degrees of freedom, electric-cylinder direct drive, EtherCAT and RS485 communication, and OTA upgrade support; published specifications use laboratory standard test conditions.

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
At 24 V supply under standard laboratory conditions.
Typical values under standard laboratory conditions; actual performance depends on environment, equipment and the delivered product.
CAN FD is a customizable option, not confirmed as the standard interface supplied.
Typical values under standard laboratory conditions; actual performance depends on environment, equipment and the delivered product.
Examples or supporting tools are available; this does not establish access to the core system.
Official product manual with outline/flange drawings, connector definitions and communication/setup notes. Match the delivered configuration; document reuse terms are unverified. Mounting a finished hand is not manufacturing the hand or a complete DIY package.
View explanationThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Simulation | Std16A official left/right URDF package theo-hand.com Official downloadable URDF and visual/collision meshes for both hands. Archive integrity, XML and mesh references were checked, not simulator execution or physical fit. No explicit reuse license was found; simulation exports are not manufacturing CAD. | — | Std16A (official left/right URDF package) | Open documentation |
| Hardware | Std16A mounting and electrical interface manual theo-hand.com Official product manual with outline/flange drawings, connector definitions and communication/setup notes. Match the delivered configuration; document reuse terms are unverified. Mounting a finished hand is not manufacturing the hand or a complete DIY package. | — | Std16A (delivered interface configuration) | Open documentation |
| Guide | TheoHand SDK V2.1 programming manual theo-hand.com Official C++/Python interface and Modbus RTU setup documentation. The two model download entries provide identical PDFs. Its source-retrieval example points to a private-network Git service, so public SDK source availability and reuse permission are not verified. Not assembly instructions. | — | Std16A (SDK manual V2.1) | Open documentation |