
Flex 2 — product manual V1.2 specification
Communication and control
Communication interface
CAN FD
Communication interface
EtherCAT
Sensing
Has tactile sensing
Yes
 Xynova
 Flex 2 is an integrated forearm-hand hybrid-drive dexterous hand developed by Xynova for humanoid robot integration, object grasping, and precision manipulation. According to company materials, forearm micro linear actuators transmit force through tendons for high-force grasping, while palm-mounted direct-drive motors support fine motion; full-palm tactile sensing, wrist vision, and palm proximity sensing provide multimodal perception. It has 23 DoF, a 12 kg peak single-hand grasp load, a 4 kg continuous rated load, and 0.05 N force-control accuracy, with adaptive grasping and slip detection.
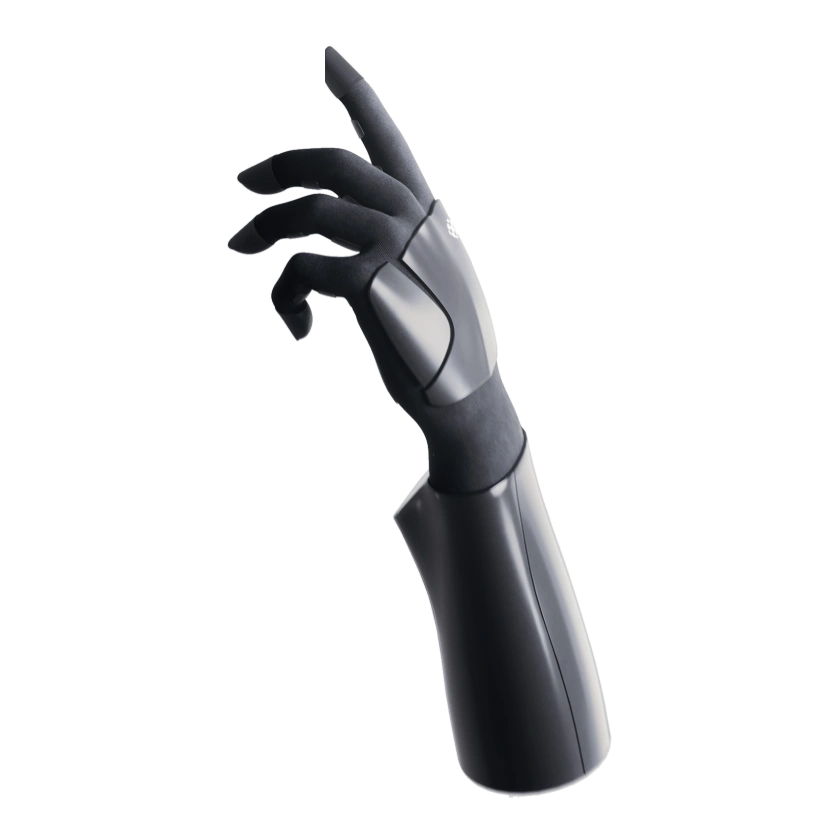
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Surface mapping follows the standard-parameter table on page 5: 3D at fingertips and palm, 1D at finger pads. The narrative on page 8 uses a different surface description; the exact mapping remains pending confirmation. Module values on page 9 are not whole-hand electrical specifications.
No related products recorded yet.