
Standard ten-axis
Sensing
Has tactile sensing
Included
Ten-axis hand specification from manufacturer release; not the earlier six-axis beta configuration.
 Tokyo Robotics
Torobo Hand Four-Finger Version 1
A 10-axis four-finger robotic hand for robotics research and object manipulation. Its in-house compact cycloidal reduction gears enable impedance control, letting the hand conform to object shapes while helping prevent finger jamming. Left- or right-hand versions are selectable; a controller, ROS package and user manual are supplied.
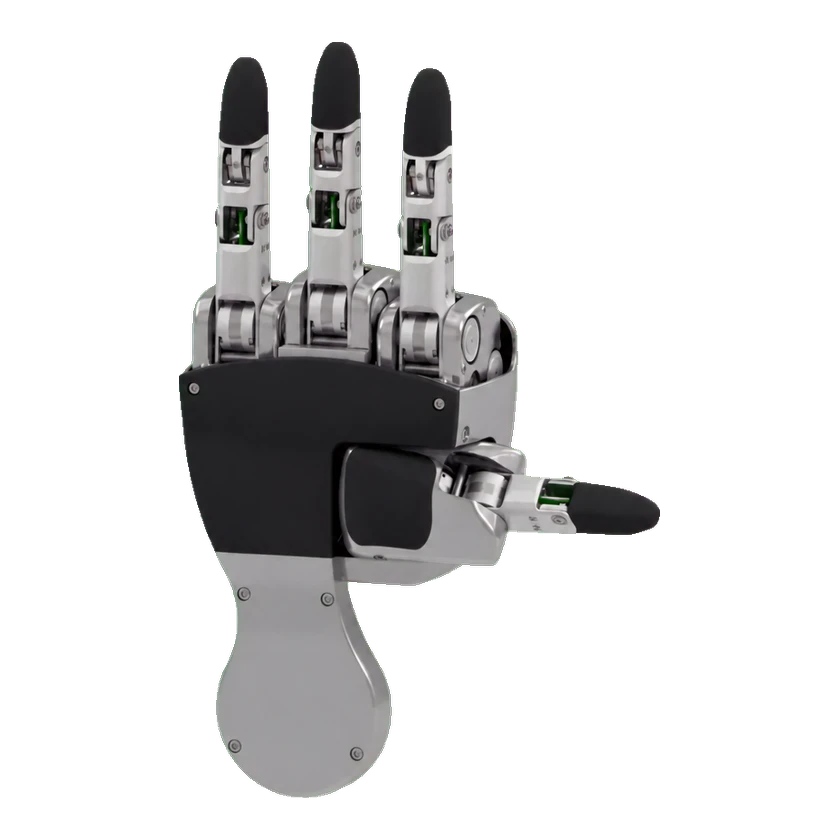
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Four Finger ver.1 ten-axis hand; not the earlier six-axis beta hand.
Ten-axis hand specification from manufacturer release; not the earlier six-axis beta configuration.
No related products recorded yet.