
Dexterous hand database
Browse source-backed dexterous hand products by specifications, availability, company, and commercial status.
193 product families · 292 models
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Hand weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
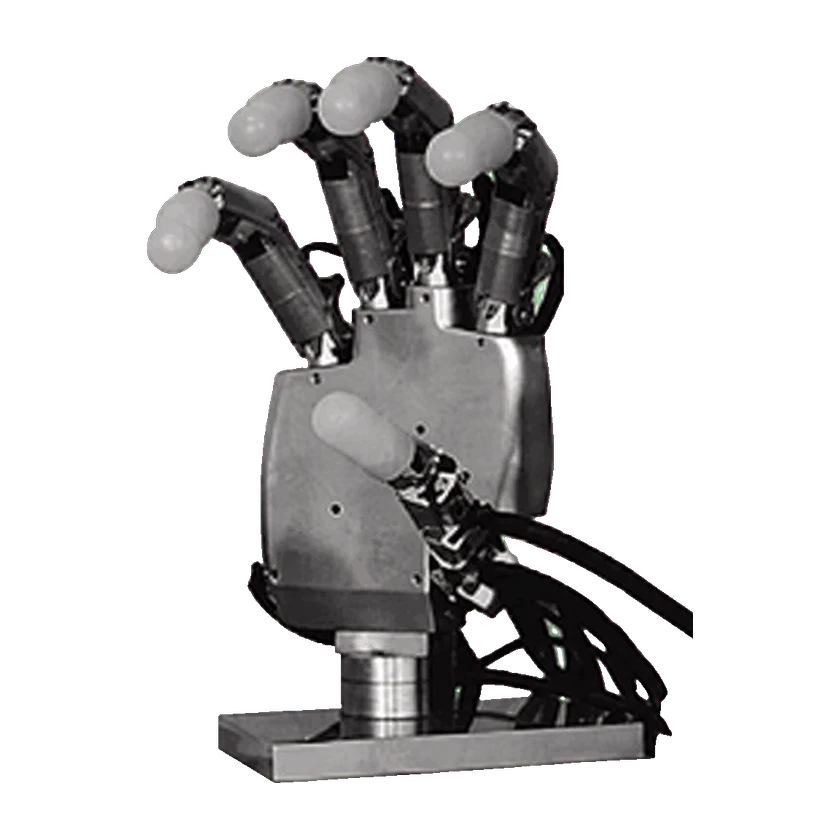 Gifu Hand IGifu Hand I | Gifu University | Japan | — | Not disclosed | 5 fingers | 20 joints | 16 DOF | 1.2 kg | — | — | Not disclosed | 2026-09-13 | |
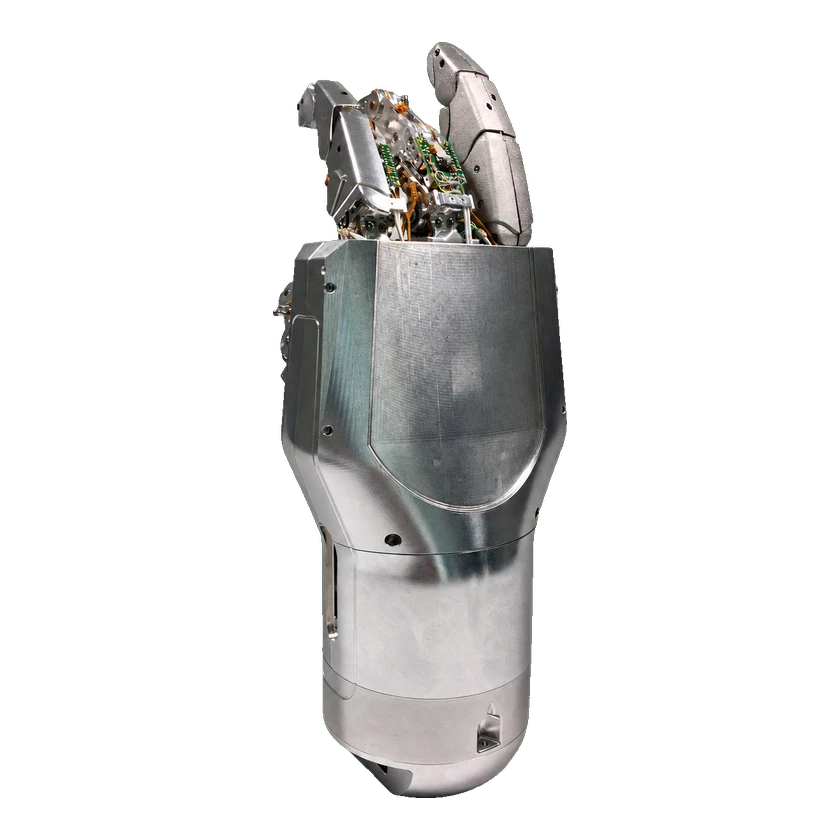 SpacehandSpacehandDocumented Spacehand | German Aerospace Center (DLR) | Germany | — | Not disclosed | 4 fingers | — | 12 DOF | — | SpaceWire (LVDS) | — | Unknown | 2026-09-13 | |
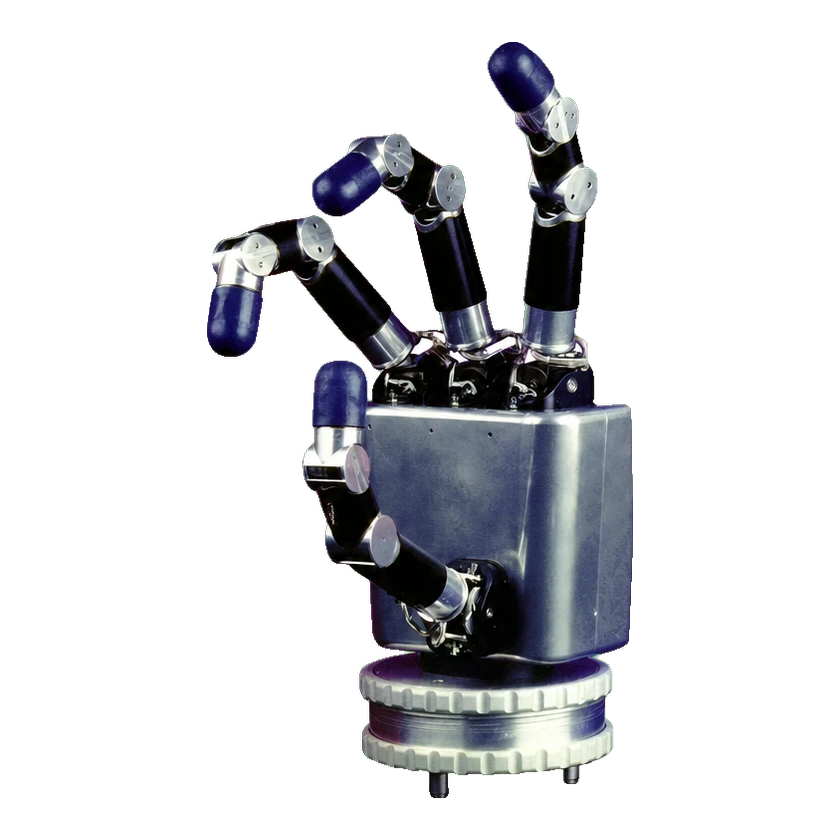 DLR Hand IDLR Hand IDLR Hand I (1998) — Documented tactile hardware | German Aerospace Center (DLR) | Germany | — | Not disclosed | 4 fingers | — | 12 DOF | 1.8 kg | — | Included | — | 2026-09-13 | |
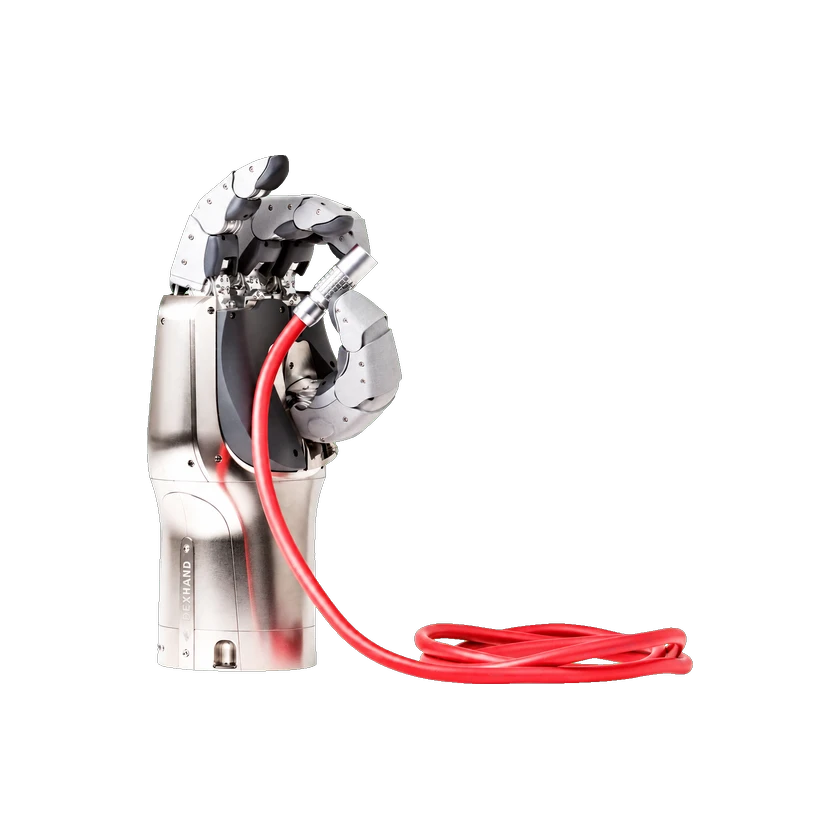 DEXHANDDEXHANDDEXHAND — documented CAN capability | German Aerospace Center (DLR) | Germany | — | Not disclosed | 4 fingers | 12 joints | 12 DOF | 4 kg | CAN | — | — | 2026-09-13 | |
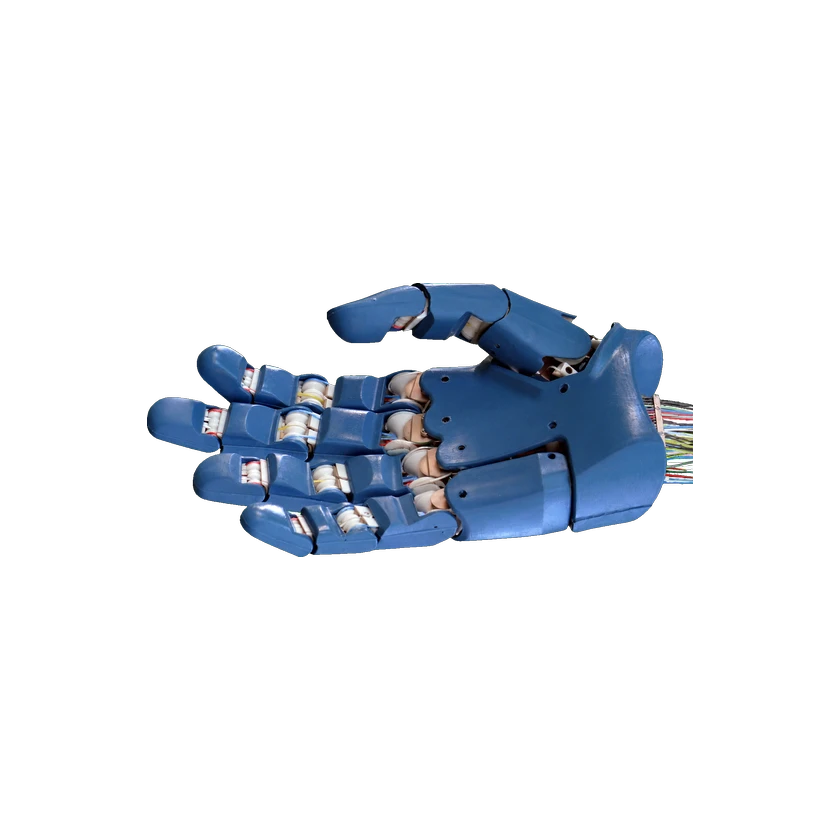 Awiwi HandAwiwi Hand | German Aerospace Center (DLR) | Germany | — | Not disclosed | 5 fingers | — | 19 DOF | — | — | — | — | 2026-09-13 | |
 David-HandDavid-Hand | German Aerospace Center (DLR) | Germany | — | Not disclosed | 5 fingers | — | 20 DOF | 4.5 kg | — | — | Unknown | 2026-09-12 | |
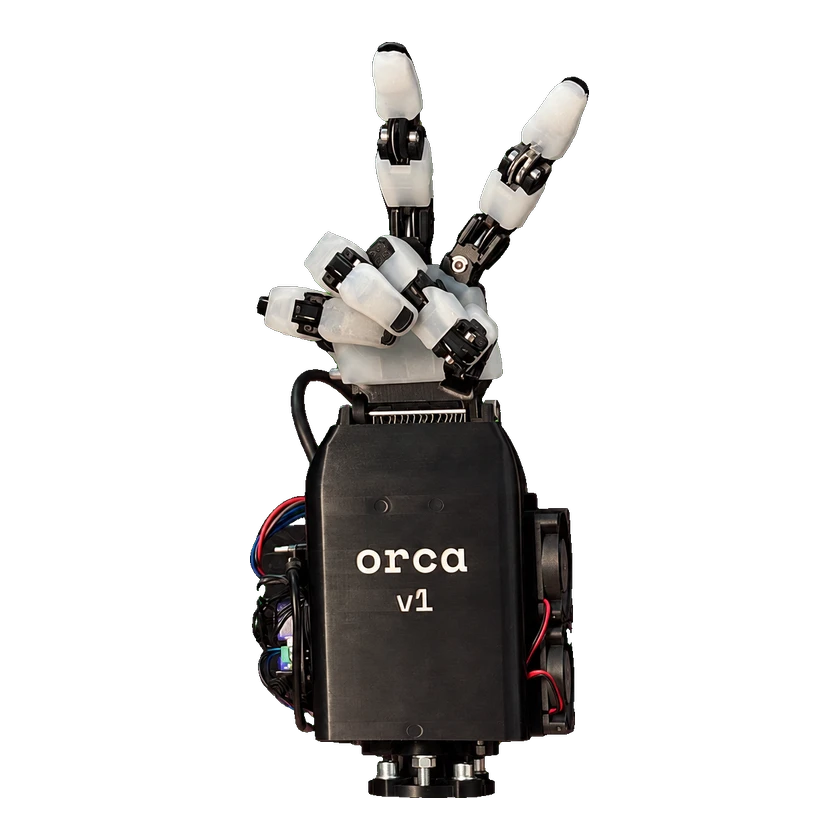 ORCA Hand v1ORCA Hand v1ORCA Hand V1 — Documented tactile hardware | ETH Zurich | Switzerland | — | Not disclosed | 5 fingers | 17 joints | 17 DOF | — | — | Included | — | 2026-09-13 | |
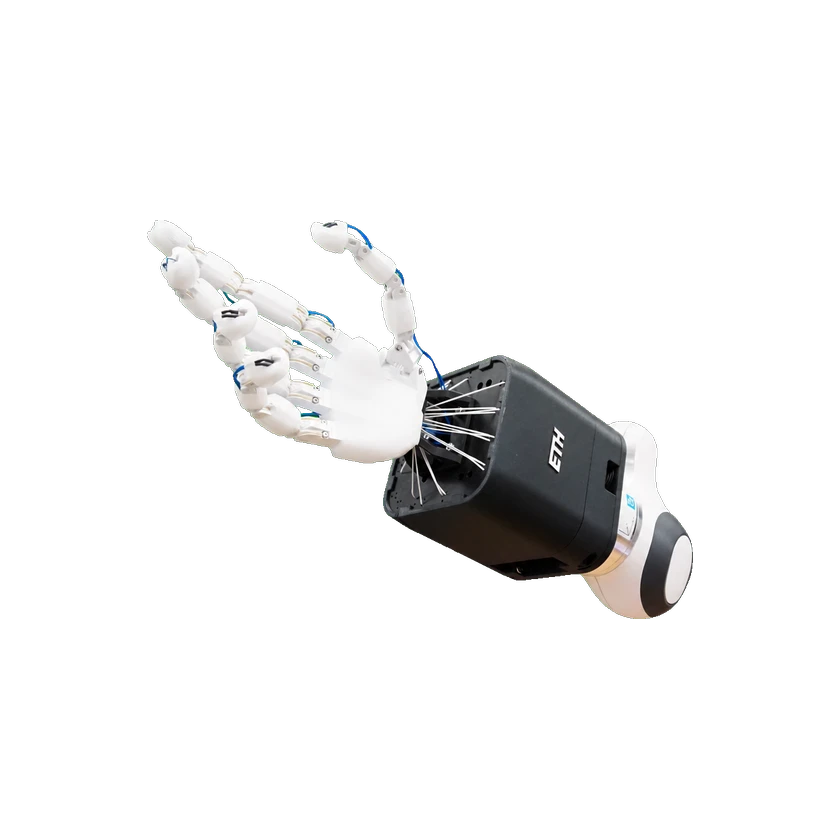 FAIVE HandFAIVE HandFAIVE Hand — ICRA 2024 sensorized-skin experiment | ETH Zurich | Switzerland | Prototype | Not released | 5 fingers | 16 joints | 11 DOF | 1.1 kg | — | Included | — | 2026-09-13 | |
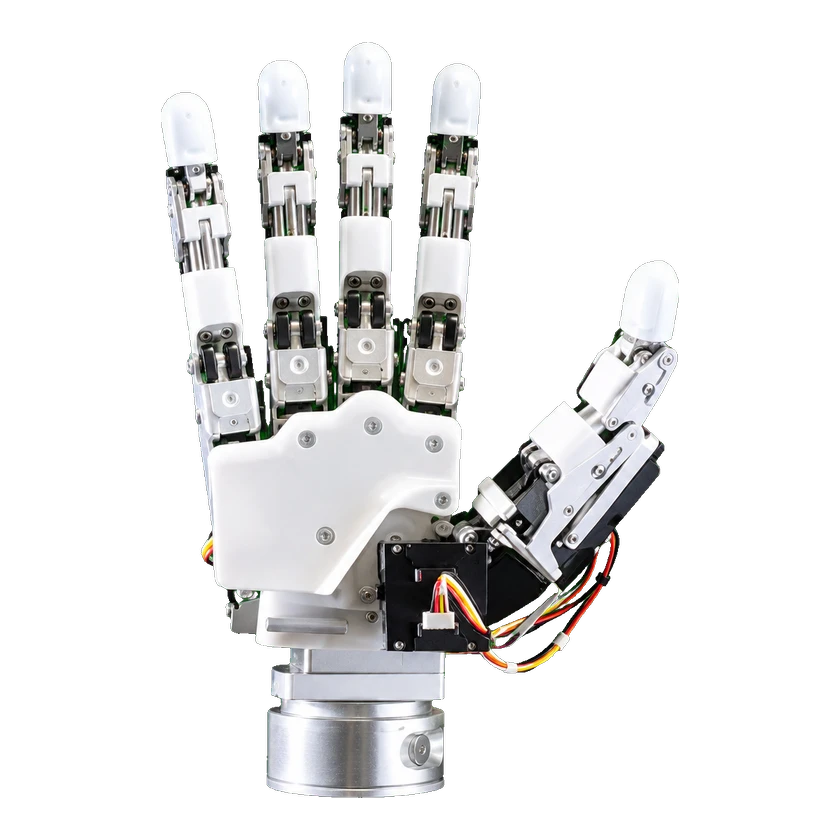 D-HAND 5STD-HAND 5STDefault | DOUBLE Research and Development Co., Ltd. | Japan | Commercial | Not disclosed | 5 fingers | — | 6 DOF | 0.45 kg | 2.4 GHz wireless · UART | — | Not disclosed | 2026-09-13 | |
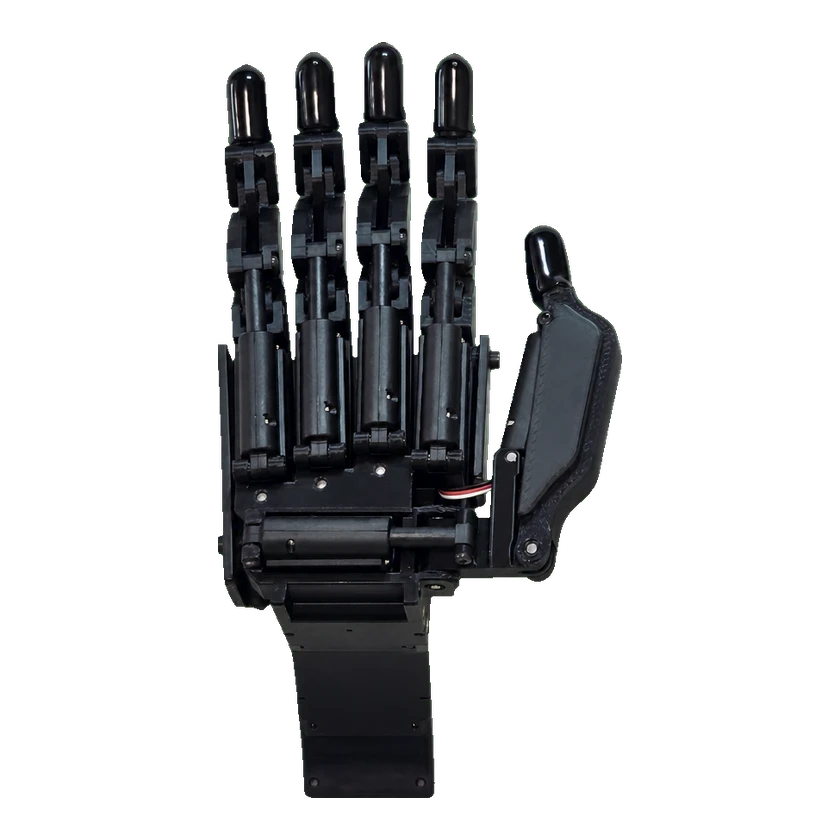 CR HandCR HandStandard | Curious Robotics Inc. | — | — | On sale | 5 fingers | 13 joints | 6 DOF | 0.33 kg | USB | — | USD 1,500 | 2026-09-13 | |
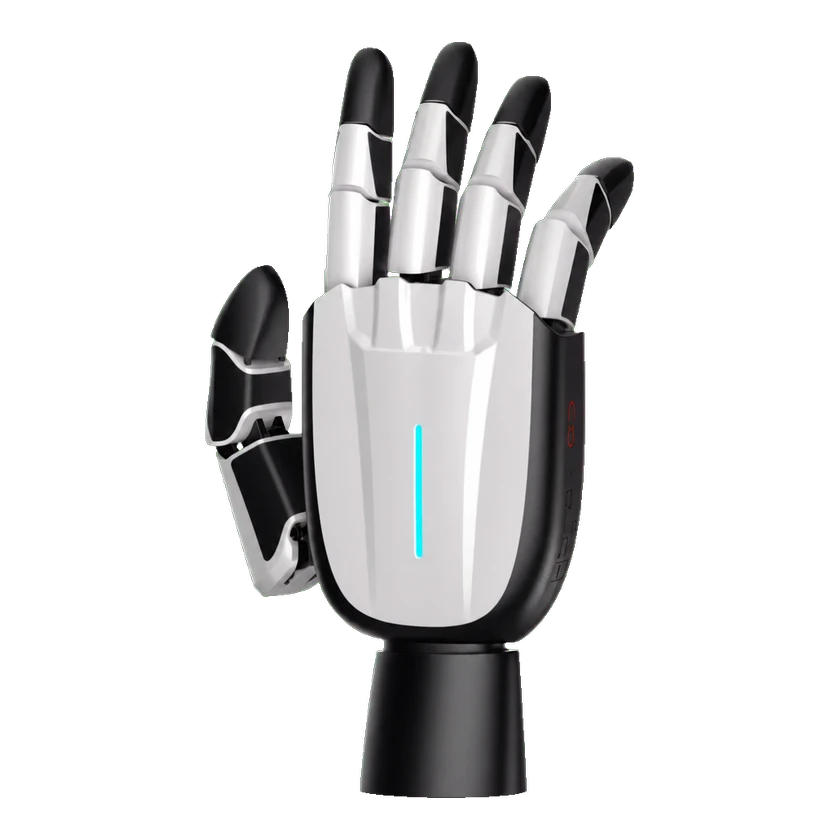 MozartMozart | Chundong Touch | China | Prototype | Not released | 5 fingers | — | 6 DOF | 0.84 kg | — | — | Not disclosed | 2026-09-13 | |
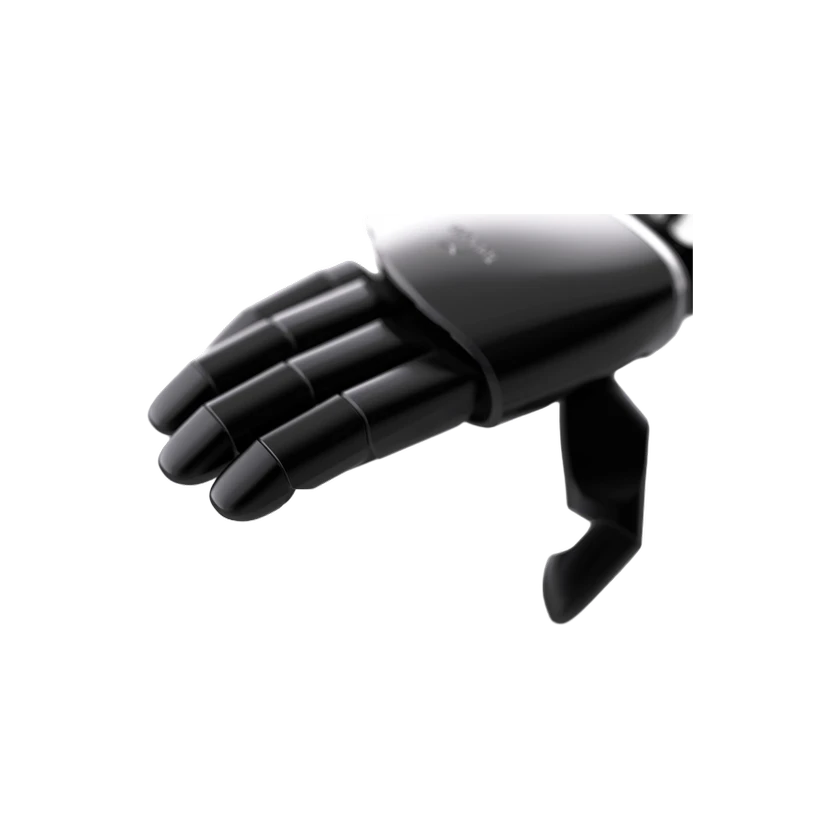 Aero HandAero HandAero Hand — manufacturer specification | Chestnut Robotics | United States | — | Not disclosed | 5 fingers | — | 15 DOF | ≤0.80 kg | CAN-FD | Included | Unknown | 2026-09-13 | |
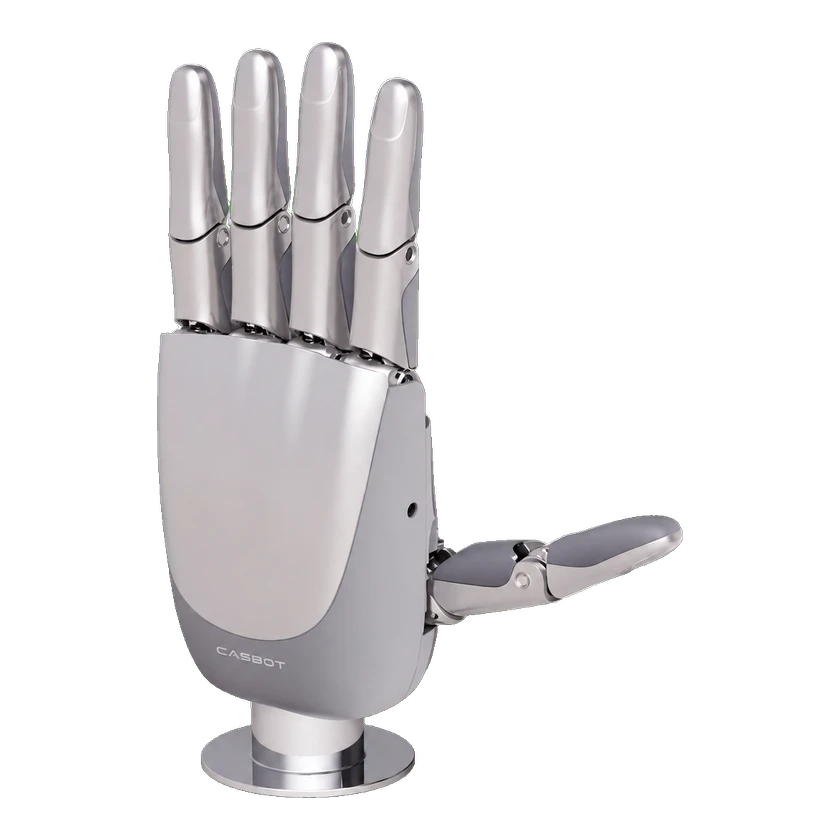 Handle-L1Handle-L1Handle-L1 — Pro tactile configuration | Beijing Zhongke Huiling Robot Technology Co., Ltd. | China | Commercial | On sale | 5 fingers | — | 6 DOF | 0.61 kg | RS485 · CAN-FD · EtherCAT | Included | — | 2026-09-13 | |
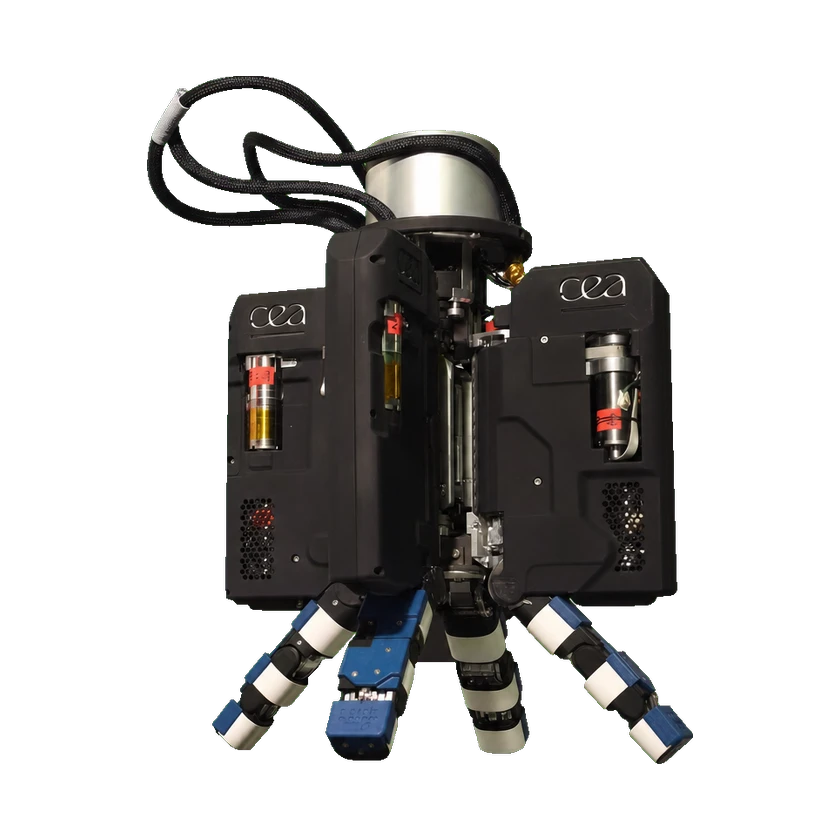 AbilisAbilisAbilis — Documented tactile hardware | CEA-List | France | Prototype | Not released | 4 fingers | — | 14 DOF | — | — | Included | — | 2026-09-13 | |
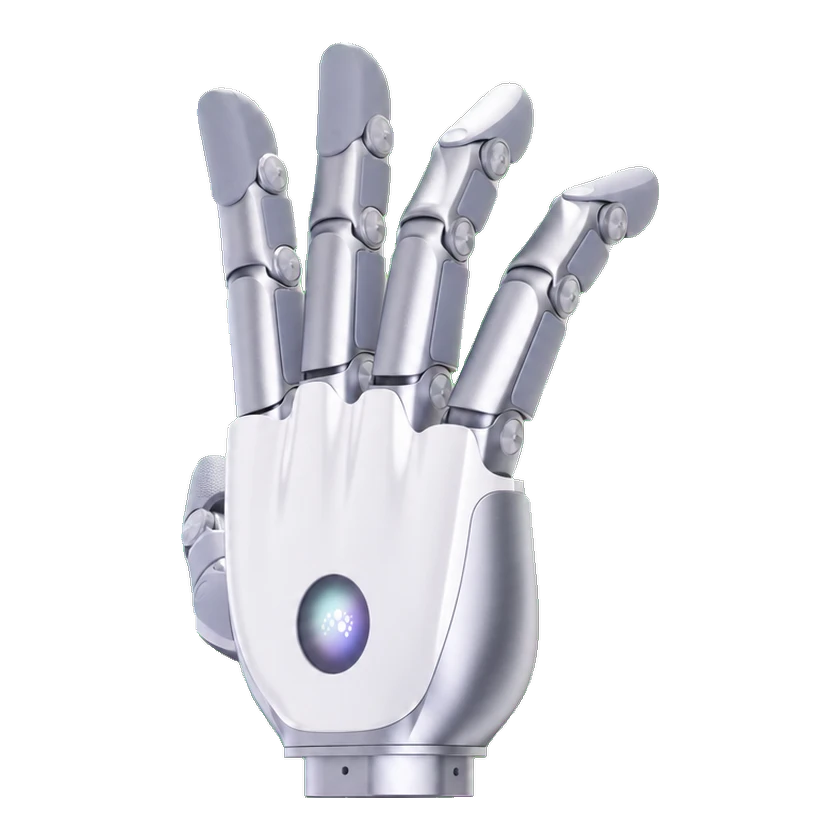 Revo 3Revo 3Revo 3 U21 | BrainCo | China | Commercial | Not disclosed | 5 fingers | — | 21 DOF | — | RS485 · CAN-FD · EtherCAT | — | — | 2026-09-13 | |
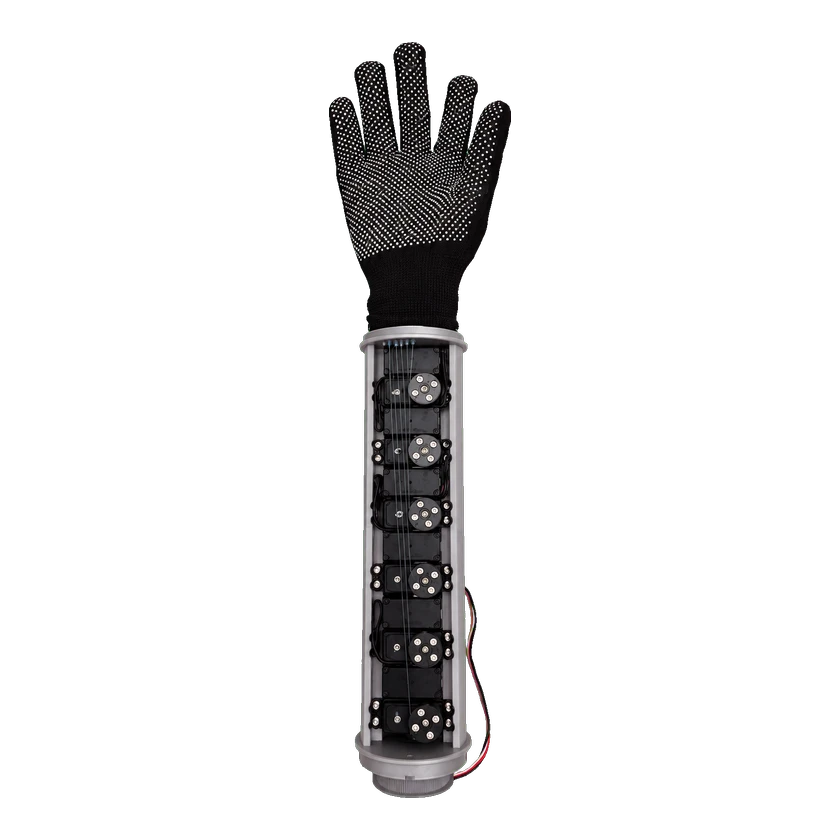 DexKit V0DexKit V0DexKit V0 — documented pinch-gauge test | Carnegie Mellon University | United States | Prototype | Not released | 5 fingers | — | 12 DOF | — | — | — | Not disclosed | 2026-09-12 | |
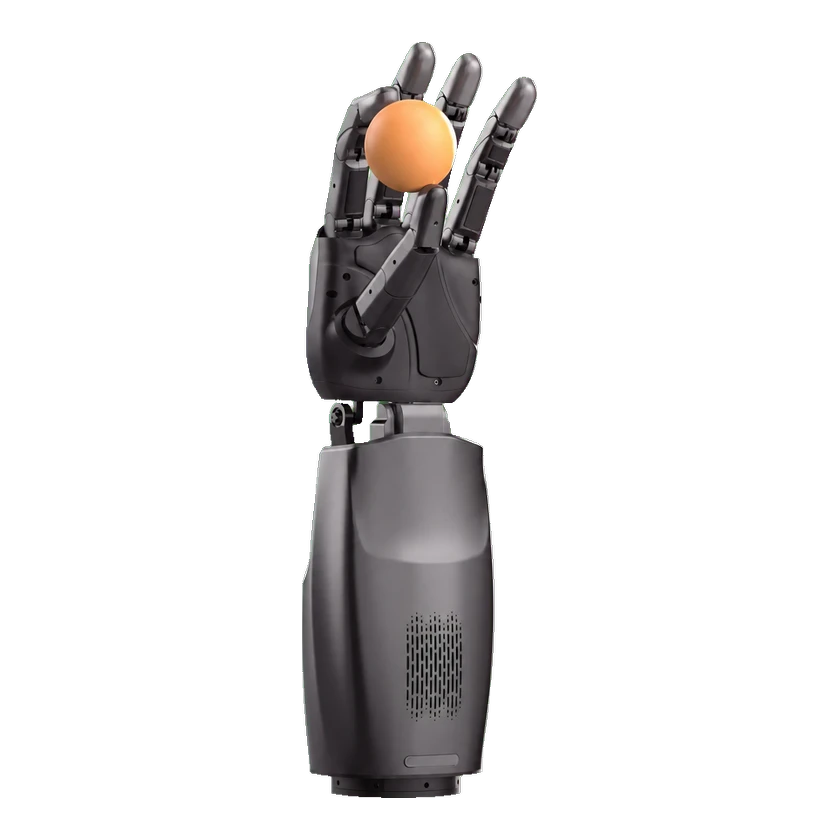 Gaoshan S1Gaoshan S1S1-L-FT — left fingertip-tactile hand | Botyard Intelligence | China | Commercial | Not disclosed | 5 fingers | 22 joints | 18 DOF | 1.8 kg | EtherCAT · RS485 · CAN-FD | Included | — | 2026-09-13 | |
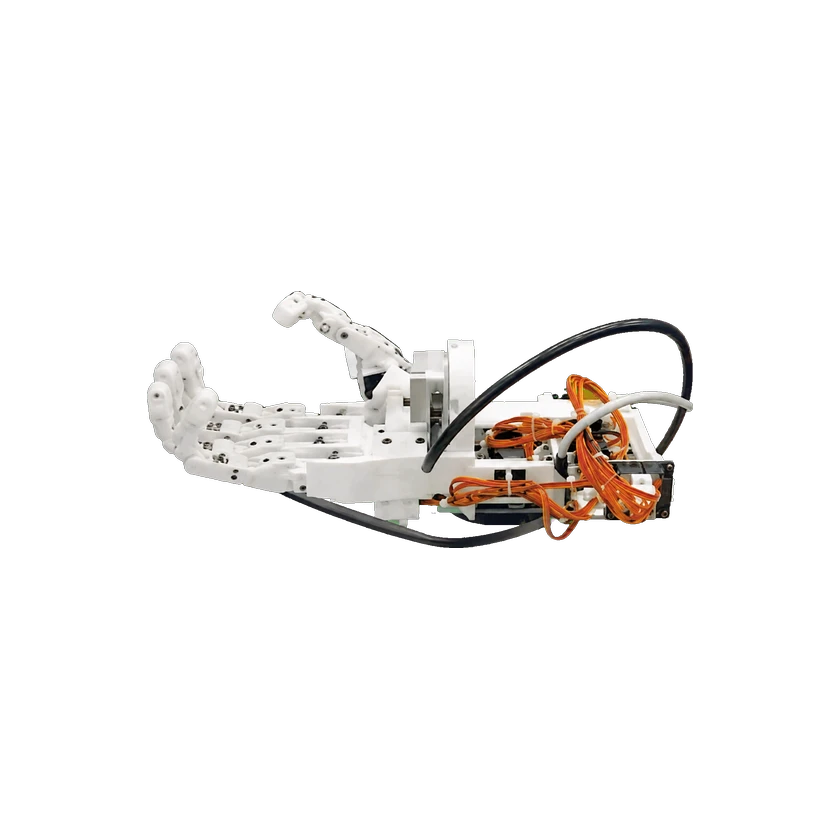 BiDexHand V4BiDexHand V4V4 PWM / Servo2040 | BiDexHand Project | — | — | Not disclosed | 5 fingers | 21 joints | 16 DOF | — | USB | — | — | 2026-09-12 | |
 NEO HandsNEO HandsNEO Hands | 1X Technologies | United States | — | Not disclosed | 5 fingers | 25 joints | 22 DOF | — | — | Included | — | 2026-09-13 | |
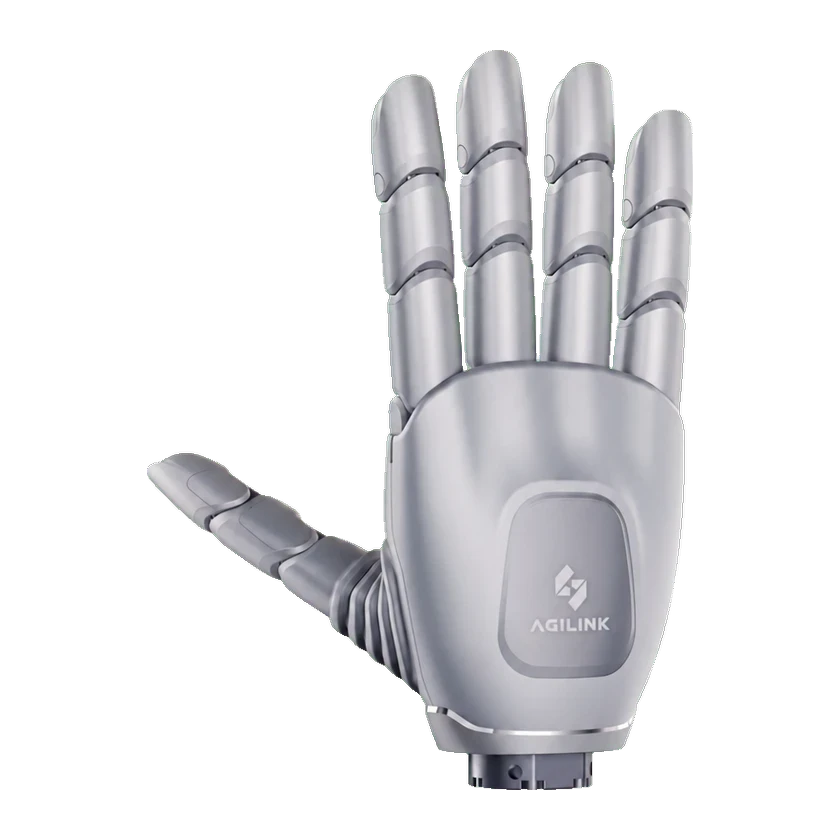 OmniHand 3 Ultra-MOmniHand 3 Ultra-MOmniHand 3 Ultra-M — documented standard configuration | AGILINK | China | — | Not disclosed | 5 fingers | — | 20 DOF | 0.63 kg | CAN-FD · RS485 · EtherCAT | Included | — | 2026-09-12 | |
 KAIST HandKAIST Hand | KAIST | South Korea | Prototype | Not released | 3 fingers | — | — | — | — | — | — | 2026-09-13 | |
 DLR-HIT Hand IIDLR-HIT Hand IIDLR/HIT Hand II — research configuration documented in 2016 | Harbin Institute of Technology | — | Prototype | Not disclosed | 5 fingers | 20 joints | 15 DOF | 1.5 kg | — | Included | — | 2026-09-12 | |
 Version I Utah/M.I.T. Dextrous HandVersion I Utah/M.I.T. Dextrous Hand | MIT | United States | Prototype | Not disclosed | 4 fingers | 16 joints | 16 DOF | — | — | — | — | 2026-09-13 | |
 UW HandUW HandUW Hand — documented research prototype | University of Washington | United States | — | Not disclosed | 5 fingers | — | 20 DOF | — | — | Not included | Unknown | 2026-09-13 |
Submit a source or correction