Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
2012
Country/Region
Germany
Latest parameter verification
2026-10-31
12 DOF
Active degrees of freedom
12 active joints
Mechanical joint count
4 kg
Hand weight
4
Finger count

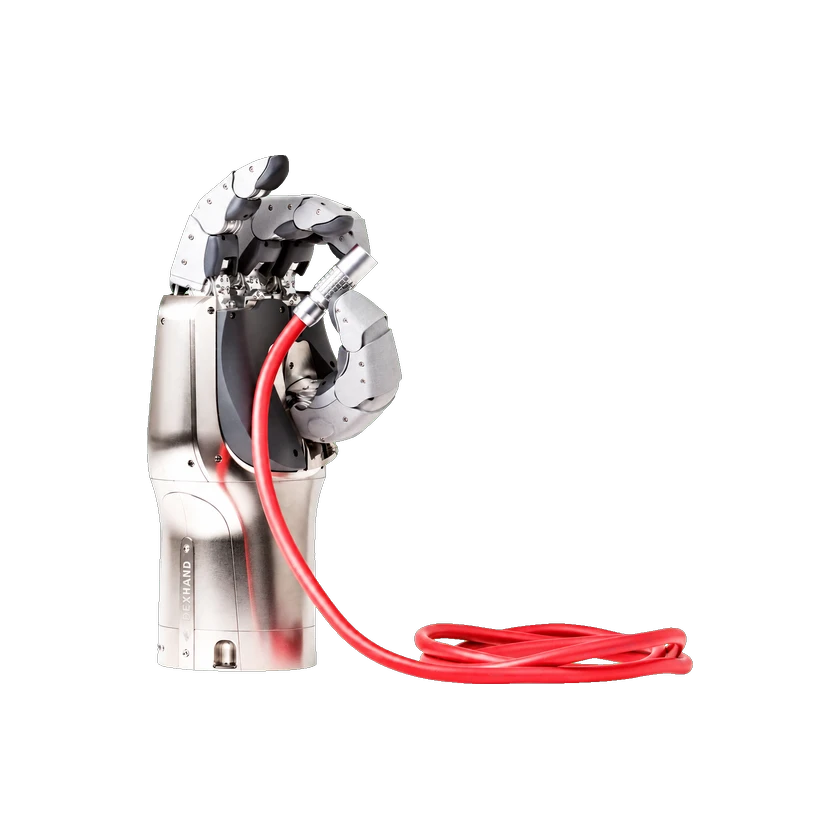
DLR developed DEXHAND for research into on-orbit servicing and astronaut assistance. The four-finger hand uses geared motors, tendon transmission, joint-torque sensing and impedance control. DLR lists CAN, SpaceWire and EtherCAT communication capabilities. These documentation profiles do not establish delivery variants or simultaneous installation; the space-oriented design is not evidence of completed flight qualification.

1 / 1DEXHAND

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
4
Actuator count
12
Actuator technology
Geared motor
Frame Material
Aluminum finger segments
Active degrees of freedom
12 DOF
Mechanical joint count
12 active joints
Materials
Conductive aluminum shell and polymer Dyneema tendons
Transmission mechanism
Tendon transmission
Actuator Model
DLR/Robodrive ILM 25 with HFUC 8 harmonic drive (100:1)

Mechanical and mounting

Hand weight
4 kg

DLR official DEXHAND system specification: hand weight 4 kg. Do not substitute the 46 g drive-unit weight from the 2011 paper.

Mechanical Structure

Dexterous Hand
Multi-finger robotic research hand designed for on-orbit servicing.

The current DLR page describes the hand as space-qualifiable. This entry does not claim completed flight qualification or deployment in orbit.

Joint Encoder
Hall-effect reference sensors; no absolute position sensors
Joint Sensor Type
Full strain-gauge torque sensors
Joint Type
Cardanic MP base joint; fixed 1:1 PIP–DIP coupling
Motor Mass
0.046 kg
Motor Peak Torque
9 N·m

Sensors

Force/Torque Sensor
Strain-gauge torque sensors
Sensors
Strain-gauge torque, Hall-effect reference and temperature sensors

Compute Platform

Processor
DSP/FPGA
Software Algorithm
Joint impedance control

Interaction and Communication

Communication
CAN bus with VxWorks communication controller

Configurations

DEXHAND — documented CAN capability

Communication and control

Communication interface
CAN

DLR lists this communication capability on its DEXHAND (2012–2015) system page. This documentation profile does not establish a separately orderable SKU, connector pinout, delivery default, or simultaneous installation of all listed communication systems.

DEXHAND — documented SpaceWire capability

Communication and control

Communication interface
SpaceWire

DLR lists this communication capability on its DEXHAND (2012–2015) system page. This documentation profile does not establish a separately orderable SKU, connector pinout, delivery default, or simultaneous installation of all listed communication systems.

DEXHAND — documented EtherCAT capability

Communication and control

Communication protocol
EtherCAT

DLR lists this communication capability on its DEXHAND (2012–2015) system page. This documentation profile does not establish a separately orderable SKU, connector pinout, delivery default, or simultaneous installation of all listed communication systems.

Commercial Status

Status
Unknown
Price
Unknown
Release Date
2012
Submit a source or correction