Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
Unknown
Latest parameter verification
2026-10-31
16 DOF
Active degrees of freedom
21
Mechanical joint count
5
Finger count

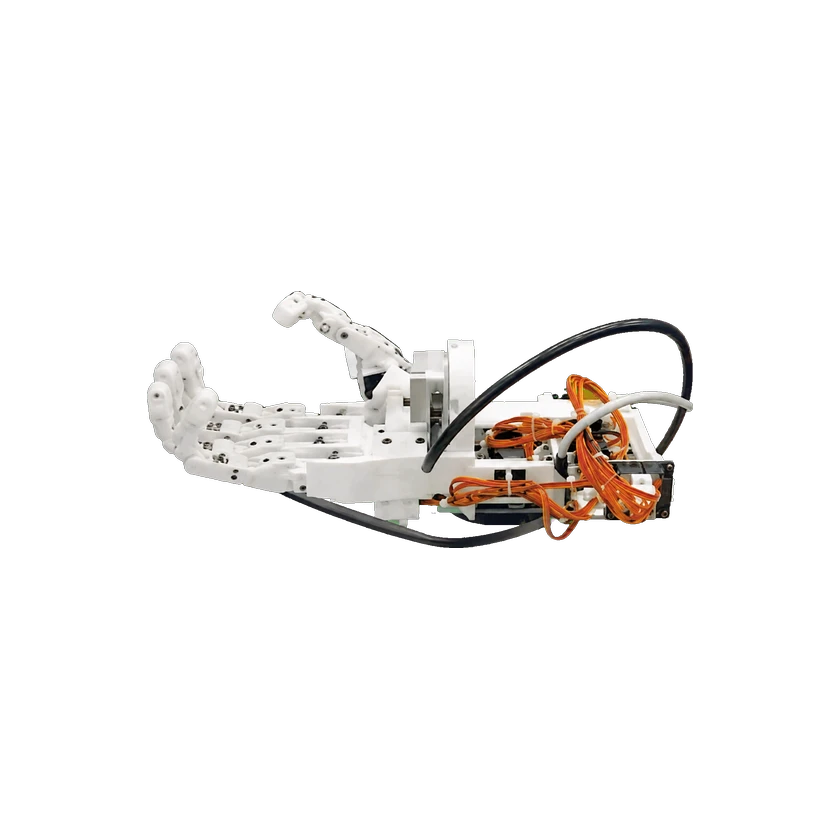
BiDexHand V4 is an open-source cable-driven biomimetic dexterous hand created by Zhengyang Kris Weng. It combines 16 independently actuated degrees of freedom with five mechanically coupled joints and uses a ROS 2 control framework. Public CAD, bill-of-materials and software resources accompany joint-level, task-based and vision-based motion-shadowing control. Reported evaluation includes all 33 GRASP taxonomy poses, a 9/11 Kapandji score, 2.14 N average peak fingertip force, and a demonstrated 10 lb lift. The project describes it as a low-cost platform for the research community.

1 / 1BiDexHand V4

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator count
16
Actuator technology
Servo motor
Coupled degrees of freedom
5 DOF
Frame Material
3D-printed parts
Active degrees of freedom
16 DOF
Mechanical joint count
21
Materials
Includes 3D-printed parts, PTFE tubing, stainless steel, alloy steel, bronze and brass
Transmission mechanism
Cable-driven
Actuator Model
FeeTech FT90M (PWM); SCS009 (SCS Bus)

Motion and coordination

Control channel count
16
Hand Payload
4.54 kg

Mechanical Structure

Joint Type
Four-bar linkage
Operating voltage
6 V

Sensors

Camera
Intel RealSense D405 wrist camera
Depth Camera
Intel RealSense D405
Vision Sensor
RGB camera

Battery and Runtime

Power Supply
6 V, 5 A power supply (PWM version)
Teleoperation support
Supported

Compute Platform

Operating System
ROS 2 Jazzy
Processor
ESP32 (SCS Bus version)
Software Algorithm
ROS 2 open-loop position control

Interaction and Communication

Communication
Serial communication
Remote Controller
VR headset

Development and Expansion

Operating Modes
Joint-level control; task-based control; motion shadowing

Configurations

V4 PWM / Servo2040

Communication and control

Communication interface
USB

Documented V4 PWM/Servo2040 build; the SCS bus alternative points to the V3 fork and is not asserted for this configuration.

Software and resources

ROS compatibility
ROS 2 Jazzy

Documented V4 PWM/Servo2040 build; the SCS bus alternative points to the V3 fork and is not asserted for this configuration.

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Unknown
Submit a source or correction