RoboAtlas Summary
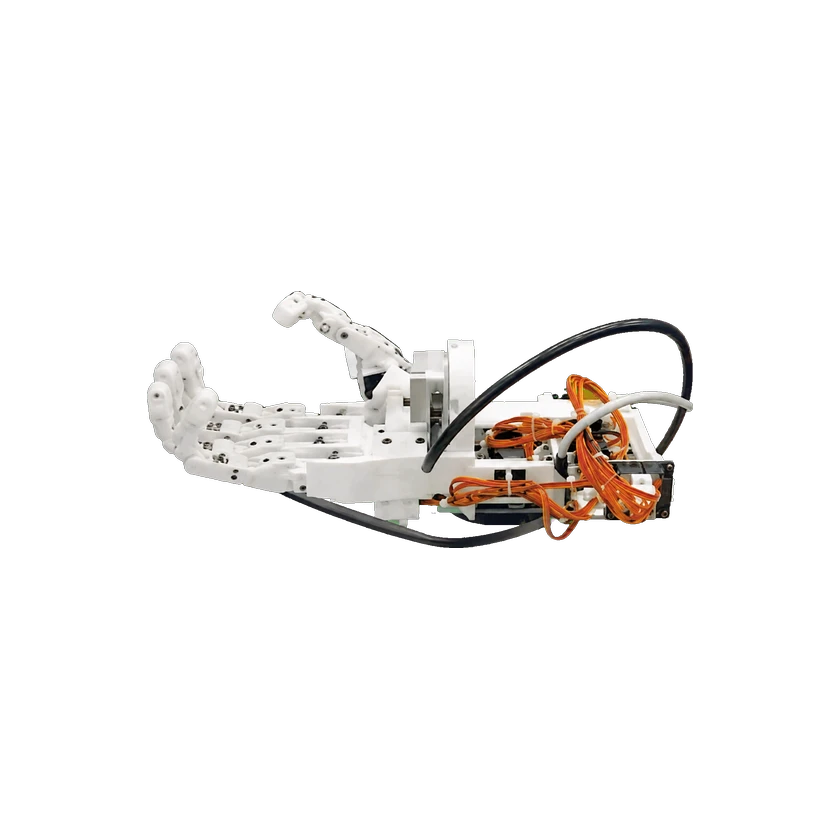
Open-source robotic-hand project created by Zhengyang Kris Weng. Its BiDexHand V4 repository releases the design files, bill of materials, ROS 2 control packages, CAD assets and build documentation for a cable-driven biomimetic dexterous hand. The project is presented as a research and development platform rather than a commercial manufacturer, and its documented affiliation is Northwestern University's Center for Robotics and Biosystems.