DOUBLE Research and Development Co., Ltd. logoDOUBLE Research and Development Co., Ltd.

D-HAND 5ST

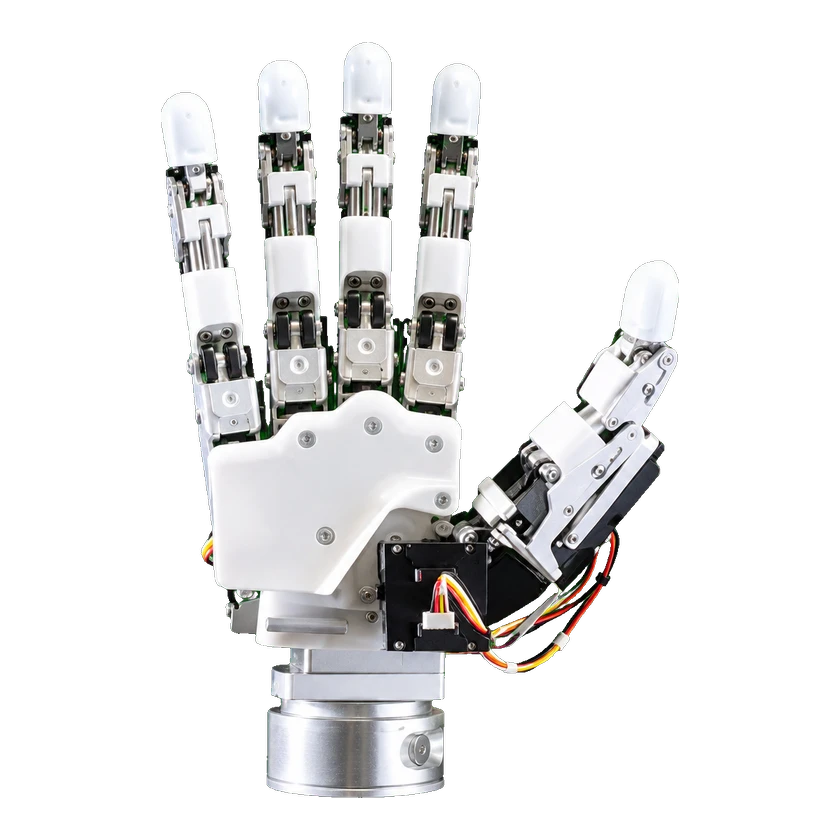
Five-finger robot hand from Double Giken.

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
Japan
Latest parameter verification
2026-10-31
6 DOF
Active degrees of freedom
0.45 kg
Hand weight
5
Finger count

D-HAND 5ST is a five-finger robot hand with independently controlled fingers. The official product page lists a six-degree-of-freedom structure including thumb abduction and adduction, a 450 g design weight, position, current, and temperature monitoring, 2.4 GHz wireless connectivity, and optional UART and CAN.

1 / 1D-HAND 5ST

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Active degrees of freedom
6 DOF

Mechanical and mounting

Hand weight
0.45 kg

Sensors

Sensors
Position, current and temperature monitoring

Interaction and Communication

Communication
2.4 GHz wireless and UART support; CAN is listed as optional.

Manufacturer-listed interface capability. The public page does not establish a delivery SKU, installed connector or pinout.

Configurations

Default

Communication and control

Communication interface
2.4 GHz wireless

Manufacturer-listed interface capability. The public page does not establish a delivery SKU, installed connector or pinout.

Communication interface
UART

Manufacturer-listed interface capability. The public page does not establish a delivery SKU, installed connector or pinout.

Software and resources

ROS compatibility
ROS 2
SDK languages
Python

D-HAND 5ST — optional CAN

Communication and control

Communication interface
CAN

Manufacturer-listed optional CAN capability; independent delivery SKU and external pinout are not specified.

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction