SCHUNK logoSCHUNK

SCHUNK SAH

SAH

Price
Unknown
Type
Components · Dexterous Hands
Status
Commercialized
Availability
Not disclosed
Release Date
Unknown
Country/Region
Germany
Latest parameter verification
2026-11-01
13 DOF
Active degrees of freedom
17
Mechanical joint count
≈2.2 kg
Hand weight
4
Finger count

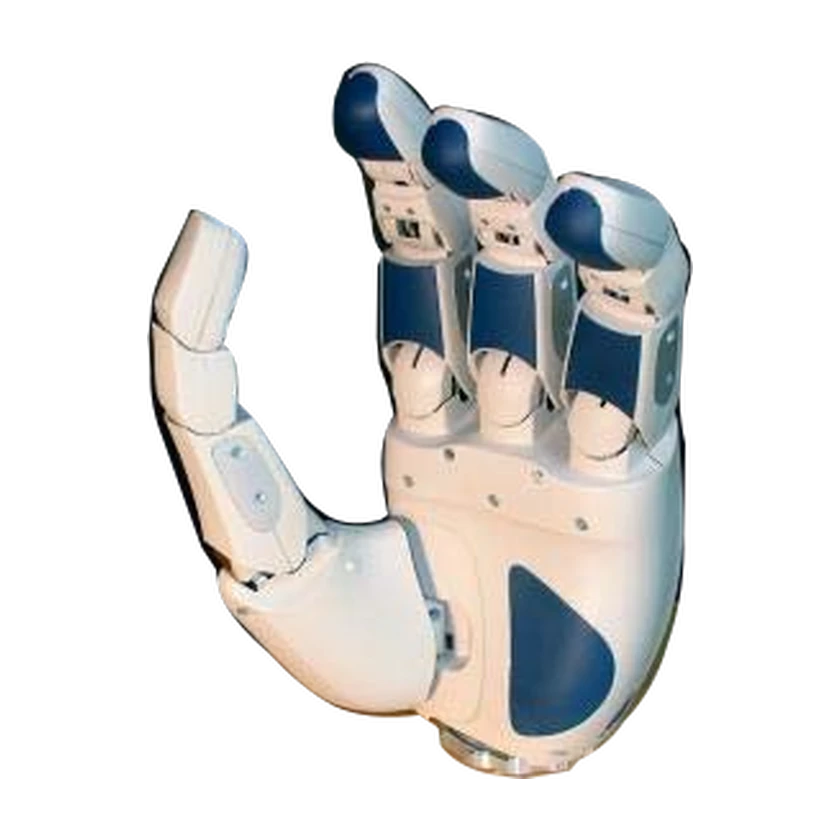
SAH is a four-fingered anthropomorphic hand jointly developed by DLR and Harbin Institute of Technology and offered by SCHUNK. It has 17 joints and 13 actuated degrees of freedom, including an extra thumb drive for opposition. Developer documentation specifies contactless magnetic angle sensing and strain-gauge torque sensing at each joint. Internal drives and electronics work with an external controller for joint feedback in fine-manipulation and power-grasping research.

1 / 1SAH

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
4
Actuator count
13
Actuator technology
Brushless DC motors
Coupled degrees of freedom
4 DOF
Active degrees of freedom
13 DOF
Mechanical joint count
17

Motion and coordination

Coordination architecture
Host DSP controls the hand through an FPGA real-time serial bus
Energy domain
Electric

Mechanical and mounting

Hand weight
≈2.2 kg

The DLR/HIT developer handout says about2.2kg, not an exact mass. The SCHUNK brochure identifies the commercial SAH but does not give a separate mass or delivered revision. Retain the approximate developer value as reported, not a newly confirmed production-unit weight. The SAH research experiment independently documents13 controllable DoF; that does not resolve mass revision.

Electrical and integration

Internal Wiring
Protected cable routing
Joint Encoder
Contactless magnetic joint angle sensors
Joint Sensor Type
Strain-gauge joint torque sensors
Operating voltage
24 V
Static current
0.75 A

Compute Platform

CPU
External host DSP on PCI board
Operating System
Windows-based host programming software

Development and Expansion

Integration Interface
PCI control board for two hands

Configurations

Left hand

Left hand

Communication and control

Communication interface
Serial interface
Communication protocol
FPGA real-time serial bus, 25 Mbps

Sensing

Proprioceptive feedback
Joint position and torque feedback
Right hand

Right hand

Communication and control

Communication interface
Serial interface
Communication protocol
FPGA real-time serial bus, 25 Mbps

Sensing

Proprioceptive feedback
Joint position and torque feedback

Commercial Status

Status
Commercialized
Price
Unknown
Release Date
Unknown
Submit a source or correction