ROBEL

D’Manus

D'Manus

Price
Unknown
Type
Components · Dexterous Hands
Status
Open-source research platform
Availability
Not disclosed
Release Date
Unknown
Country/Region
Unknown
Latest parameter verification
2026-09-15
10 DOF
Active degrees of freedom
3
Finger count

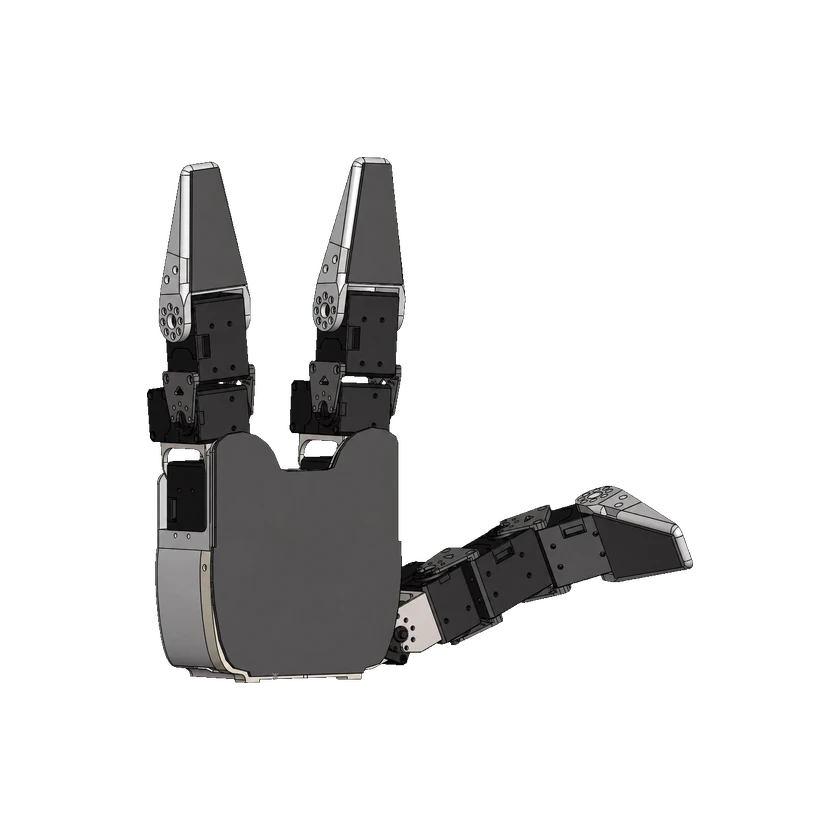
D'Manus is a three-fingered hand developed by Carnegie Mellon University and FAIR–Meta AI researchers, with joint-level Dynamixel actuation and 10 degrees of freedom. ReSkin magnetic tactile sensing covers the palm and all three fingertips. The paper reports that an arm-mounted setup with learned models identified softness and texture and performed tactile bin sorting; these results apply to the reported experimental setup.

1 / 1D'Manus

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
3
Actuator count
10
Actuator technology
Electric servo
Active degrees of freedom
10 DOF
Materials
3D-printed PLA/ABS parts, machined aluminum brackets and knuckles
Actuator Model
Dynamixel XM430-W210-R

Motion and coordination

Energy domain
Electrical

Mechanical and mounting

Mounting interface
Custom 3D-printed robot-arm or wrist adapter

Mechanical Structure

Operating voltage
12 V

Development and Expansion

Secondary Development (SDK)
Python driver with Gym interface

Configurations

ReSkin 10-DoF

Communication and control

Communication interface
USB serial bus
Communication interface
RS-485 motor bus
Communication protocol
Dynamixel Protocol
Control mode
Position
Control mode
Velocity
Control mode
Extended position
Control mode
Current
Control mode
PWM
Protocol version
2.0

Software and resources

CAD availability
Open-source CAD files
SDK languages
Python
Simulation formats
MuJoCo

Sensing

Has tactile sensing
Yes
Proprioceptive feedback
Joint position
Proprioceptive feedback
Joint velocity
Proprioceptive feedback
Motor current
Proprioceptive feedback
Input voltage
Tactile configuration
ReSkin: 8 magnetometers per fingertip; 32 in the palm; 56 total

Commercial Status

Status
Open-source research platform
Price
Unknown
Release Date
Unknown
Submit a source or correction