
Dexterous hand database
Browse source-backed dexterous hand products by specifications, availability, company, and commercial status.
Showing 195 dexterous hands models
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Maximum weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
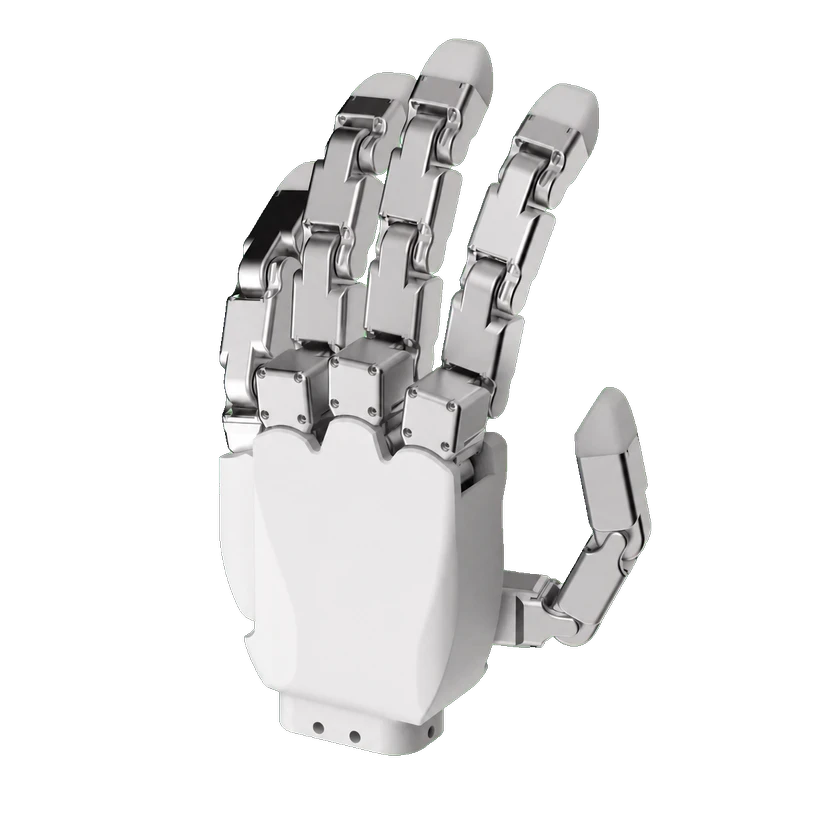 DG-5F-MDG-5F-M | Tesollo | South Korea | — | Not disclosed | 5 fingers | 20 joints | 20 DOF | 1.76 kg | Ethernet / | — | — | 2026-09-09 | |
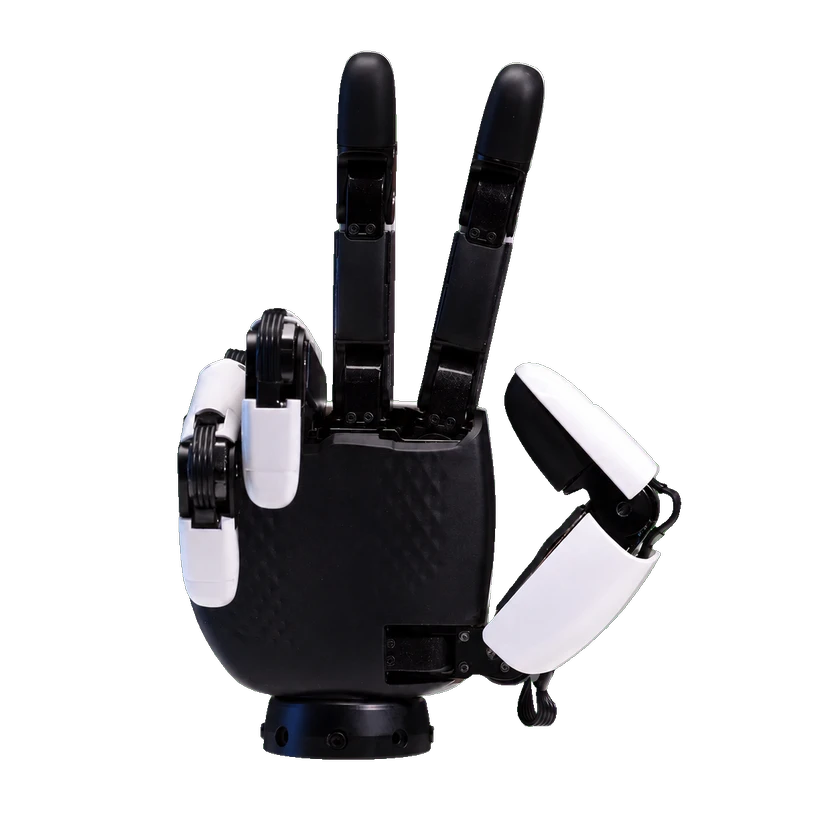 XHAND 1XHAND 1 | Robot Era | China | — | Not disclosed | 5 fingers | 12 joints | 12 DOF | 1.1 kg | — | — | — | 2026-09-13 | |
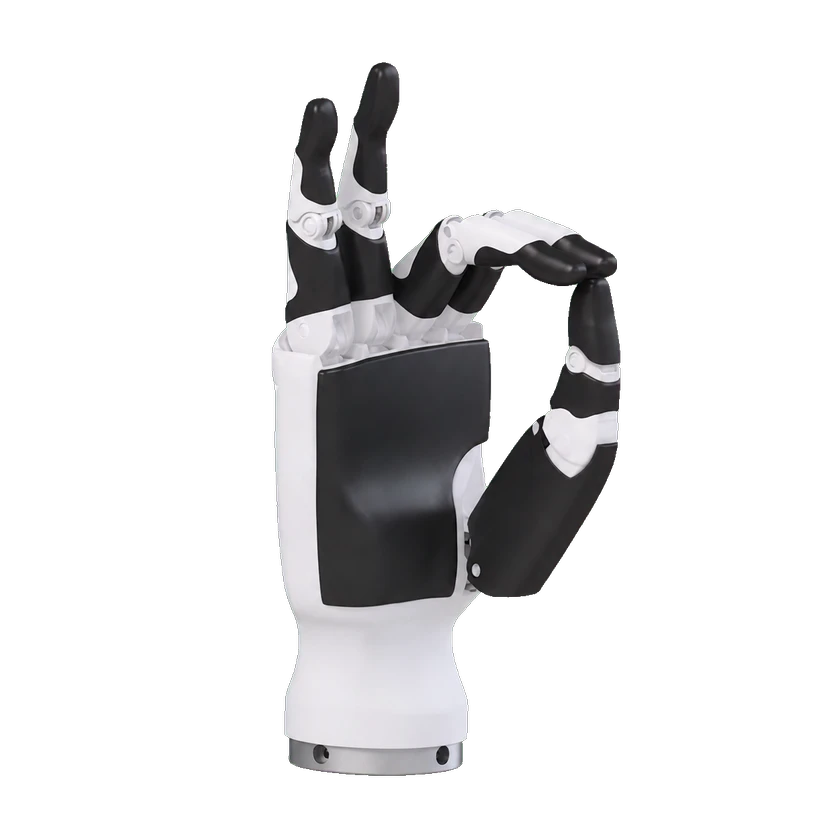 RH56DFXRH56DFX-2 | Inspire Robots | China | — | Not disclosed | 5 fingers | 12 joints | 6 DOF | 0.54 kg | RS485 | Included | — | 2026-09-08 | |
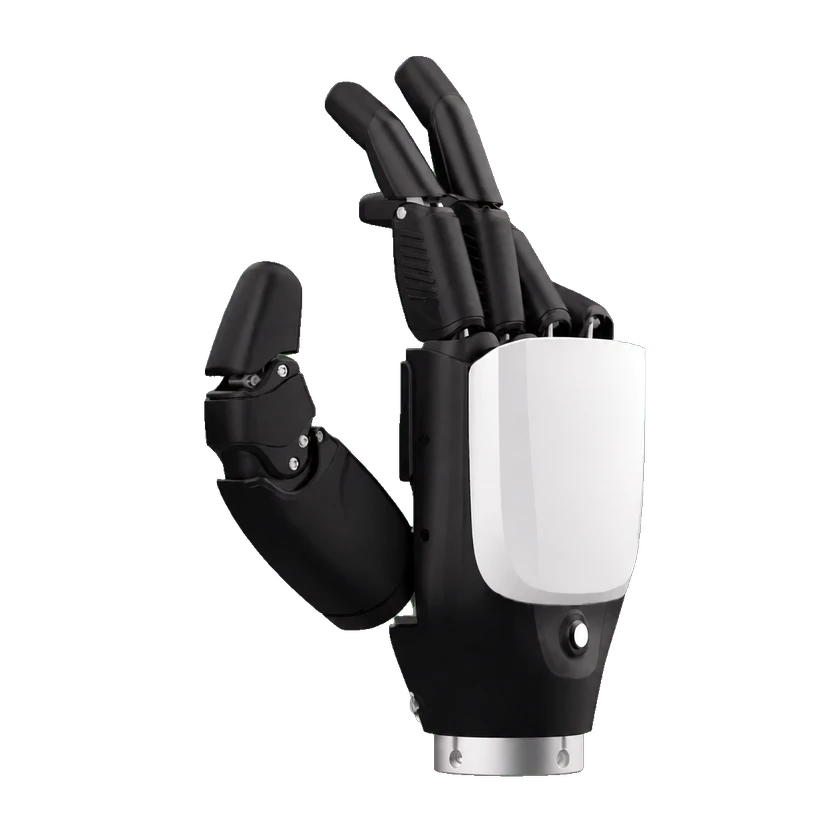 RH56DFTPRH56DFTP | Inspire Robots | China | — | Not disclosed | 5 fingers | 12 joints | 6 DOF | — | Ethernet / RS485 / CAN 2.0 | Included | — | 2026-08-28 | |
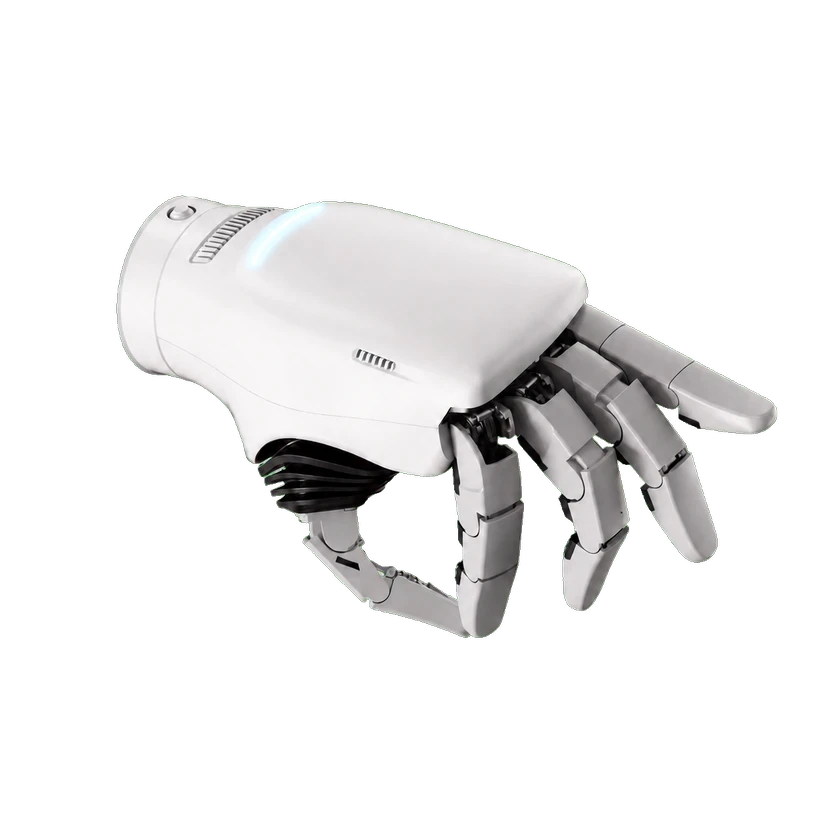 ArtiXon HandArtiXon Hand | X Square Robot | China | Commercial | Not disclosed | 5 fingers | — | 15 DOF | ≤1.00 kg | — | — | — | 2026-09-13 | |
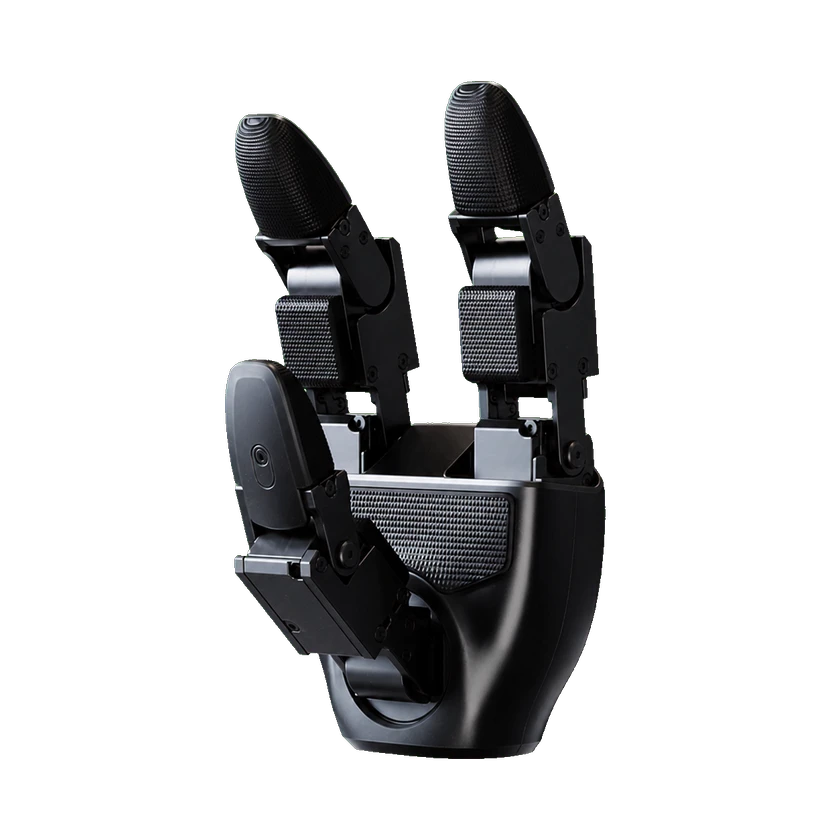 Dex3-1Dex3-1 | Unitree Robotics | China | — | Not disclosed | 3 fingers | 7 joints | 7 DOF | 0.71 kg | USB 2.0 / high-speed UniBus | — | — | 2026-08-27 | |
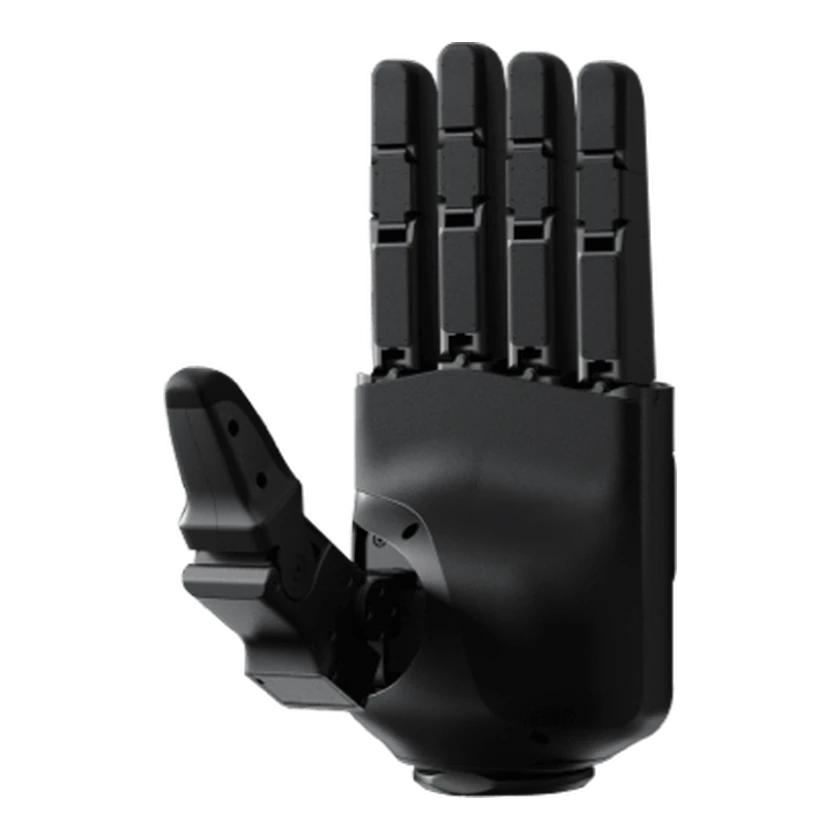 Dex5-1Dex5-1 | Unitree Robotics | China | Commercial | On sale | 5 fingers | 20 joints | 16 DOF | 1.1 kg | — | — | — | 2026-09-12 | |
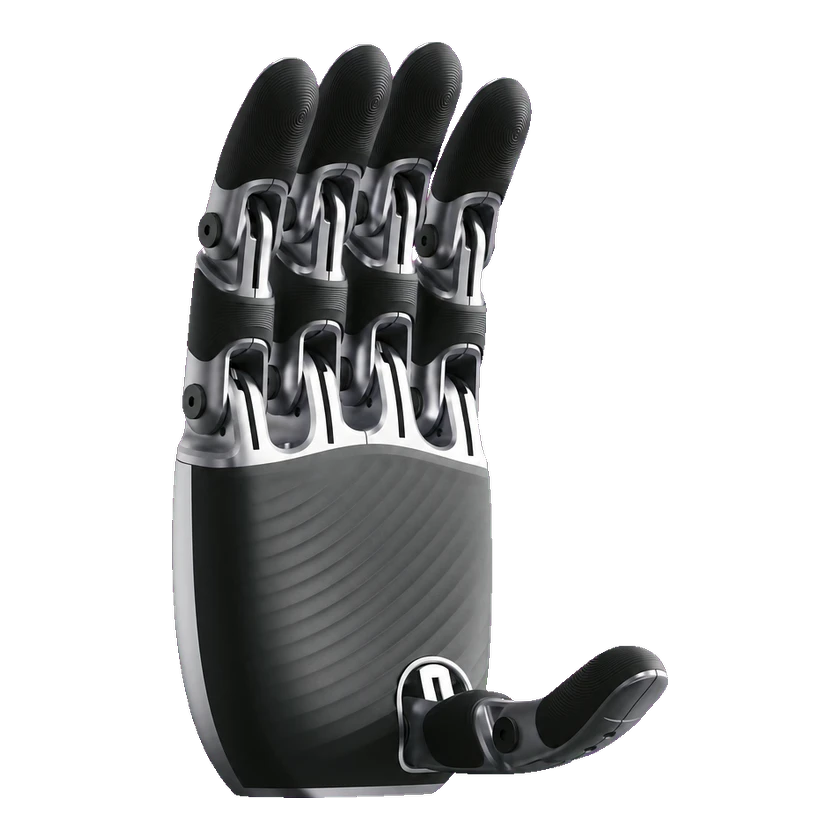 Dex2/5Dex2/5 | Unitree Robotics | China | — | On sale | 5 fingers | 10 joints | 2 DOF | 0.37 kg | — | — | — | 2026-09-12 | |
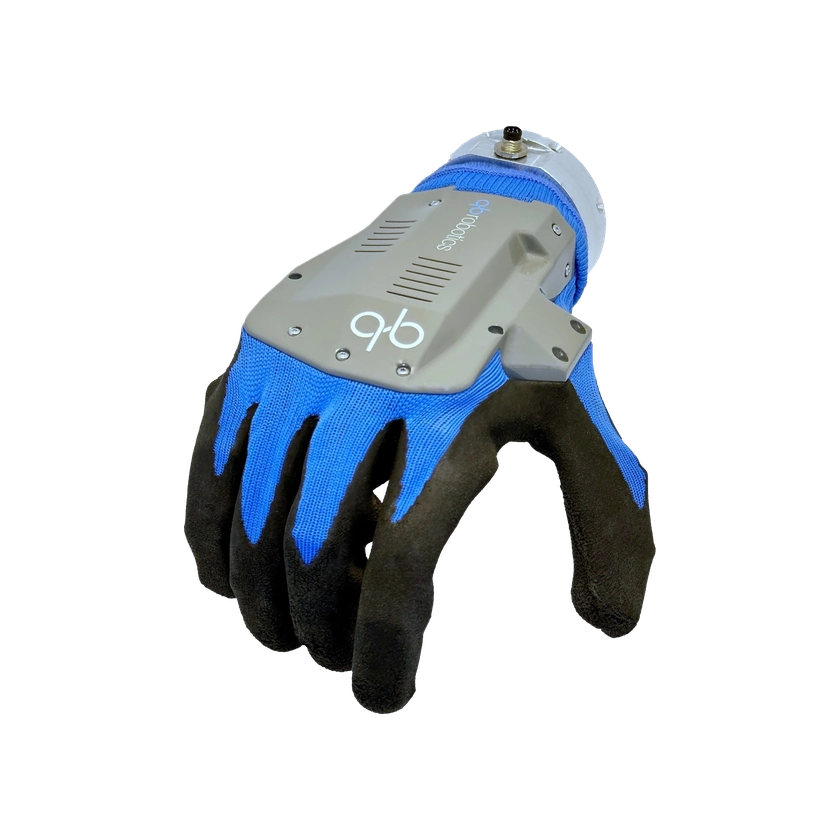 qb SoftHand Researchqb SoftHand Research | qb robotics | Italy | Commercial | On sale | 5 fingers | — | 1 DOF | 0.77 kg | — | — | From EUR 7,000 | 2026-09-12 | |
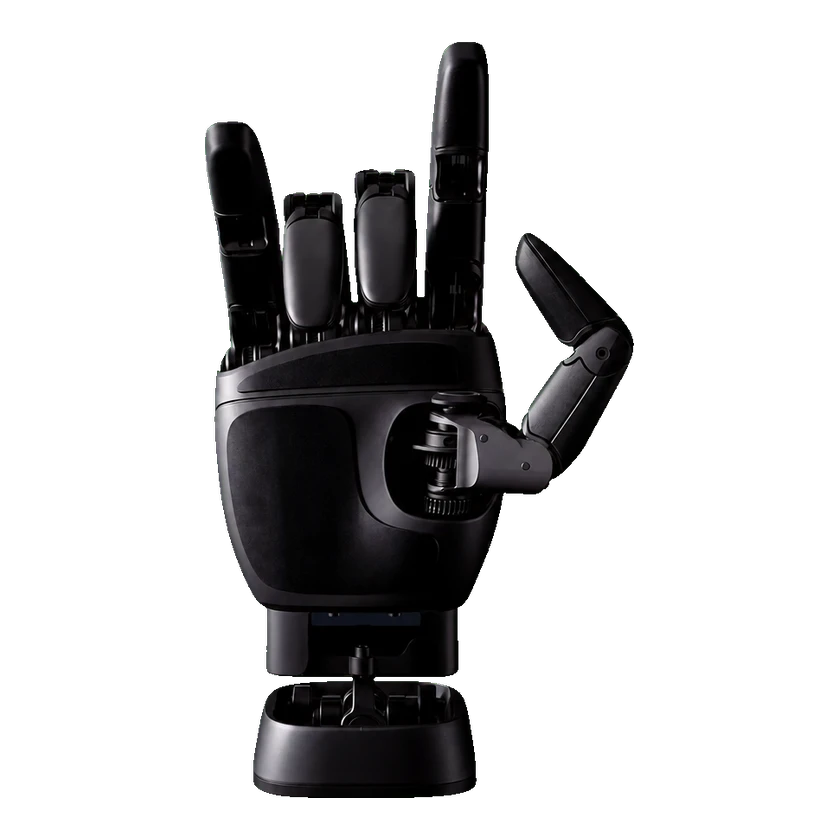 PUDU DH11PUDU DH11 | Pudu Robotics | China | — | Not disclosed | 5 fingers | — | 6 DOF | 0.5 kg | — | — | — | 2026-09-07 | |
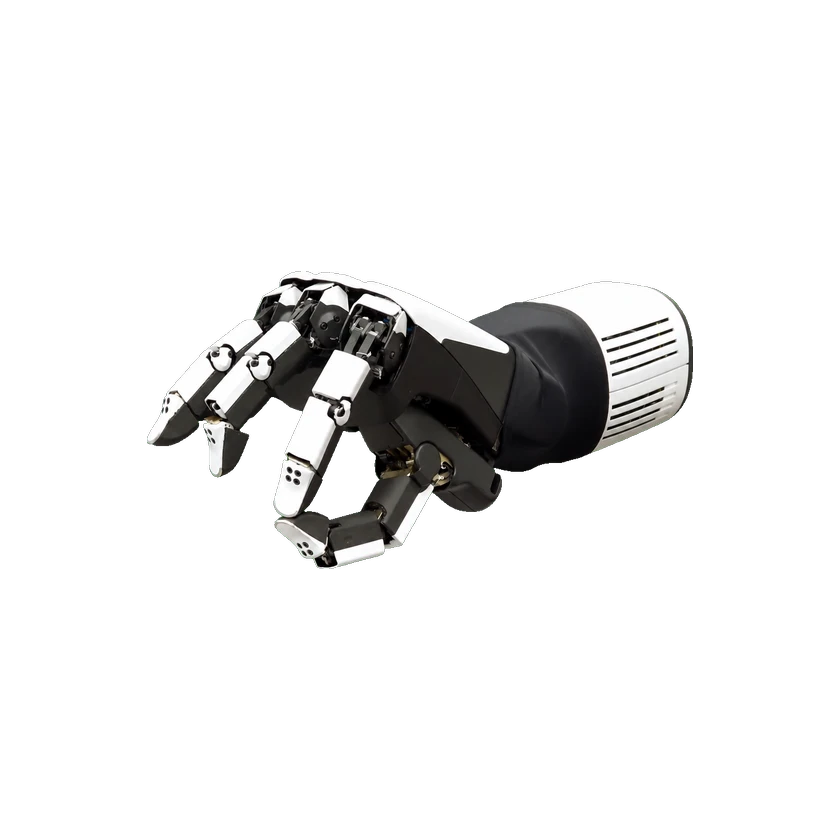 Honda Dexterous Multi-fingered HandHonda Dexterous Multi-fingered Hand | Honda R&D | Japan | Prototype | Not released | 4 fingers | 16 joints | 16 DOF | — | — | — | Not publicly priced | 2026-09-14 | |
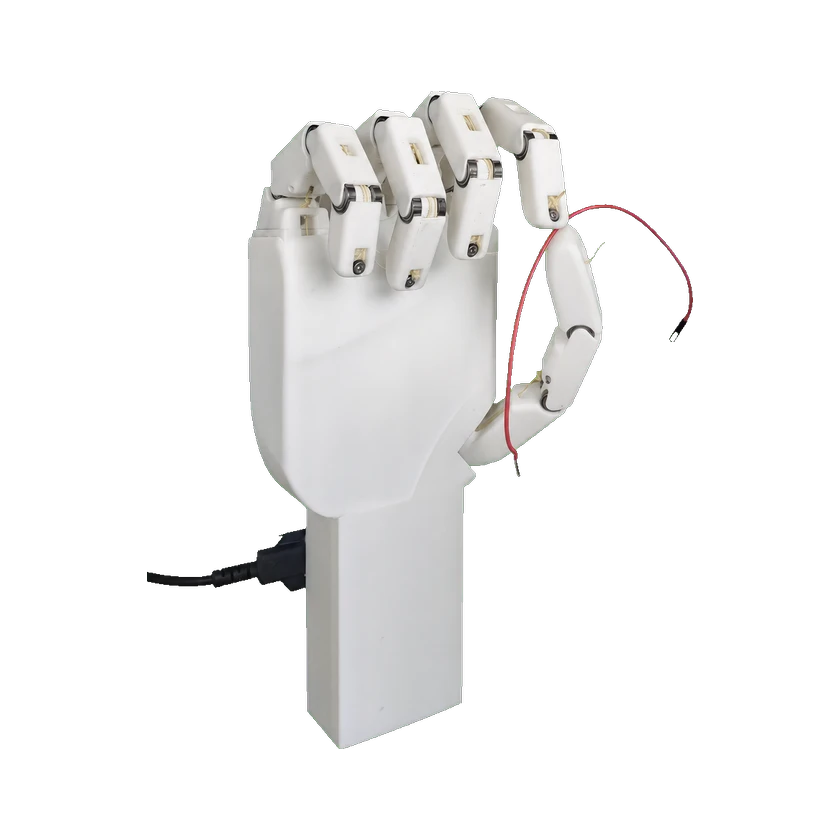 PHANTOM HandPHANTOM Hand | The Hong Kong University of Science and Technology (Guangzhou) | China | Prototype | Not released | 5 fingers | 15 joints | 6 DOF | — | — | — | Price unknown | 2026-09-14 |
Submit a source or correction