
 Unitree Robotics
Dex3-1
Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-08-27
7 count
Active degrees of freedom
7 count
Mechanical joint count
0.71 kg
Weight
3 count
Finger count
Verified dexterous-hand sample.
1 / 1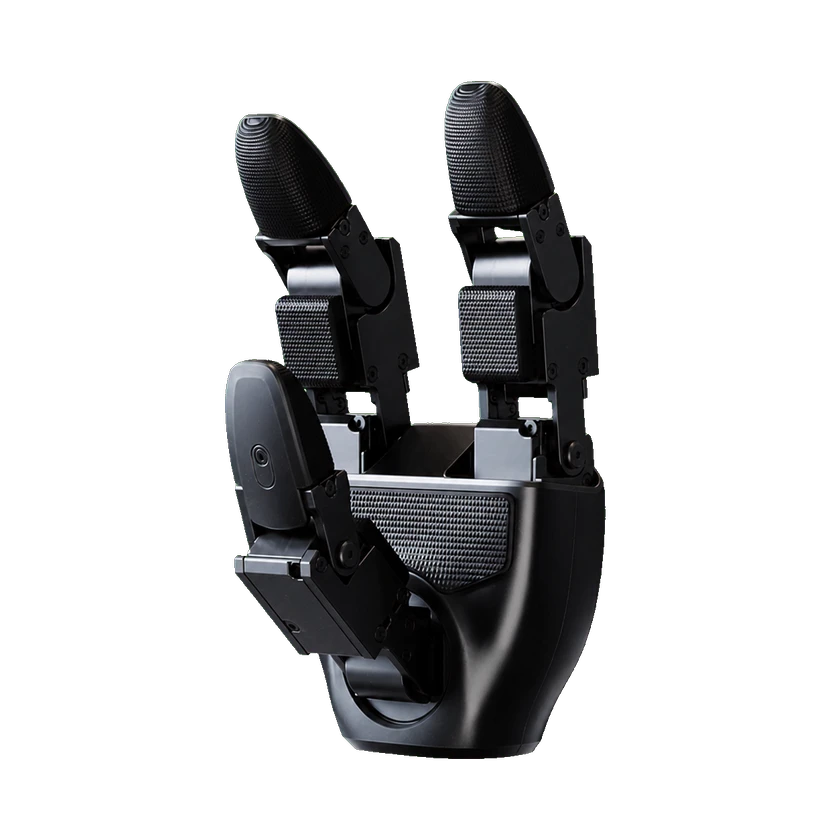
Hardware Specification
Degrees of freedom and drive
Actuator count
7 count
Actuator technology
micro brushless force control joint
Active degrees of freedom
7 count
Active degrees of freedom
7 DOF
Mechanical joint count
7 count
Dimensions (Standing)
175 mm x 88 mm x 77 mm
Total degrees of freedom
7 DOF
Total degrees of freedom
7 DOF
Transmission mechanism
6 Motors Drive Directly 1 Motor Drive with Gears
Mobility & Payload
Absolute Position Accuracy
±2 mm fingertip repeat positioning accuracy
General Payload
0.500
Mechanical and mounting
Depth
77 mm
Dimension measurement pose
flat state
Length
175 mm
Weight
0.71 kg
Weight
0.710
Width
88 mm
Electrical and integration
Actuator Model
F-1515-108; F-1515-214
Dexterous Hand
Yes
Dexterous Hand Model
Dex3-1
Gear Ratio
1:108; 1:214
Joint Encoder
Rotor absolute value encoder
Maximum current
10A
Motor Mass
45 g
Motor Peak Torque
0.76 Nm; 1.498 Nm ideal; 0.49 Nm, 0.86 Nm, 1.37 Nm and 3.1 Nm actual
Operating voltage
12–58 V
Peak power
400W@3s
Static current
58V @ 0.2A
Communication and control
Communication interface
USB 2.0 / high-speed UniBus
Control mode
force and position hybrid control
Feedback rate
1000 Hz
Feedback signals
Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, Sensor Pressure Value, Sensor Temperature Value, imu Data
Sensors
33 pressure sensors
Tactile Sensor
33 tactile/pressure sensors
Battery and Runtime
Max Power
400 W @ 3 s
Power Supply
12-58 V
Performance and tasks
Power grasp payload
0.5 kg
Repeatability
±2mm
Software Algorithm
Force-position hybrid control
Reliability and environment
Operating temperature
-20℃ ~ 60℃
Operating temperature
-20 °C to 60 °C
Sensing
Communication
1000 Hz; High Speed Unibus
External Port
USB 2.0
Tactile configuration
Number of Pressure Sensors 9 (Total of 33 Pressure Sensors) Array resolution 2 x 2 (Palm) x 3 2 x 2 (Single Finger Pad) x 3 3 x 1 (Single Fingertip) x 3
Tactile Feedback
Joint and sensor pressure feedback
Development and Expansion
Integration Interface
Unitree G1 humanoid robot
Max Weight
500 g
Commercial Status
Status
Commercial
Price
Unknown
Release Date
Unknown
Related Entities
Robots related to “Dex3-1”
Submit a source or correction