Dex2/5
Communication and control
Communication interface
RS485
 Unitree Robotics
Unitree Dex2/5 is a compact five-finger tendon-driven dexterous hand designed for humanoid manipulation and embodied-AI research. It weighs 365 g and provides 10 degrees of freedom, including two actuated degrees of freedom, with gear-tendon rope transmission and hidden internal wiring. RS485 communication, joint-state feedback, 24–60 V operation, a 0.5-second minimum fist-clench time, and compatibility with Unitree G1 and R1 support integration, grasping, and repeatable laboratory evaluation. Its listed communication rate and fatigue-cycle testing further suit long-term operation.
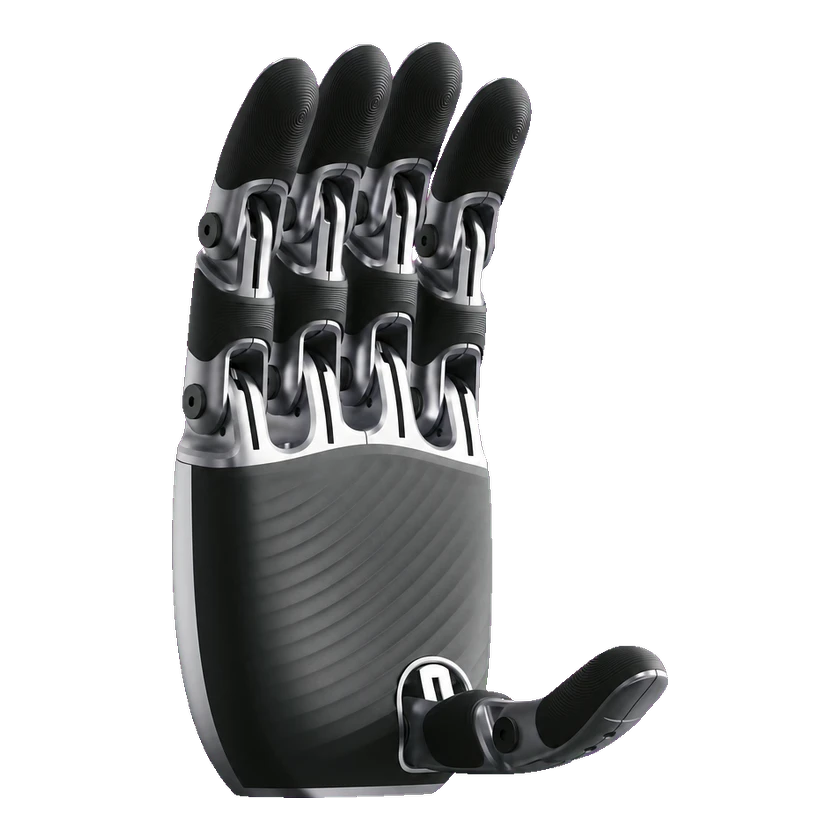
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
At 58 V, as specified by Unitree.
At 58 V, as specified by Unitree.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
There is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Simulation | Dex2/5 ROS robot-description and simulation assets GitHub · unitreerobotics/unitree_ros Official ROS repository lists this robot model. These robot-description assets support visualization and simulation; they do not establish published manufacturing drawings or complete onboard software. Match the model configuration before use. | BSD-3-Clause | Dex2/5 | Open GitHub |