
 Inspire Robots
RH56DFTP
Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-08-28
6 DOF
Active degrees of freedom
12
Mechanical joint count
29.4 N
Fingertip force
5 count
Finger count
A five-finger dexterous hand with force and tactile sensing.
1 / 1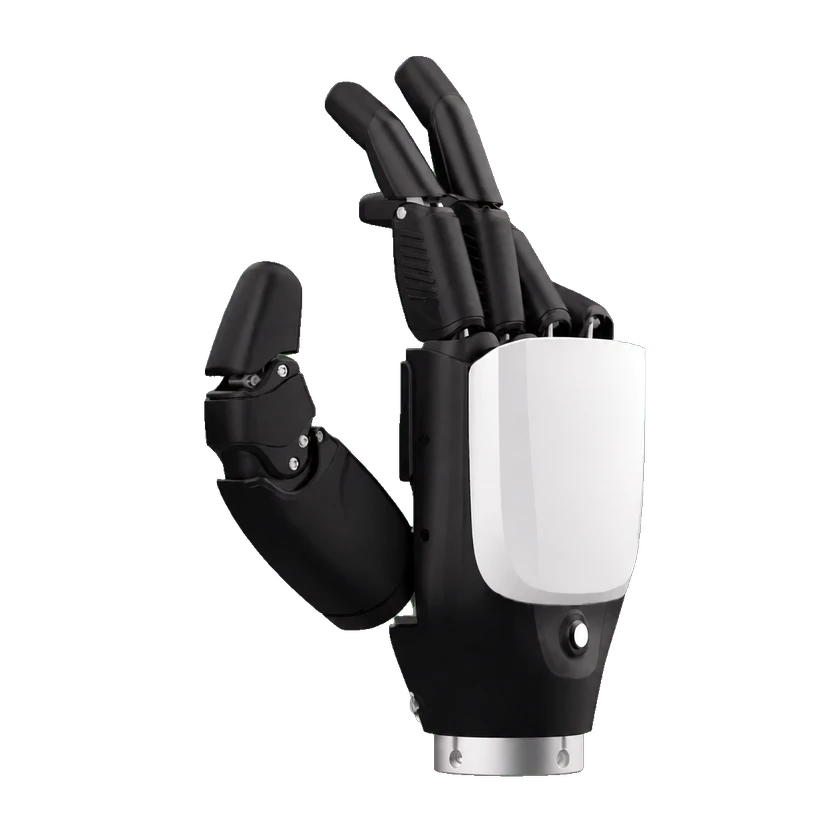
Hardware Specification
Degrees of freedom and drive
Actuator count
6
Active degrees of freedom
6 DOF
Mechanical joint count
12
Electrical and integration
Connector type
1BZ1G08CLL00000 aviation plug (Lemo FGG-1B-8P compatible)
Maximum current
4.5 A at 24 V (maximum gripping force)
Operating voltage
24 V
Rated current
1.2 A at 24 V (no-load average)
Static current
0.2 A at 24 V
Communication and control
Calibration method
Force-sensor calibration with hand open
Communication interface
Ethernet, RS485, CAN 2.0
Communication protocol
Modbus TCP; CAN 2.0 or RS485
Feedback signals
Actual angle, force, actuator position/current/temperature, tactile data
Performance and tasks
Fingertip force
29.4 N
Power grasp force
30 N (five-finger gripping force)
Repeatability
±0.2 mm
Sensing
Has tactile sensing
Yes
Tactile configuration
5–17 tactile sensors across fingertips, finger pads, and palm; 6 pressure sensors
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Robots related to “RH56DFTP”
Submit a source or correction