
 Inspire Robots
RH56DFX
Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-08
6 DOF
Active degrees of freedom
12
Mechanical joint count
15 N
Fingertip force
0.54 kg
Weight
Verified dexterous-hand sample.
1 / 1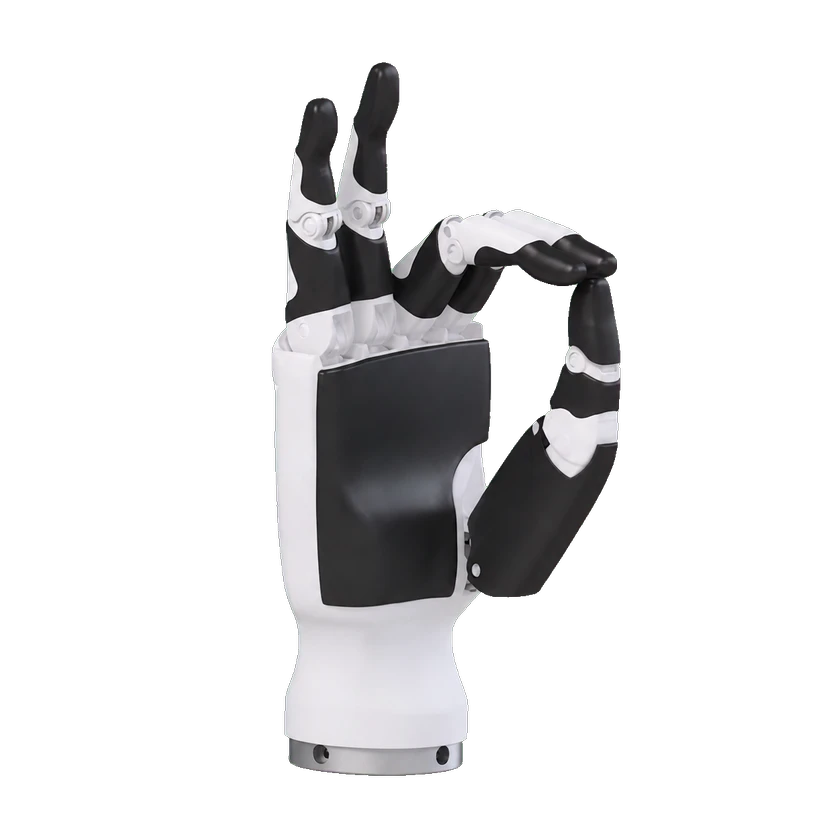
Hardware Specification
Degrees of freedom and drive
Actuator count
6
Active degrees of freedom
6 DOF
Mechanical joint count
12
Total degrees of freedom
6 6+2
Mechanical and mounting
Depth
49.3 mm
Length
217.8 mm
Mounting interface
Ø12.0, Ø38.0, Ø52.0, 4×Ø6.0, 4×Ø3.5
Weight
0.54 kg
Width
80.7 mm
Electrical and integration
Maximum current
2A
Operating voltage
DC 24 V ±10%
Static current
0.09A 0.1A
Communication and control
Communication interface
RS485
Communication protocol
RS485 serial: 115200 bps, 8 data bits, 1 stop bit, no parity
Feedback signals
Pressure-sensor real-time gripping force
Performance and tasks
Fingertip force
15 N
Repeatability
±0.20mm
Sensing
Has tactile sensing
Yes
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Robots related to “RH56DFX-2”
Submit a source or correction