
 Robot Era
XHAND 1
Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-13
12 DOF
Active degrees of freedom
12
Mechanical joint count
1.1 kg
Weight
5
Finger count
XHAND 1 is RobotEra’s fully actuated five-finger dexterous hand for AI research. It has 12 active degrees of freedom, optional high-resolution tactile sensing, Linux SDK and ROS-compatible applications, plus Vision Pro teleoperation.
1 / 1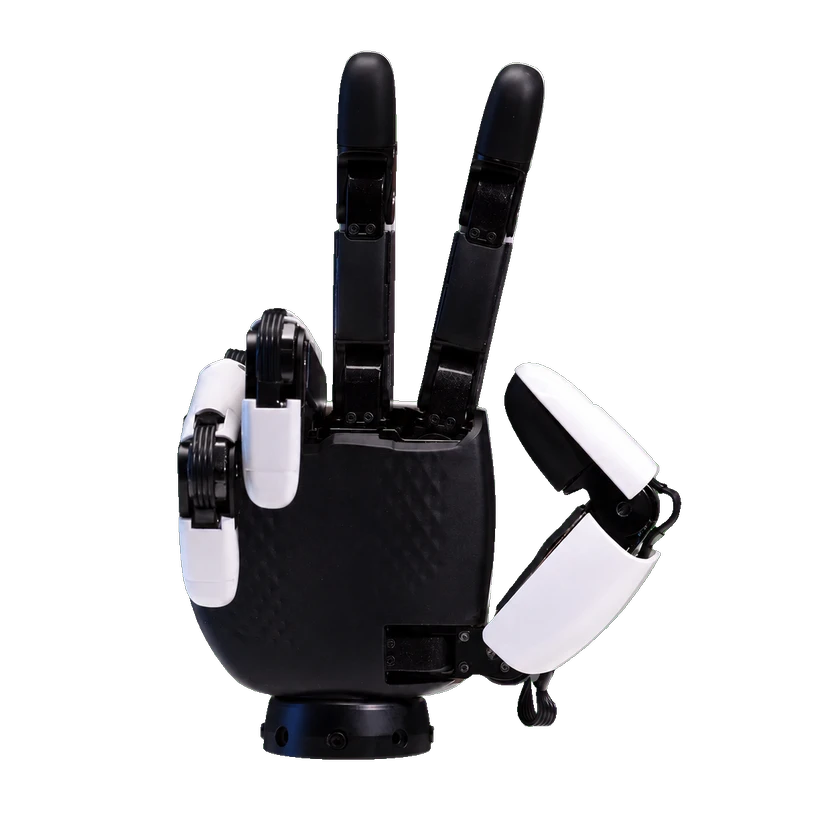
Hardware Specification
Degrees of freedom and drive
Actuator count
12
Actuator technology
Gear- and motor-driven
Active degrees of freedom
12 DOF
Mechanical joint count
12
Mobility & Payload
General Payload
25 kg
Mechanical and mounting
Depth
4.7 cm
Length
19.036 cm
Minimum grip diameter
1.6 cm
Weight
1.1 kg
Width
9.4 cm
Sensors
Tactile Sensor
Optional high-resolution tactile sensor (>100 points) on each finger
Compute Platform
Operating System
Linux
Software Algorithm
Reinforcement learning and imitation learning
Interaction and Communication
Tactile Feedback
3D force, tactile and temperature information
Development and Expansion
Secondary Development (SDK)
Standard Linux SDK and ROS-compatible applications
Teleoperation
Vision Pro remote teleoperation with gloves and visual mapping
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Submit a source or correction