
Components
Search component names, models or companies
Showing 213 components product families
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Hand weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
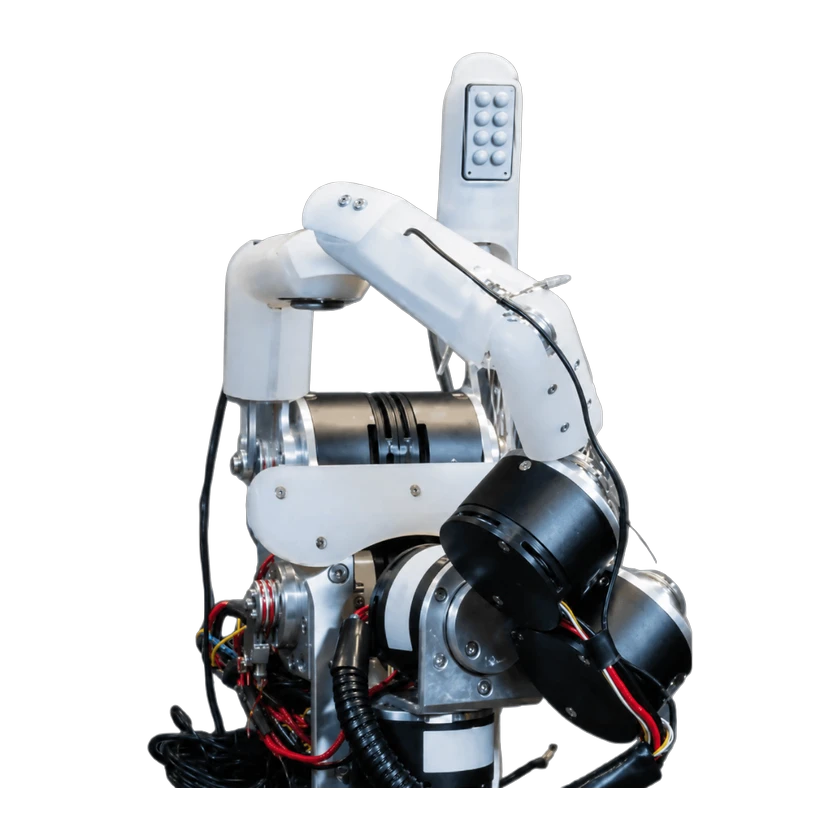 ARISTO HandARISTO Hand | The University of Texas at Austin | United States | Prototype | Not released | 3 fingers | — | — | — | — | — | Not disclosed | — | |
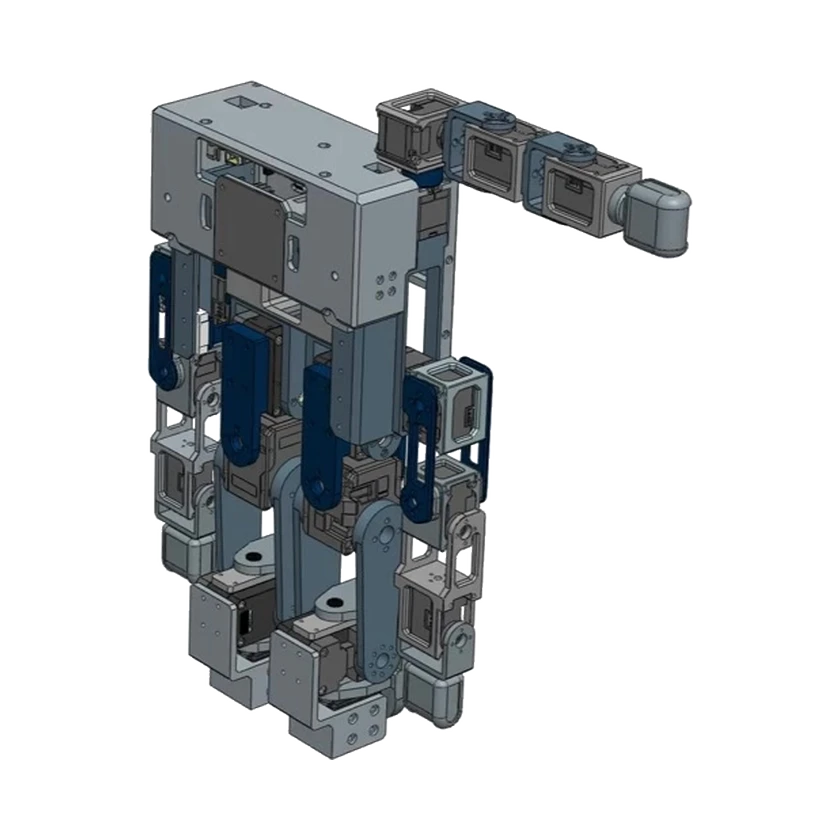 HandroidHandroid | University of North Carolina at Chapel Hill | United States | Prototype | Not disclosed | 5 fingers | — | 20 DOF | 2.05 kg | — | — | Not disclosed | — | |
 CRAFT HandCRAFT Hand | University of Illinois Urbana-Champaign | United States | Prototype | Not disclosed | 5 fingers | — | 15 DOF | 0.8 kg | — | — | Not disclosed | — | |
| Karlsruhe Dextrous Hand IIKarlsruhe Dextrous Hand II | Karlsruhe Institute of Technology | Germany | Prototype | Not released | 4 fingers | 12 joints | 12 DOF | — | — | — | — | — | |
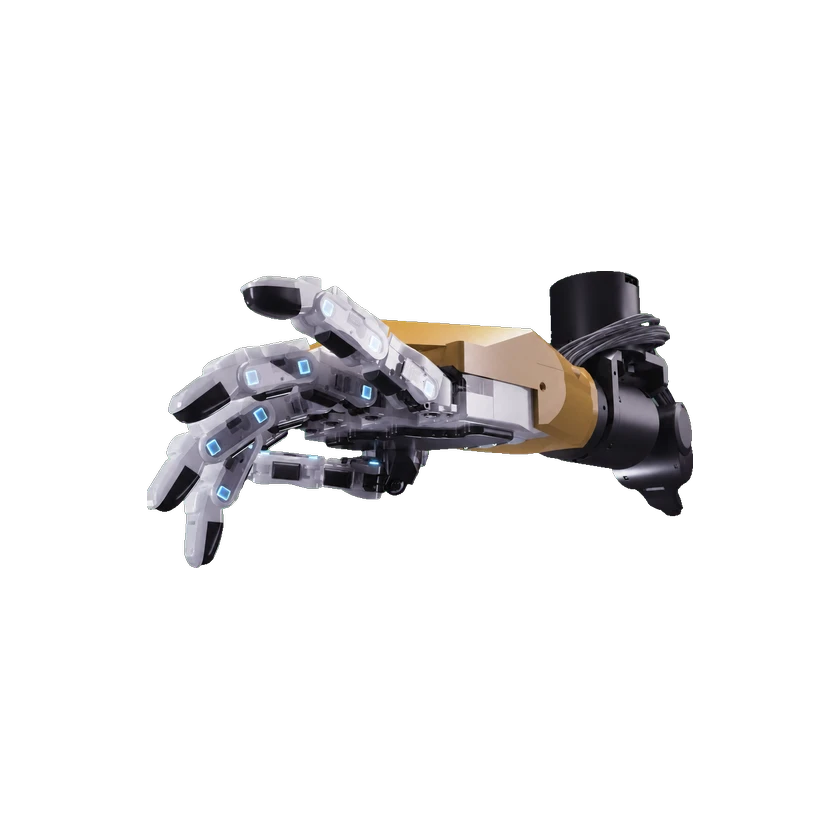 MM-HandMM-Hand 1.0 | The University of Hong Kong | Hong Kong SAR China | — | Not disclosed | 5 fingers | — | 21 DOF | 0.35 kg | — | — | Not disclosed | — | |
| SoftHand Model-WSoftHand Model-W | University of Bristol | United Kingdom | — | Not disclosed | 5 fingers | — | 4 DOF | — | — | — | Not disclosed. | — | |
| DIST-HandDIST-Hand | University of Genoa | Italy | Prototype | Not released | 4 fingers | — | 16 DOF | — | — | — | Not disclosed | — | |
| TUAT/Karlsruhe Humanoid HandTUAT/Karlsruhe Humanoid Hand Version 2 (2013) | Karlsruhe Institute of Technology | Germany | Prototype | Not released | 5 fingers | — | 7 DOF | 0.49 kg | — | — | — | — | |
| UB HandUB Hand III | University of Bologna | Italy | Prototype | Not released | 5 fingers | — | 20 DOF | — | — | — | Not disclosed | — | |
| Belgrade/USC HandBelgrade/USC Hand Model II | University of Southern California | United States | Prototype | Not disclosed | 5 fingers | 14 joints | 4 DOF | — | — | — | Not disclosed | — | |
| MIDAS HandMIDAS Hand | RoMeLa | United States | — | Not disclosed | 4 fingers | — | 13 DOF | 0.7 kg | — | — | — | — | |
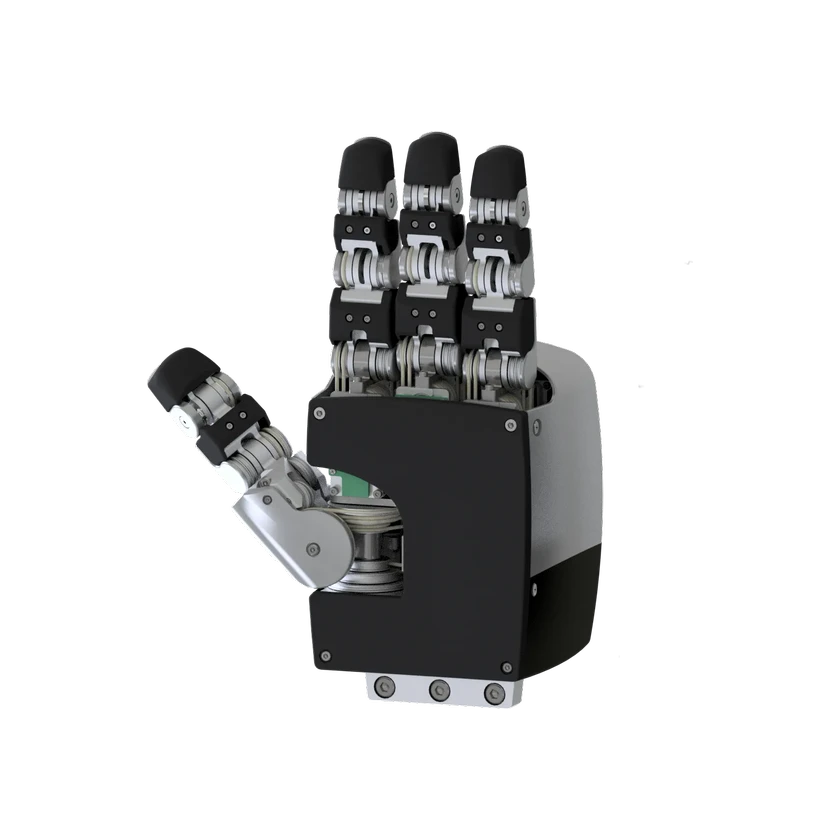 Torobo HandTorobo Hand | Tokyo Robotics | Japan | Commercial | On sale | 4 fingers | 16 joints | 12 DOF | 2 kg | — | — | Price on request | — |
Submit a source or correction