
Components
Search component names, models or companies
Showing 213 components product families
| Component | Organization | Country | Product status | Availability | Finger count | Joint count | Active DOF | Hand weight | Communication interface | Tactile sensing | Actions | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
 Yale Stewart HandStewart Hand | Yale University | United States | Prototype | Not disclosed | 3 fingers | — | 6 DOF | 1.13 kg | — | — | Not disclosed | — | |
| Yuequan Y-HandYingShou Y-Hand M1 | Yuequan Bionics | China | — | Not disclosed | 5 fingers | — | Not established | 0.3 kg | — | — | Not disclosed | — | |
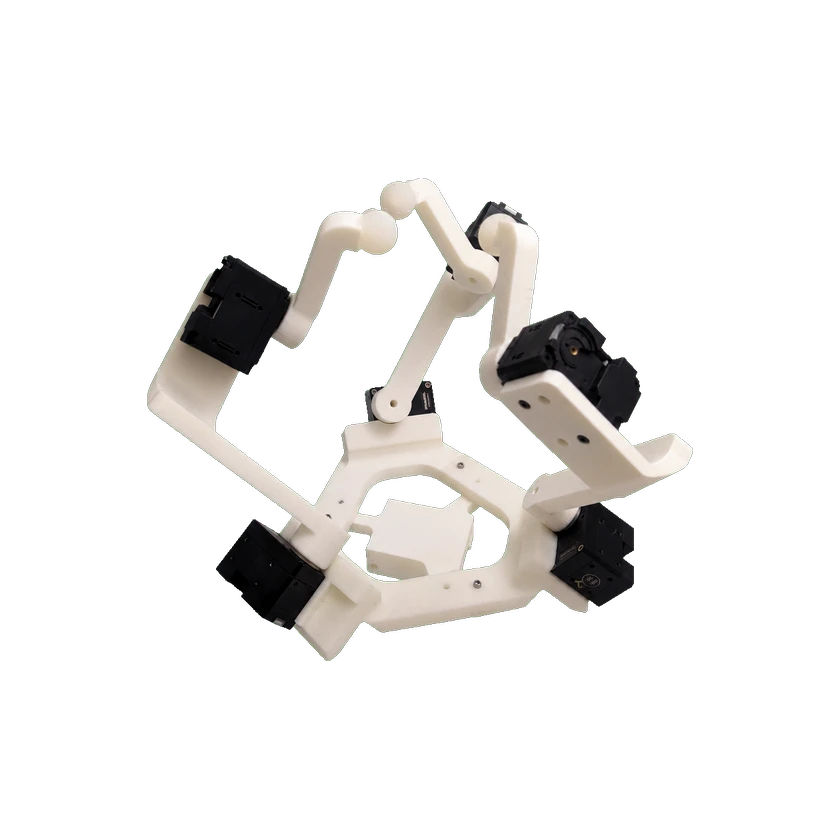 Yale OpenHand Sphinx HandSphinx Hand | Yale University | United States | — | Not disclosed | 3 fingers | — | — | 0.65 kg | — | — | Not disclosed | — | |
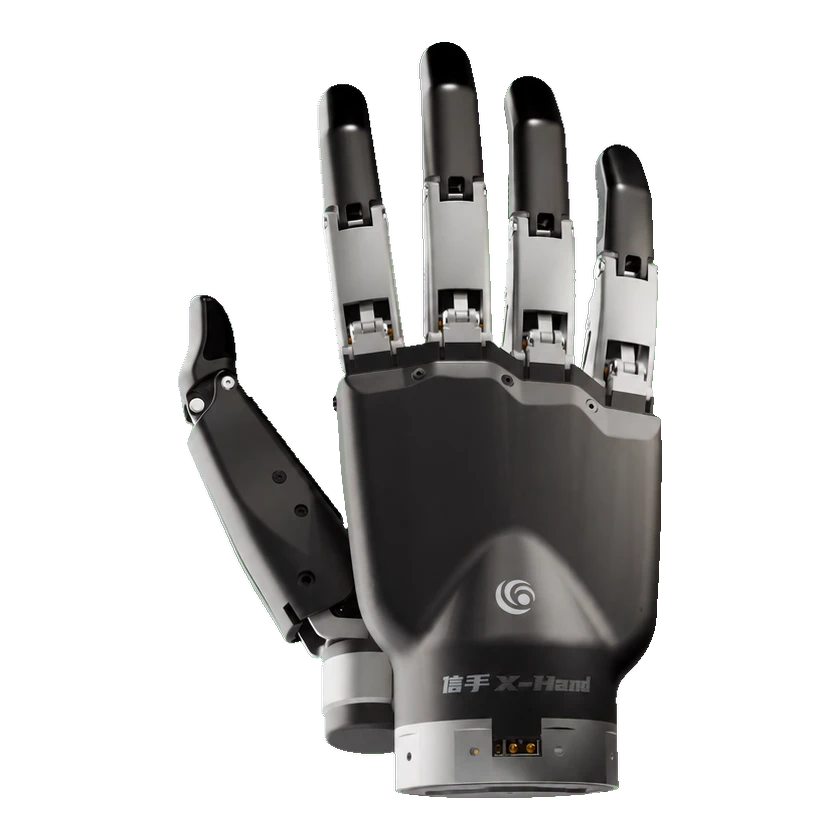 Yuequan X-HandX-Hand M1 | Yuequan Bionics | China | — | Not disclosed | 5 fingers | 11 joints | 11 DOF | 0.63 kg | — | — | — | — | |
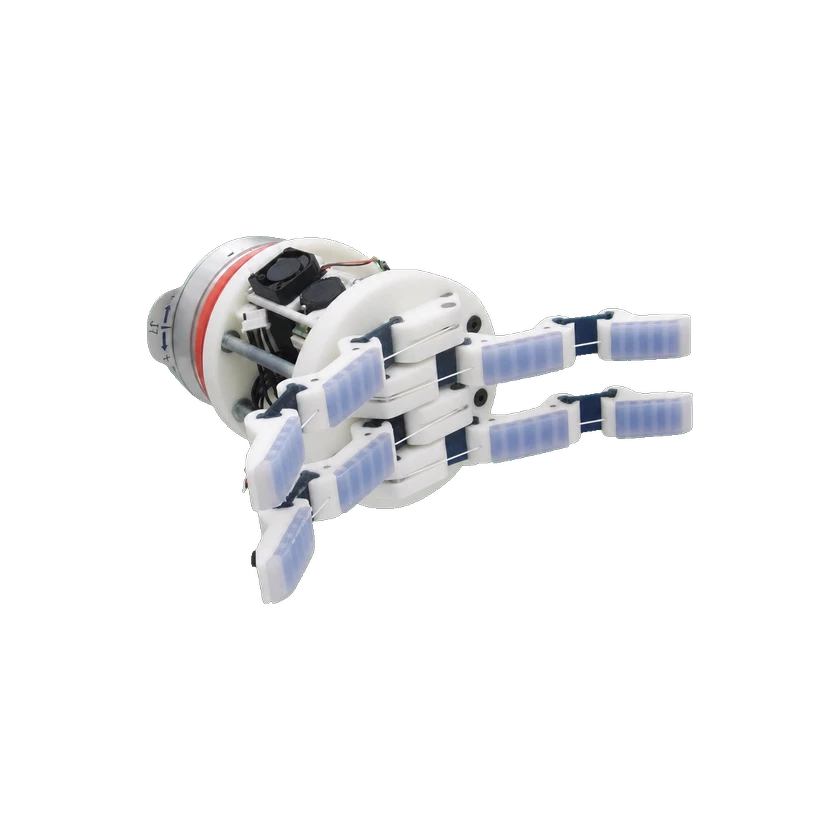 Yale OpenHand Model TModel T | Yale University | United States | Prototype | Not disclosed | 4 fingers | — | 1 DOF | 0.49 kg | — | — | Not disclosed | — | |
| Yale SDM HandSDM Hand | Yale University | United States | Prototype | Not disclosed | 4 fingers | 8 joints | 1 DOF | — | — | — | Not disclosed | — | |
| Model QModel Q | Yale University | United States | — | Not disclosed | 4 fingers | — | — | 0.74 kg | — | — | — | — | |
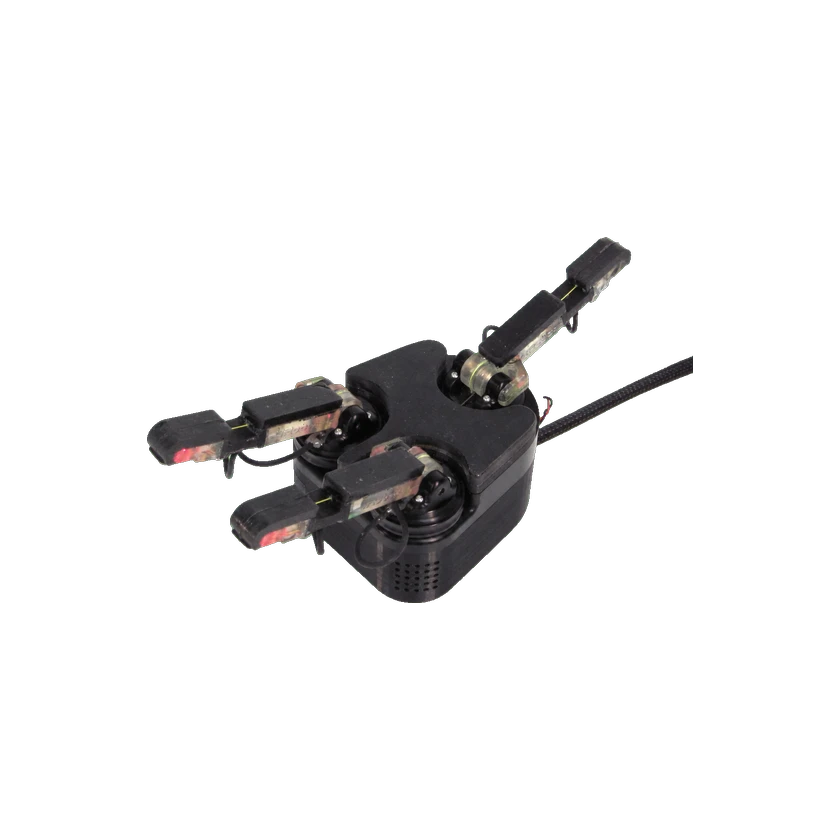 iRobot-Harvard-Yale iHY HandiRobot-Harvard-Yale iHY Hand | Yale GRAB Lab | United States | Prototype | Not released | 3 fingers | — | 5 DOF | 1.35 kg | — | — | Not disclosed | — | |
| Yale OpenHand Model OModel O | Yale University | United States | Prototype | Not disclosed | 3 fingers | — | 4 DOF | 0.75 kg | — | — | Not disclosed | — | |
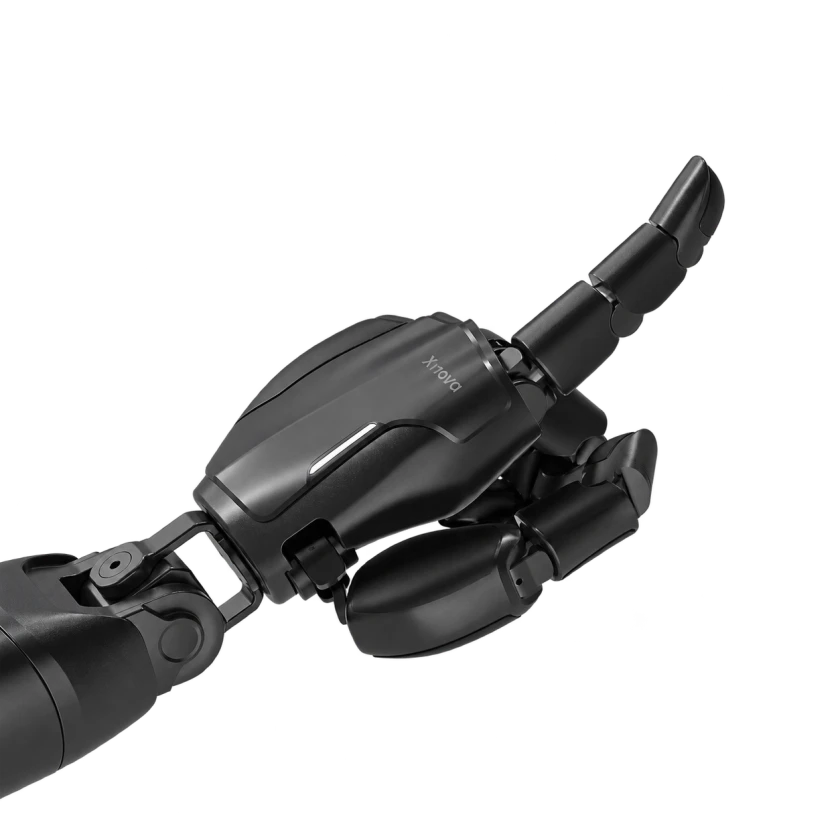 Xynova PrimaXynova Prima 1 | Xynova | China | Commercial | On sale | 5 fingers | — | 22 DOF | 0.85 kg | — | — | CNY 98,000 per set | — | |
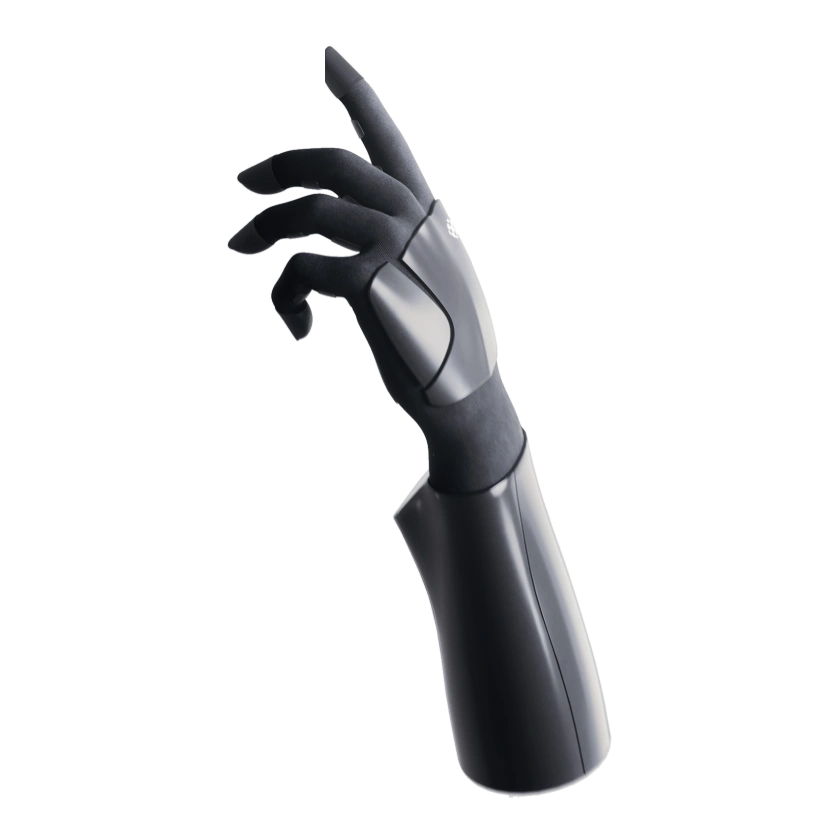 Xynova FlexXynova Flex 2 | Xynova | China | Commercial | On sale | 5 fingers | — | 19 DOF | 0.4 kg | — | — | CNY 128,000+ | 2026-09-26 | |
| MCR-Bionic HandMCR-Bionic Hand | University of Salford | United Kingdom | Prototype | Not released | 5 fingers | — | — | — | — | — | Not disclosed | — |
Submit a source or correction