
Price
Not disclosed
Type
Components · Dexterous Hands
Status
Research prototype
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Jul 17, 2026
Country/Region
United States
Last Verified
Unknown
20 DoF per hand embodiment
Active degrees of freedom
2.05 kg
Weight
5
Finger count
A 27-DoF reconfigurable research robot that uses one body as a five-finger, 20-DoF dexterous hand or a compact humanoid.
1 / 1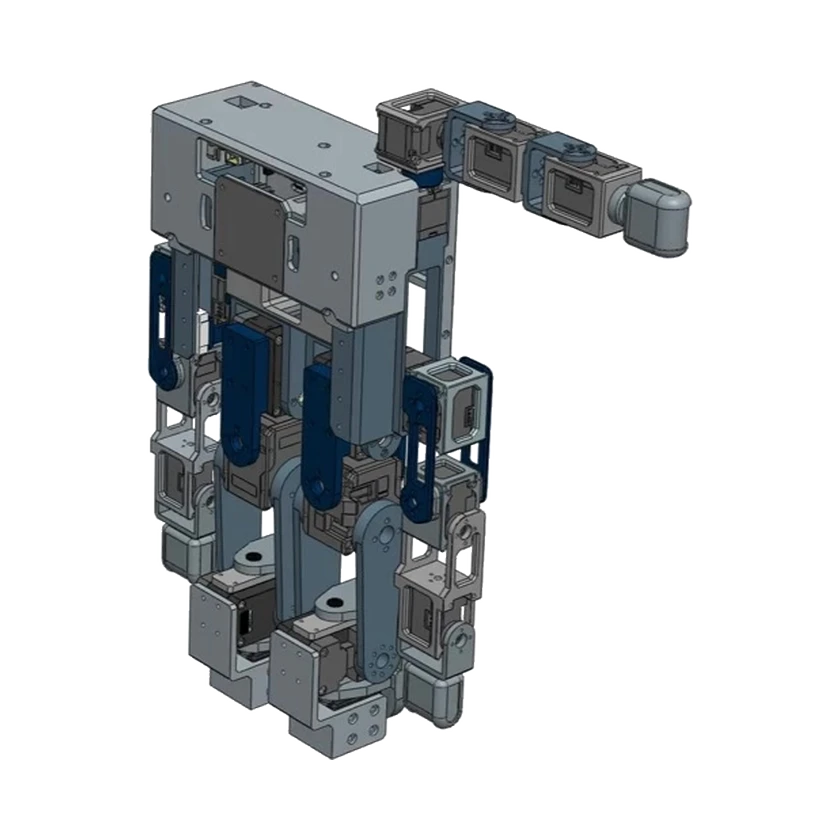
Hardware Specification
Degrees of freedom and drive
Active degrees of freedom
20 DoF per hand embodiment
Total degrees of freedom
27 DoF total
Degrees of Freedom
Controllable DOF per Arm
8 DoF across both arms in humanoid embodiment
Head DOF
4 DoF head in humanoid embodiment
Height
33 cm
DOF per Leg
12 lower-limb DoF
Weight
2.05 kg
Sensors
IMU
Distributed inertial sensing
Battery and Runtime
Max Power
180 W
Power Supply
Onboard battery or USB PD charger input up to 140 W
Compute Platform
Processor
ESP32-S3 controller
Interaction and Communication
Communication
Wi-Fi host communication; TTL bus for Dynamixel actuators
Development and Expansion
Teleoperation
Apple Vision Pro hand-tracking-based arm-hand teleoperation
Commercial Status
Status
Research prototype
Price
Not disclosed
Release Date
Jul 17, 2026
Submit a source or correction