

硬件规格
整机规格
运动性能
自由度
机械结构
传感器
电池与续航
计算平台
安全与防护
交互与通信
开发与扩展
二次开发
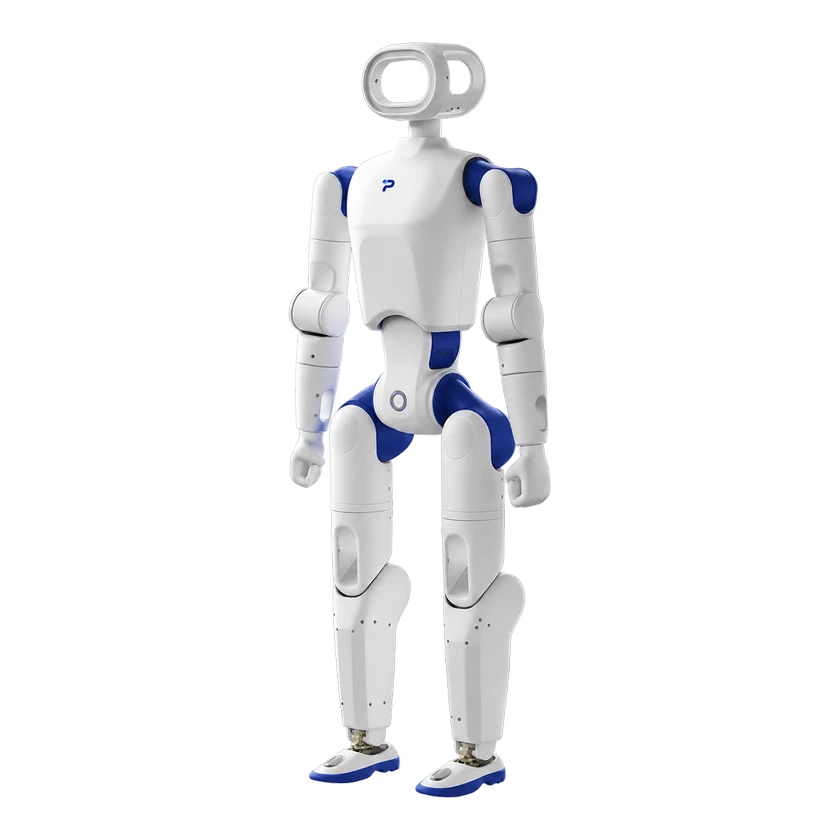
ROBOTO 01(RP1)当前型号
有条件开放仅既有RP1:官方将RP1对应24身体关节、Pro对应28身体关节另加2头部,手指另计。本批仅对应身体开发配置,条件为交付机械修订、LRO CAN-FD controller/FW、IMU/hostSDK ABI、个体零位方向/总线ID映射和闭链踝解算匹配。固定inference b3eaa0bb6a9d/motors a5c930a06a16/description8c12d13ae051;官网与固定源码的API默认值/周期/type标签不同,须整套版本兼容并核实际契约。保留物理参数/价格状态/发布,两个Pro既有记录不合并;未执行软硬件。
萝博头原型机
有条件开放仅既有RobotoOrigin/RPO原型非RP1/Pro。deploy95be3502 gitlink固定inferenceb3eaa0bb/motorsa5c930a0,Git tree只读未checkout执行。RPOconfig23DM槽/四CAN+HIPNUCserial,实际sign-offset-urdf2motor/闭链踝映射,不改物理DOF。匹配交付model固件/USB-CAN/零位config/已build ROS2Humble或Jazzy,单owner;父聚合GPL不重授submodule/binary/assets。
Exact existing RP1 record. Official series documentation maps RP1 to24 body joints and RP1 Pro to28 body joints plus2head joints; hand axes are counted separately. This batch covers the corresponding body development configuration only, conditional on matching delivered mechanical revision, LRO CAN-FD controller/firmware, IMU, host SDK ABI, calibrated zero/sign/bus-ID maps and closed-chain ankle conversion. Source pins: inference b3eaa0bb6a9d, motors a5c930a06a16, description8c12d13ae051. The current website and pinned source differ in API defaults, control periods and robot type labels; use one mutually compatible pinned stack and verify its actual contract. Preserves existing physical specifications, price/status and publication state; the two Pro records remain separate. No software/hardware executed. Body position/hybrid interface: apply_action(p,v,kp,kd,tau), URDF-to-motor permutation and sign conversion, wrapped state and nearest-turn targets. Supply every position and gain entry; actual pinned validation requires finite kp>0 and kd>=0 for every motor. The website says optional gains default from configuration, but this pinned Python binding requires explicit p,v,kp,kd; only tau has a default. Position/velocity targets must match the 24-entry body layout; check finite values, limits and state freshness before invocation. CAN-FD batches use motorID-1 in8slots per bus. Parallel ankles convert desired joint PD+feedforward to actuator position targets with positive gains. This is position development, not an independent zero-kp velocity or pure torque mode. get_joint_tau is derived from get_motor_current; the pinned LRO feedback decodes CurMax amperes, so do not interpret it as measured jointNm or apply a torque-space inverse-transpose to raw current. No independent velocity/Nm/FF, Cartesian, navigation, teleoperation or persistent collection claim is added. Constructor opens hardware interfaces; init status does not aggregate per-driver success, refresh waits then reads cache.
开发能力
身体position/hybrid:apply_action(p,v,kp,kd,tau),URDF-motor顺序/方向和wrap/最近圈目标;必须完整位置/增益长度,固定版要求每项finite kp>0/kd>=0。官网说gain可省而此Python固定版p/v/kp/kd必传、仅tau默认。24项身体顺序、finite/limits/新鲜度须核;CANFD按motorID-1在每bus8槽。并联踝将jointPD+FF转为正gain执行器位置目标,非独立零kp速度/纯力矩。get_joint_tau来自get_motor_current,LRO按CurMax反馈A,不当实测jointNm,原始current不直接套力矩逆转置。本批不填独立vel/Nm/FF/Cartesian/nav/teleop/持久采集。构造即开硬件,initflag不汇总驱动成功,refresh等待后读cache。
已知限制
- 身体position/hybrid:apply_action(p,v,kp,kd,tau),URDF-motor顺序/方向和wrap/最近圈目标;必须完整位置/增益长度,固定版要求每项finite kp>0/kd>=0。官网说gain可省而此Python固定版p/v/kp/kd必传、仅tau默认。24项身体顺序、finite/limits/新鲜度须核;CANFD按motorID-1在每bus8槽。并联踝将jointPD+FF转为正gain执行器位置目标,非独立零kp速度/纯力矩。get_joint_tau来自get_motor_current,LRO按CurMax反馈A,不当实测jointNm,原始current不直接套力矩逆转置。本批不填独立vel/Nm/FF/Cartesian/nav/teleop/持久采集。构造即开硬件,initflag不汇总驱动成功,refresh等待后读cache。
信息来源 · 4
- 官方roboparty.com ↗核验日期: 2026-11-06
- 官方raw.githubusercontent.com ↗核验日期: 2026-11-06
- 官方raw.githubusercontent.com ↗核验日期: 2026-11-06
- 官方raw.githubusercontent.com ↗核验日期: 2026-11-06
开源情况与制作资料
软件
部分开放仅示例或辅助工具已公开,不能据此认定核心系统开源。
硬件设计
待核验当前证据不足,尚未核实这一维度的公开情况。
制作资料
待核验当前证据不足,尚未核实这一维度的公开情况。
| 类型 | 资源 | 许可证 | 适用版本 | 前往 |
|---|---|---|---|---|
| 代码 | roboparty_inference · scoped primary-code license GitHub · Roboparty/roboparty_inference Complete pinnedGPLv3 grant for primary roboparty_inference C++/pybind source, consistent with parent license inventory. Bundled ONNX/runtime libraries/checkpoints, NPZ/motion data/models and subdependencies remain separately scoped; no execution or whole-robot licensing claim. | GPL-3.0-only | rp1_24dof_cpp_body_b3eaa0bb, rp1_24dof_python_body_b3eaa0bb, rp1_24dof_ros2_documented_interfaces | 前往 GitHub |
商业状态
关联实体
暂无已收录的关联产品。
时间线
- 机器人发布ROBOTO 01(RP1)