
 萝博派对
萝博头原型机
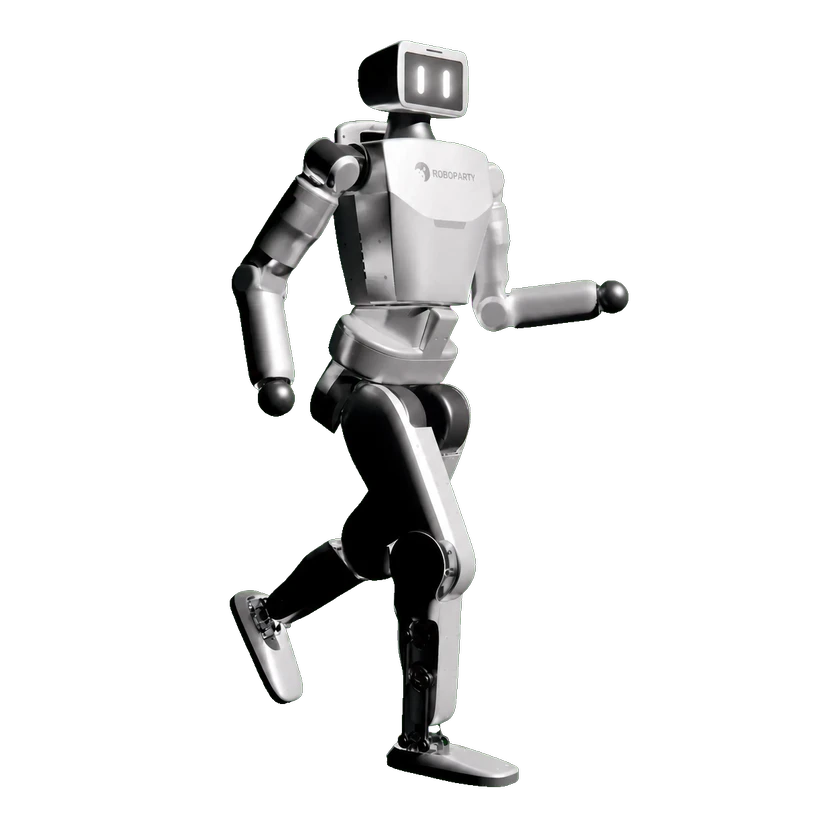
ROBOTO Origin 是 RoboParty 面向创客、科研、教育与开发者推出的开源双足人形机器人原型平台。官方资料公开其身高 1.25 米、重量 34 千克、23 自由度、最高约 3 米/秒、48V 15Ah 电池和至少 2 小时续航,并说明其采用 RDK X5 算力、可选深度相机和三维激光雷达,支持二次开发。
硬件规格
自由度与驱动
运动性能
机械尺寸与安装
传感器
电池与续航
计算平台
交互与通信
开发与扩展
二次开发
ROBOTO 01(RP1)
有条件开放仅既有RP1:官方将RP1对应24身体关节、Pro对应28身体关节另加2头部,手指另计。本批仅对应身体开发配置,条件为交付机械修订、LRO CAN-FD controller/FW、IMU/hostSDK ABI、个体零位方向/总线ID映射和闭链踝解算匹配。固定inference b3eaa0bb6a9d/motors a5c930a06a16/description8c12d13ae051;官网与固定源码的API默认值/周期/type标签不同,须整套版本兼容并核实际契约。保留物理参数/价格状态/发布,两个Pro既有记录不合并;未执行软硬件。
萝博头原型机当前型号
有条件开放仅既有RobotoOrigin/RPO原型非RP1/Pro。deploy95be3502 gitlink固定inferenceb3eaa0bb/motorsa5c930a0,Git tree只读未checkout执行。RPOconfig23DM槽/四CAN+HIPNUCserial,实际sign-offset-urdf2motor/闭链踝映射,不改物理DOF。匹配交付model固件/USB-CAN/零位config/已build ROS2Humble或Jazzy,单owner;父聚合GPL不重授submodule/binary/assets。
Exact existing RobotoOrigin/RPO prototype, not RP1/Pro variants. Pinned deploy95be3502 gitlinks fix inferenceb3eaa0bb and motorsa5c930a0, verified by Git tree without checking out/executing code. RPO reference configuration has23DMmotor slots across4CAN buses plus HIPNUCserialIMU, actualsign/offset/urdf2motor/closed-chain ankles; this does not overwrite physicalDOF. Match delivered motor models/firmware/USB-CAN/zeroing/config and built ROS2Humble-or-Jazzy workspace, one command owner. Parent aggregateGPL does not relicense submodules/binaries/assets; only scoped reviewed code grants apply. Separate isolated RPO DM-actuator driver profile bypasses robot-level joint/closed-chain mapping and must never compete with whole-body policy/control threads. Native C++ driver provides POS(rad with speedlimit), independentSPD(rad/s) and MIT(p,v,kp,kd,tau) frames. MIT gains clamp down to0, permitting explicitkp=kd=0 direct feedforward torque within exactmodel limits; with nonzero gains tau adds to PD. These are motor-shaft interfaces, not arbitrary jointNm after closed-chain transmission. Must set mode first: a mismatched firstcall only switches mode thenreturns, so a latercall sends target. ignore_limit argument is unused and implementation still clamps position/speed. Verify signs/zeros, bus/motorID/model and mechanically support coupled chain; no blanket all-joint puretorque/independentvelocity claim. No motor/framecommand executed.
开发能力
仅既有RobotoOrigin/RPO原型非RP1/Pro。deploy95be3502 gitlink固定inferenceb3eaa0bb/motorsa5c930a0,Git tree只读未checkout执行。RPOconfig23DM槽/四CAN+HIPNUCserial,实际sign-offset-urdf2motor/闭链踝映射,不改物理DOF。匹配交付model固件/USB-CAN/零位config/已build ROS2Humble或Jazzy,单owner;父聚合GPL不重授submodule/binary/assets。 独立隔离RPO DM actuator配置绕过robotjoint/闭链映射,不能与wholebody policy线程争owner。原生Cpp POS(rad+speedlimit)/独立SPD(rad-s)/MIT(pvkp-kd-tau),MIT gain可限到0,显式kp=kd=0可在精确model限额内directmotor torque;非零gain时tau叠PD。仅motor轴非闭链后任意jointNm。须先setmode,首个不同mode call仅换模式return,下次才发目标;ignore_limit参数未用、仍pos-speedclip。校signzero/IDmodelbus并支撑机构,不主张所有joint纯torquevel。未发命令。
已知限制
- 仅既有RobotoOrigin/RPO原型非RP1/Pro。deploy95be3502 gitlink固定inferenceb3eaa0bb/motorsa5c930a0,Git tree只读未checkout执行。RPOconfig23DM槽/四CAN+HIPNUCserial,实际sign-offset-urdf2motor/闭链踝映射,不改物理DOF。匹配交付model固件/USB-CAN/零位config/已build ROS2Humble或Jazzy,单owner;父聚合GPL不重授submodule/binary/assets。 独立隔离RPO DM actuator配置绕过robotjoint/闭链映射,不能与wholebody policy线程争owner。原生Cpp POS(rad+speedlimit)/独立SPD(rad-s)/MIT(pvkp-kd-tau),MIT gain可限到0,显式kp=kd=0可在精确model限额内directmotor torque;非零gain时tau叠PD。仅motor轴非闭链后任意jointNm。须先setmode,首个不同mode call仅换模式return,下次才发目标;ignore_limit参数未用、仍pos-speedclip。校signzero/IDmodelbus并支撑机构,不主张所有joint纯torquevel。未发命令。
信息来源 · 3
- 官方roboparty.com ↗核验日期: 2026-11-06
- 官方raw.githubusercontent.com ↗核验日期: 2026-11-06
- 官方raw.githubusercontent.com ↗核验日期: 2026-11-06
开源情况与制作资料
软件
部分开放仅示例或辅助工具已公开,不能据此认定核心系统开源。
硬件设计
待核验当前证据不足,尚未核实这一维度的公开情况。
制作资料
待核验当前证据不足,尚未核实这一维度的公开情况。
| 类型 | 资源 | 许可证 | 适用版本 | 前往 |
|---|---|---|---|---|
| 代码 | roboparty_inference · scoped primary-code license GitHub · Roboparty/roboparty_inference Complete pinnedGPLv3 grant for primary roboparty_inference C++/pybind source, consistent with parent license inventory. Bundled ONNX/runtime libraries/checkpoints, NPZ/motion data/models and subdependencies remain separately scoped; no execution or whole-robot licensing claim. | GPL-3.0-only | rpo_robot_pd_ff_b3eaa0bb | 前往 GitHub |
| 代码 | roboparty_motors · scoped primary-code license GitHub · Roboparty/roboparty_motors Complete pinnedGPLv3 grant for primary roboparty_motors source at parent-fixedgitlink. Firmware/device libraries, interfaces, hardware and other third-party terms remain separate; grant does not promise safety, calibrated torque after linkage, or everydriver feature. | GPL-3.0-only | rpo_isolated_dm_cpp_a5c930a0 | 前往 GitHub |
商业状态
关联实体
暂无已收录的关联产品。
时间线
- 机器人发布萝博头原型机