
 RoboParty
ROBOTO Origin
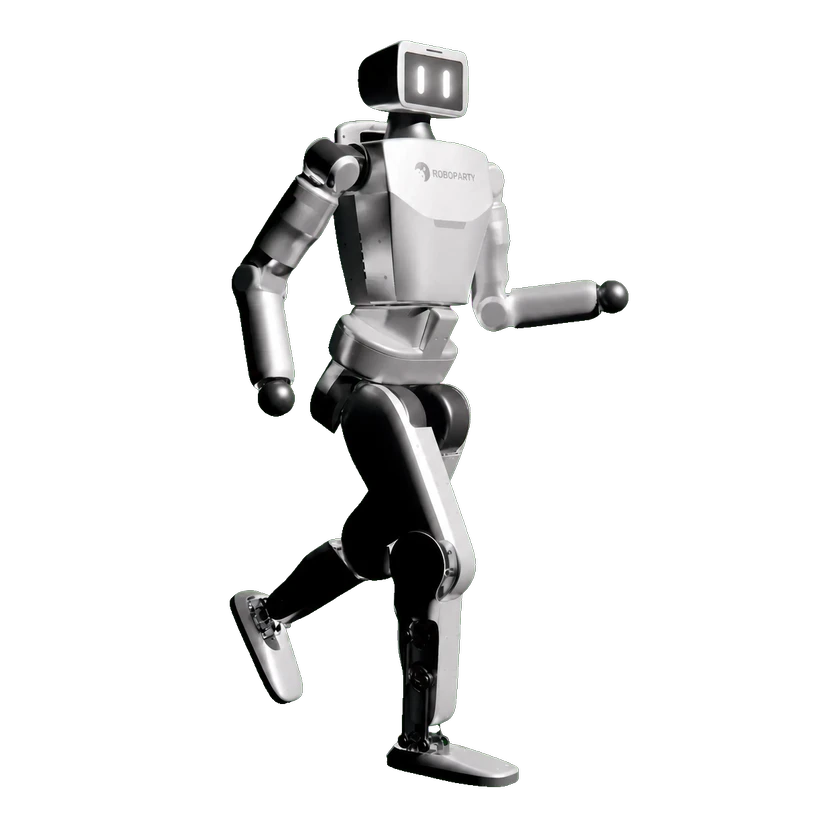
ROBOTO Origin は、RoboParty がメイカー、研究、教育、開発者向けに提供するオープンソースの二足ヒューマノイド試作プラットフォームです。公式資料には身長1.25m、重量34kg、23自由度、最高約3m/s、48V 15Ahバッテリー、2時間以上の稼働時間が記載されています。RDK X5を搭載し、深度カメラと3D LiDARをオプションで選べ、二次開発に対応します。
ハードウェア仕様
自由度と駆動
運動性能
機械・取付
センサー
バッテリーと稼働時間
計算プラットフォーム
インタラクションと通信
開発と拡張
二次開発
ROBOTO 01(RP1)
条件付きで開発可能既存RP1、RP1身体24/Pro身体28+head2、hand別計。対応bodyのみ、納入revision/FW/LRO CANFD/ABI/calib/閉鎖足首整合条件。websiteとpinnedAPI/default周期差を保持、仕様公開状態保持、二Pro非統合、未実行。
ROBOTO Origin現在のモデル
条件付きで開発可能既存RPOOriginのみ、deploygitlinksでinference/motors固定。23DMslots/4CAN/signclosechain整合、physicalDOF非変更、RP1非継承、scopedmodulegrantのみ。
Exact existing RobotoOrigin/RPO prototype, not RP1/Pro variants. Pinned deploy95be3502 gitlinks fix inferenceb3eaa0bb and motorsa5c930a0, verified by Git tree without checking out/executing code. RPO reference configuration has23DMmotor slots across4CAN buses plus HIPNUCserialIMU, actualsign/offset/urdf2motor/closed-chain ankles; this does not overwrite physicalDOF. Match delivered motor models/firmware/USB-CAN/zeroing/config and built ROS2Humble-or-Jazzy workspace, one command owner. Parent aggregateGPL does not relicense submodules/binaries/assets; only scoped reviewed code grants apply. Separate isolated RPO DM-actuator driver profile bypasses robot-level joint/closed-chain mapping and must never compete with whole-body policy/control threads. Native C++ driver provides POS(rad with speedlimit), independentSPD(rad/s) and MIT(p,v,kp,kd,tau) frames. MIT gains clamp down to0, permitting explicitkp=kd=0 direct feedforward torque within exactmodel limits; with nonzero gains tau adds to PD. These are motor-shaft interfaces, not arbitrary jointNm after closed-chain transmission. Must set mode first: a mismatched firstcall only switches mode thenreturns, so a latercall sends target. ignore_limit argument is unused and implementation still clamps position/speed. Verify signs/zeros, bus/motorID/model and mechanically support coupled chain; no blanket all-joint puretorque/independentvelocity claim. No motor/framecommand executed.
開発機能
既存RPOOriginのみ、deploygitlinksでinference/motors固定。23DMslots/4CAN/signclosechain整合、physicalDOF非変更、RP1非継承、scopedmodulegrantのみ。 別isolatedDMmotorPOS/SPD/MIT、gain0directtorque可/PD+tau、closedchainjointNmとは別。firstcallmodechangeのみ/limits実装、ownermechanicalsupport条件、未実行。
確認済みの制約
- 既存RPOOriginのみ、deploygitlinksでinference/motors固定。23DMslots/4CAN/signclosechain整合、physicalDOF非変更、RP1非継承、scopedmodulegrantのみ。 別isolatedDMmotorPOS/SPD/MIT、gain0directtorque可/PD+tau、closedchainjointNmとは別。firstcallmodechangeのみ/limits実装、ownermechanicalsupport条件、未実行。
情報源 · 3
- 公式roboparty.com ↗確認日: 2026-11-06
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
オープンソースと製作資料
ソフトウェア
一部公開例や補助ツールのみ公開されています。中核システムの公開を意味しません。
ハードウェア設計
未検証この項目について十分な検証済みの根拠がありません。
製作資料
未検証この項目について十分な検証済みの根拠がありません。
| 種類 | 資料 | ライセンス | 対象バージョン | 開く |
|---|---|---|---|---|
| コード | roboparty_inference · scoped primary-code license GitHub · Roboparty/roboparty_inference Complete pinnedGPLv3 grant for primary roboparty_inference C++/pybind source, consistent with parent license inventory. Bundled ONNX/runtime libraries/checkpoints, NPZ/motion data/models and subdependencies remain separately scoped; no execution or whole-robot licensing claim. | GPL-3.0-only | rpo_robot_pd_ff_b3eaa0bb | 開く GitHub |
| コード | roboparty_motors · scoped primary-code license GitHub · Roboparty/roboparty_motors Complete pinnedGPLv3 grant for primary roboparty_motors source at parent-fixedgitlink. Firmware/device libraries, interfaces, hardware and other third-party terms remain separate; grant does not promise safety, calibrated torque after linkage, or everydriver feature. | GPL-3.0-only | rpo_isolated_dm_cpp_a5c930a0 | 開く GitHub |
商用ステータス
関連エンティティ
関連製品はまだ登録されていません。
タイムライン
- ロボット公開ROBOTO Origin