
 RoboParty
ROBOTO
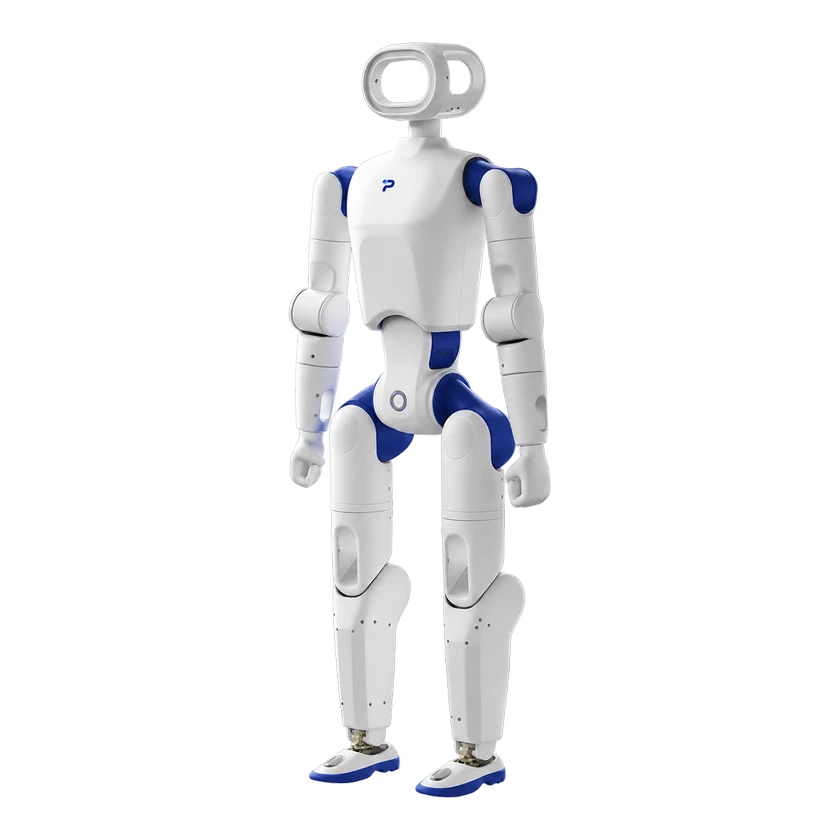
RP1は、RoboPartyの研究・教育・開発向けオープンソース二足歩行ヒューマノイドです。高さ1.35 m、重量約39 kg、能動自由度24。運動制御用ヘッド、ダミーハンド、RK3588を標準装備し、バッテリーのホットスワップとモジュール交換に対応します。
ハードウェア仕様
本体仕様
運動性能
自由度
機械構造
センサー
バッテリーと稼働時間
計算プラットフォーム
安全と保護
インタラクションと通信
開発と拡張
二次開発
ROBOTO 01(RP1)現在のモデル
条件付きで開発可能既存RP1、RP1身体24/Pro身体28+head2、hand別計。対応bodyのみ、納入revision/FW/LRO CANFD/ABI/calib/閉鎖足首整合条件。websiteとpinnedAPI/default周期差を保持、仕様公開状態保持、二Pro非統合、未実行。
ROBOTO Origin
条件付きで開発可能既存RPOOriginのみ、deploygitlinksでinference/motors固定。23DMslots/4CAN/signclosechain整合、physicalDOF非変更、RP1非継承、scopedmodulegrantのみ。
Exact existing RP1 record. Official series documentation maps RP1 to24 body joints and RP1 Pro to28 body joints plus2head joints; hand axes are counted separately. This batch covers the corresponding body development configuration only, conditional on matching delivered mechanical revision, LRO CAN-FD controller/firmware, IMU, host SDK ABI, calibrated zero/sign/bus-ID maps and closed-chain ankle conversion. Source pins: inference b3eaa0bb6a9d, motors a5c930a06a16, description8c12d13ae051. The current website and pinned source differ in API defaults, control periods and robot type labels; use one mutually compatible pinned stack and verify its actual contract. Preserves existing physical specifications, price/status and publication state; the two Pro records remain separate. No software/hardware executed. Body position/hybrid interface: apply_action(p,v,kp,kd,tau), URDF-to-motor permutation and sign conversion, wrapped state and nearest-turn targets. Supply every position and gain entry; actual pinned validation requires finite kp>0 and kd>=0 for every motor. The website says optional gains default from configuration, but this pinned Python binding requires explicit p,v,kp,kd; only tau has a default. Position/velocity targets must match the 24-entry body layout; check finite values, limits and state freshness before invocation. CAN-FD batches use motorID-1 in8slots per bus. Parallel ankles convert desired joint PD+feedforward to actuator position targets with positive gains. This is position development, not an independent zero-kp velocity or pure torque mode. get_joint_tau is derived from get_motor_current; the pinned LRO feedback decodes CurMax amperes, so do not interpret it as measured jointNm or apply a torque-space inverse-transpose to raw current. No independent velocity/Nm/FF, Cartesian, navigation, teleoperation or persistent collection claim is added. Constructor opens hardware interfaces; init status does not aggregate per-driver success, refresh waits then reads cache.
開発機能
body位置hybrid、p/v/kp/kd明示必須、kp>0/kd>=0、tauのみdefault。24bodymap/IDslot/calib/新鮮性条件。anklePD→motorposition、get_joint_tau実体AでNm非推論、独立vel/torque/FF等未確認。constructorhardware/未実行。
確認済みの制約
- body位置hybrid、p/v/kp/kd明示必須、kp>0/kd>=0、tauのみdefault。24bodymap/IDslot/calib/新鮮性条件。anklePD→motorposition、get_joint_tau実体AでNm非推論、独立vel/torque/FF等未確認。constructorhardware/未実行。
情報源 · 4
- 公式roboparty.com ↗確認日: 2026-11-06
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
オープンソースと製作資料
ソフトウェア
一部公開例や補助ツールのみ公開されています。中核システムの公開を意味しません。
ハードウェア設計
未検証この項目について十分な検証済みの根拠がありません。
製作資料
未検証この項目について十分な検証済みの根拠がありません。
| 種類 | 資料 | ライセンス | 対象バージョン | 開く |
|---|---|---|---|---|
| コード | roboparty_inference · scoped primary-code license GitHub · Roboparty/roboparty_inference Complete pinnedGPLv3 grant for primary roboparty_inference C++/pybind source, consistent with parent license inventory. Bundled ONNX/runtime libraries/checkpoints, NPZ/motion data/models and subdependencies remain separately scoped; no execution or whole-robot licensing claim. | GPL-3.0-only | rp1_24dof_cpp_body_b3eaa0bb, rp1_24dof_python_body_b3eaa0bb, rp1_24dof_ros2_documented_interfaces | 開く GitHub |
商用ステータス
関連エンティティ
関連製品はまだ登録されていません。
タイムライン
- ロボット公開ROBOTO 01(RP1)