
 RoboParty
ROBOTO Origin
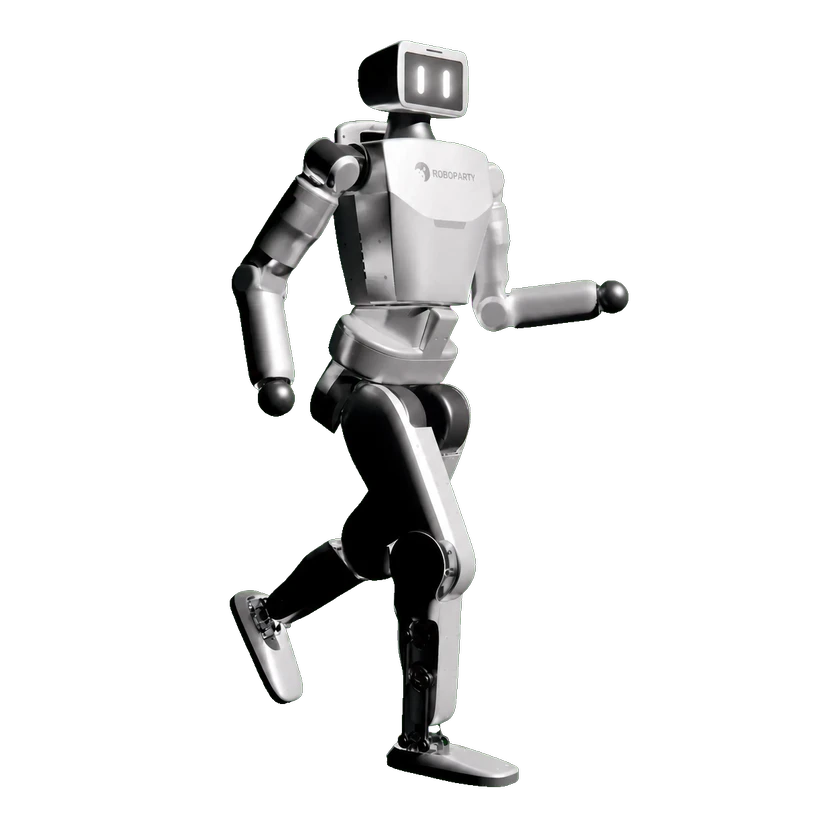
ROBOTO Origin is RoboParty’s open-source bipedal humanoid prototype platform for makers, research, education, and developers. Official materials specify a 1.25 m height, 34 kg weight, 23 DoF, top speed of about 3 m/s, 48 V 15 Ah battery, and at least two hours of runtime. It uses RDK X5 compute, offers optional depth-camera and 3D LiDAR sensing, and supports secondary development.
Hardware Specification
Degrees of freedom and drive
Mobility & Payload
Mechanical and mounting
Sensors
Battery and Runtime
Compute Platform
Interaction and Communication
Development and Expansion
Development support
ROBOTO 01(RP1)
Conditional accessExact existing RP1 record. Official series documentation maps RP1 to24 body joints and RP1 Pro to28 body joints plus2head joints; hand axes are counted separately. This batch covers the corresponding body development configuration only, conditional on matching delivered mechanical revision, LRO CAN-FD controller/firmware, IMU, host SDK ABI, calibrated zero/sign/bus-ID maps and closed-chain ankle conversion. Source pins: inference b3eaa0bb6a9d, motors a5c930a06a16, description8c12d13ae051. The current website and pinned source differ in API defaults, control periods and robot type labels; use one mutually compatible pinned stack and verify its actual contract. Preserves existing physical specifications, price/status and publication state; the two Pro records remain separate. No software/hardware executed.
ROBOTO OriginCurrent model
Conditional accessExact existing RobotoOrigin/RPO prototype, not RP1/Pro variants. Pinned deploy95be3502 gitlinks fix inferenceb3eaa0bb and motorsa5c930a0, verified by Git tree without checking out/executing code. RPO reference configuration has23DMmotor slots across4CAN buses plus HIPNUCserialIMU, actualsign/offset/urdf2motor/closed-chain ankles; this does not overwrite physicalDOF. Match delivered motor models/firmware/USB-CAN/zeroing/config and built ROS2Humble-or-Jazzy workspace, one command owner. Parent aggregateGPL does not relicense submodules/binaries/assets; only scoped reviewed code grants apply.
Exact existing RobotoOrigin/RPO prototype, not RP1/Pro variants. Pinned deploy95be3502 gitlinks fix inferenceb3eaa0bb and motorsa5c930a0, verified by Git tree without checking out/executing code. RPO reference configuration has23DMmotor slots across4CAN buses plus HIPNUCserialIMU, actualsign/offset/urdf2motor/closed-chain ankles; this does not overwrite physicalDOF. Match delivered motor models/firmware/USB-CAN/zeroing/config and built ROS2Humble-or-Jazzy workspace, one command owner. Parent aggregateGPL does not relicense submodules/binaries/assets; only scoped reviewed code grants apply. Separate isolated RPO DM-actuator driver profile bypasses robot-level joint/closed-chain mapping and must never compete with whole-body policy/control threads. Native C++ driver provides POS(rad with speedlimit), independentSPD(rad/s) and MIT(p,v,kp,kd,tau) frames. MIT gains clamp down to0, permitting explicitkp=kd=0 direct feedforward torque within exactmodel limits; with nonzero gains tau adds to PD. These are motor-shaft interfaces, not arbitrary jointNm after closed-chain transmission. Must set mode first: a mismatched firstcall only switches mode thenreturns, so a latercall sends target. ignore_limit argument is unused and implementation still clamps position/speed. Verify signs/zeros, bus/motorID/model and mechanically support coupled chain; no blanket all-joint puretorque/independentvelocity claim. No motor/framecommand executed.
Development capabilities
Sources · 3
- Officialroboparty.com ↗Verified: 2026-11-06
- Officialraw.githubusercontent.com ↗Verified: 2026-11-06
- Officialraw.githubusercontent.com ↗Verified: 2026-11-06
Open source & build resources
Software
Partially availableExamples or supporting tools are available; this does not establish access to the core system.
Hardware design
Not verifiedThere is not enough verified evidence to establish this dimension.
Build resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | roboparty_inference · scoped primary-code license GitHub · Roboparty/roboparty_inference Complete pinnedGPLv3 grant for primary roboparty_inference C++/pybind source, consistent with parent license inventory. Bundled ONNX/runtime libraries/checkpoints, NPZ/motion data/models and subdependencies remain separately scoped; no execution or whole-robot licensing claim. | GPL-3.0-only | rpo_robot_pd_ff_b3eaa0bb | Open GitHub |
| Code | roboparty_motors · scoped primary-code license GitHub · Roboparty/roboparty_motors Complete pinnedGPLv3 grant for primary roboparty_motors source at parent-fixedgitlink. Firmware/device libraries, interfaces, hardware and other third-party terms remain separate; grant does not promise safety, calibrated torque after linkage, or everydriver feature. | GPL-3.0-only | rpo_isolated_dm_cpp_a5c930a0 | Open GitHub |
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseROBOTO Origin