
 RoboParty
RP Hand
Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
6 DOF
Active degrees of freedom
0.369–0.389 kg
Hand weight
5
Finger count
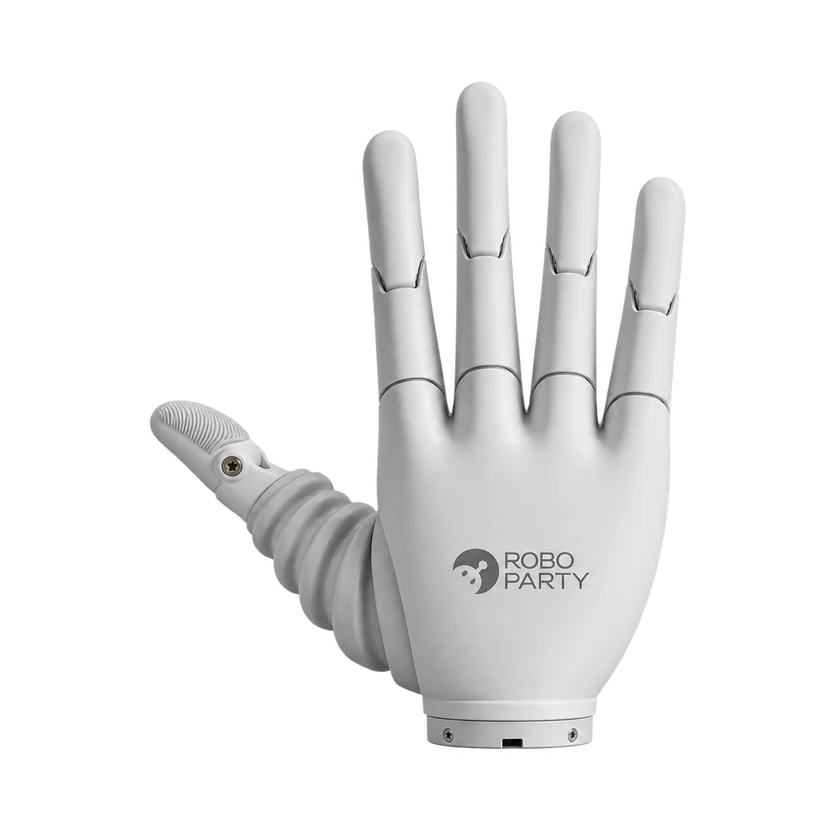
RP Hand is RoboParty’s slim five-finger hand for humanoid integration. It has six active axes, eleven mechanical degrees of freedom and worm-gear transmission. Standard hardware uses CAN FD; official resources cover C++, Python, Linux ROS 2 and left/right models.
Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Degrees of freedom and drive
Finger count
5
Actuator technology
Brushless coreless motor modules
Active degrees of freedom
6 DOF
Ingress Protection (IP)
IP30
Total degrees of freedom
11 DOF
Transmission mechanism
Worm gear
Joint Motion Range
0–87.5 °
Joint Motion Range
0–65 °
Joint Motion Range
0–72 °
Mechanical and mounting
Depth
2.635 cm
Length
14.754 cm
Hand weight
0.369–0.389 kg
Width
7.353 cm
Mechanical Structure
Joint Encoder
Integrated driver and miniature encoder
Load Cycles
250000
Load Cycles
250000
Maximum current
≤2.5 A
Static current
≤0.1 A
Battery and Runtime
Power Supply
12 V (-10%) to 48 V (+10%)
Compute Platform
Operating System
Windows; Linux
Reliability and environment
Operating humidity
10–90 %RH
Operating temperature
-10–45 °C
Interaction and Communication
Communication
Standard CAN FD; RS485 and EtherCAT require custom hardware
Development and Expansion
Integration Interface
Linux SocketCAN; Windows WinUSB/gs_usb (A8FA:8598 single-channel adapter); CAN FD+BRS 1 Mbps/5 Mbps
Secondary Development (SDK)
C++17, Python 3.9+; current rphand API; Linux ROS 2
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
No related products recorded yet.
Submit a source or correction