
Learning ApproachOfficial claim
Reinforcement learning
 UBTECH Robotics
Walker Tienkung is UBTECH’s full-size humanoid platform for academic research, education and secondary development, with adaptive locomotion, dynamic balance, open interfaces and teleoperation.
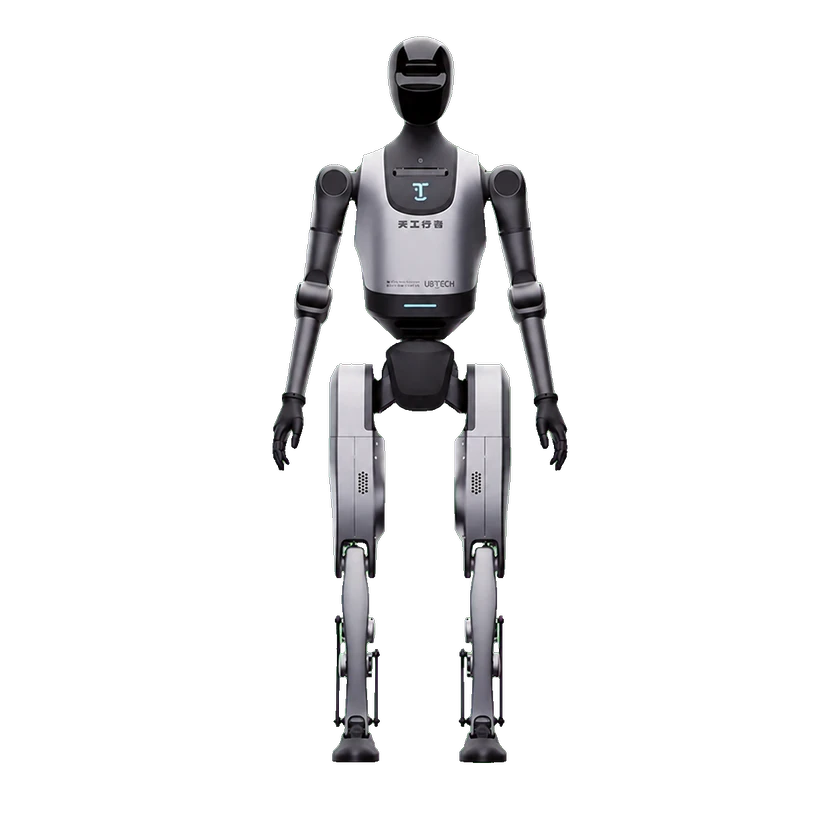
Experiments do not imply factory configuration. Evidence applies only to the named model version.
UBTECH states that the Tiangong Xingzhe series can stand, walk, run, and adapt stably to slopes and sandy terrain.
UBTECH states that the Tiangong Xingzhe series has dynamic balance and disturbance-rejection capability.
Development configuration: Walker Tienkung V2.0.7.x interfaces
Series-wide interface declaration in the V2.0.7.x manual. Match the purchased SKU, actual joint layout and delivered SDK; optional hands/compute are not assumed.
The V2.0.7.x manufacturer manual explicitly lists joint/sensor interfaces, teleoperation and data collection across the series. Use the delivered SDK and actual SKU layout; this does not establish particular control modes, language bindings or optional peripherals.
No related products recorded yet.
