
 UBTECH Robotics
Walker S1 Dexterous Hand
Walker S1 Third-generation Five-finger Hand
Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Pilot only
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-07
6 DoF per hand
Active degrees of freedom
5 fingers
Finger count
UBTECH’s third-generation anthropomorphic five-finger dexterous hand is integrated with Walker S1 for industrial manufacturing and home-service tasks. Six array tactile pressure sensors monitor grasp force, while a full-stack dexterous-operation strategy library supports reusable skills for precise grasping and assembly of flexible objects.
1 / 1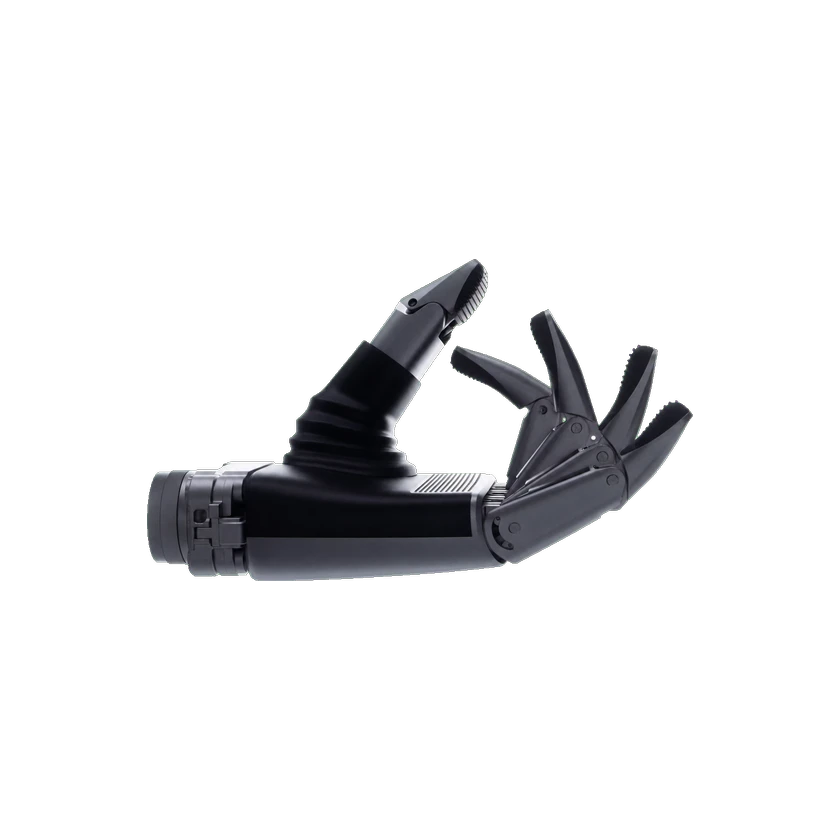
Hardware Specification
Degrees of freedom and drive
Active degrees of freedom
6 DoF per hand
Total degrees of freedom
6 DoF (reported total)
Motion and coordination
Coordination architecture
Full-stack strategy library with industrial-scenario skill training
Mechanical and mounting
Mounting interface
Walker S1 arm-end wrist mounting interface
Mechanical Structure
Dexterous Hand
Self-developed third-generation anthropomorphic dexterous hand
Dexterous Hand Model
Third-generation anthropomorphic five-finger hand
End-Effector
Anthropomorphic five-finger dexterous hand
Joint Type
Articulated mechanical finger linkage
Sensors
Force/Torque Sensor
Tactile pressure arrays for grasp-force monitoring
Sensors
Six array tactile pressure sensors
Tactile Sensor
Six array tactile pressure sensors
Compute Platform
Software Algorithm
Full-stack dexterous-operation strategy library
Interaction and Communication
Tactile Feedback
Precise grasp-force monitoring
Development and Expansion
Configuration Options
Walker S1 integrated dexterous-hand configuration
Integration Interface
Walker S1 / ROSA 2.0 application framework integration
Operating Modes
Skill-library-based dexterous operation
Workflow Integration
Integrated with Walker S1 for factory training
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Robots related to “Walker S1 Third-generation Five-finger Hand”
Submit a source or correction