
LernansatzOffizielle Angabe
Bestärkendes Lernen
 UBTECH Robotics
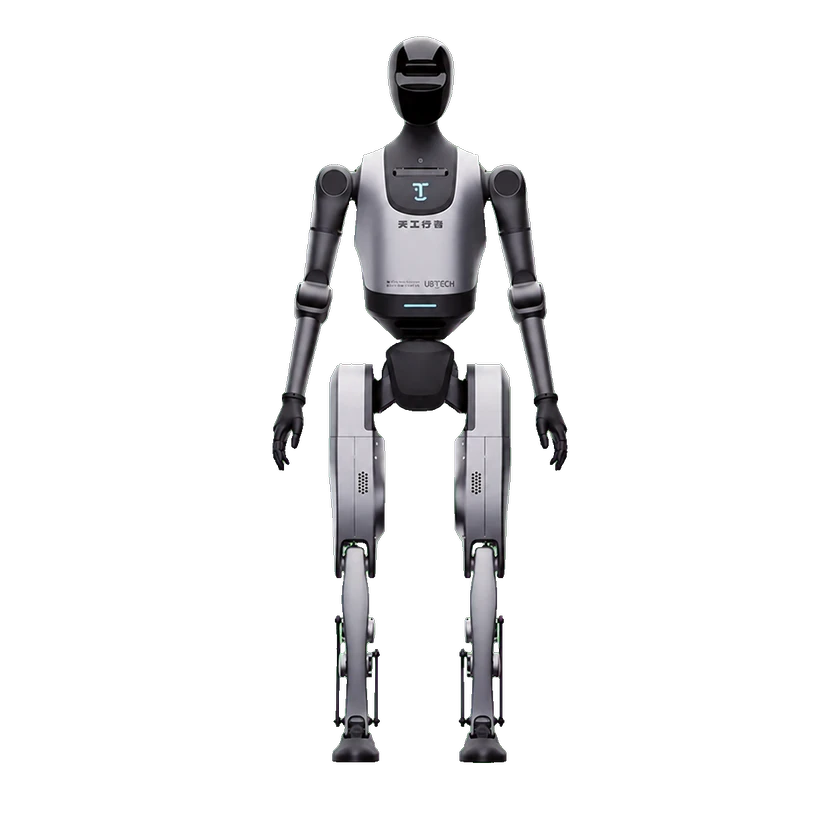
Walker Tienkung ist die humanoide Plattform in voller Größe von UBTECH für akademische Forschung, Bildung und Weiterentwicklung mit adaptiver Fortbewegung, dynamischem Gleichgewicht, offenen Schnittstellen und Teleoperation.
Versuche bedeuten keine Serienausstattung. Belege gelten nur für die genannte Modellversion.
UBTECH states that the Tiangong Xingzhe series can stand, walk, run, and adapt stably to slopes and sandy terrain.
UBTECH states that the Tiangong Xingzhe series has dynamic balance and disturbance-rejection capability.
Entwicklungskonfiguration: Walker Tienkung V2.0.7.x interfaces
Series-wide interface declaration in the V2.0.7.x manual. Match the purchased SKU, actual joint layout and delivered SDK; optional hands/compute are not assumed.
The V2.0.7.x manufacturer manual explicitly lists joint/sensor interfaces, teleoperation and data collection across the series. Use the delivered SDK and actual SKU layout; this does not establish particular control modes, language bindings or optional peripherals.
Noch keine verwandten Produkte erfasst.
