
GRW公式仕様
通信・制御
通信プロトコル · メーカー公表
EtherCAT
出典と動作条件
Joint communication interface: EtherCAT
Joint communication bus; external host I/O is listed separately.
GRW official brochure, page 5, Joint Spec., Communication Interface 2026-10-15 Fourier Intelligence
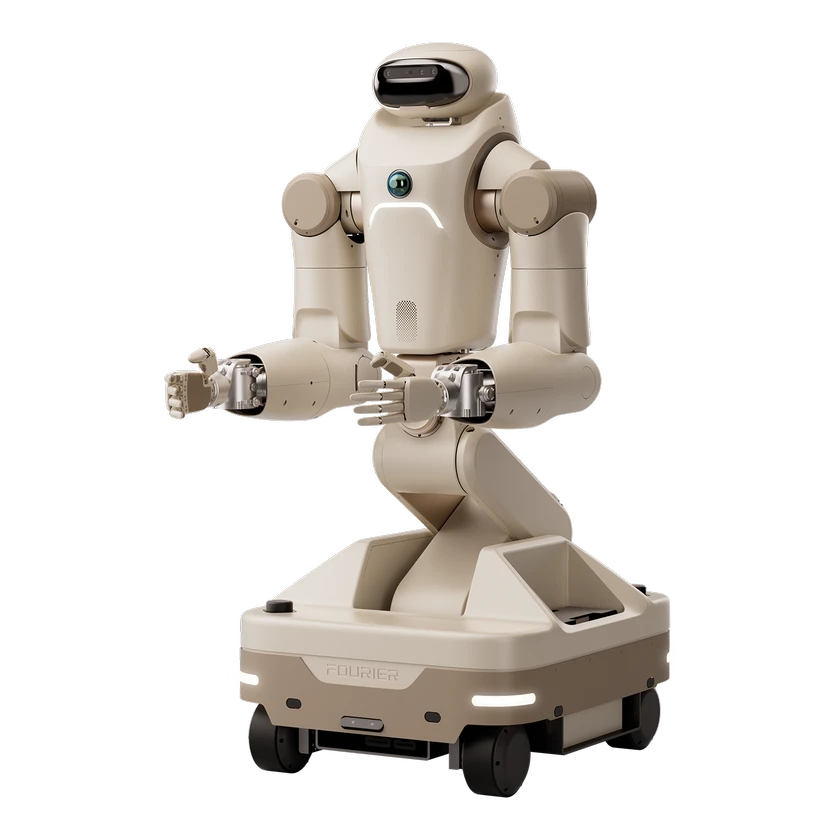
Fourier GRWは車輪式双腕ロボットです。29自由度と197 cmのアームスパンはいずれもエンドエフェクターを含みません。バッテリーは各720 Whを2基搭載し、2,000回以上のサイクル寿命は放電深度80%の条件です。Orin/Thor演算モジュールとエンドエフェクターは選択式です。
Joint communication interface: EtherCAT
Joint communication bus; external host I/O is listed separately.
GRW official brochure, page 5, Joint Spec., Communication Interface 2026-10-15