MobilityOfficial claim
Walking
Unitree states that H1 can walk and run autonomously in complex terrain and environments.
Unitree H1 is a 180 cm, 47 kg humanoid with 5 leg DOF, 4 arm DOF, 3.3 m/s speed and 864 Wh battery.
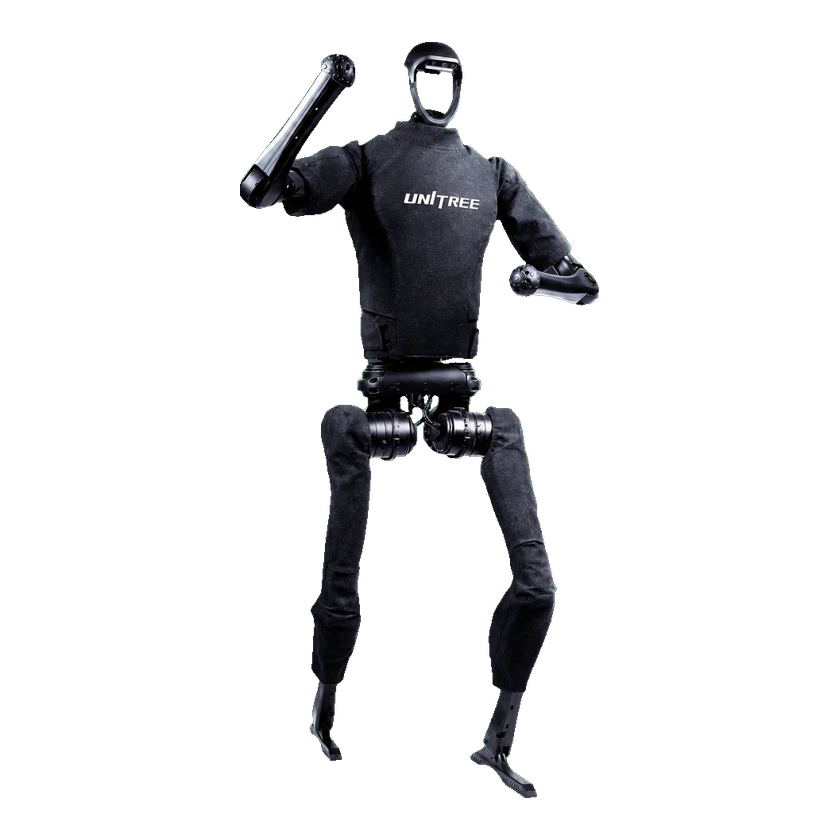
Unitree states that H1 can walk and run autonomously in complex terrain and environments.
Unitree describes H1 as having a stable gait and highly flexible movement capabilities.
Development configuration: Original H1 (not H1-2)
Exact documented development profile. Hardware, firmware and access conditions are recorded per capability.
Model-specific Python SDK2 example. Requires the matching SDK2 firmware, developer access and network setup; disable competing high-level control as documented.
Official ROS 2 examples; match CycloneDDS, message definitions and the installed firmware.
Joint-level control, C++ SDK, Position commands, Velocity commands, and PD + feedforward torque · Official C++ low-level example exposes q/dq, PD gains and feedforward torque. Requires the matching hardware and low-level control permissions; not a direct torque-mode claim.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
There is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | Unitree SDK2 Python GitHub · unitreerobotics/unitree_sdk2_python Pinned source revision 814556d15970dd2ecf1c9984e845ca02ab07e206. License applies to this repository; hardware, firmware, dependencies and robot access have separate terms. | BSD-3-Clause | h1_original | Open GitHub |
| Code | H1 Python SDK wireless-controller example GitHub · unitreerobotics/unitree_sdk2_python Official SDK example explicitly supports H1 for reading wireless-controller data. Follow the H1-specific message-type configuration in the source. This auxiliary example does not establish that the complete onboard system is open. | BSD-3-Clause | H1 | Open GitHub |
| Simulation | H1 ROS robot-description and simulation assets GitHub · unitreerobotics/unitree_ros Official ROS repository lists this robot model. These robot-description assets support visualization and simulation; they do not establish published manufacturing drawings or complete onboard software. Match the model configuration before use. | BSD-3-Clause | H1 | Open GitHub |
Statuses reflect historical reports; subsequent operating conditions are unknown.
Deployment records 1 · Customer test 1 · Project actual units · Undisclosed
潮新闻 reported on 2024-11-10 that a Unitree H1 had recently completed an assembly test on a dynamic line at a Geely subsidiary factory; the photo caption credits Geely’s Guiyang factory. The article says the motions were not yet seamless. The report date is not the test date. The test date, unit count, payment, and any later or current operation are unknown.