
 RoboParty
ROMOMO
- Output torque · Rated
- 10 N·m
- Weight
- 0.5331 kg
- Outer diameter
- 65 mm
- Operating voltage
- 48 V
RoboParty’s ROMOMO RMM6562-2E integrates an inner-rotor motor, an NGW planetary reducer, a drive and two magnetic encoders. It is rated at 48 V DC, 10 N·m and 60 rpm, with 35 N·m peak torque. It supports CAN-FD and EtherCAT and appears in both RP1.3.4 bills of materials.
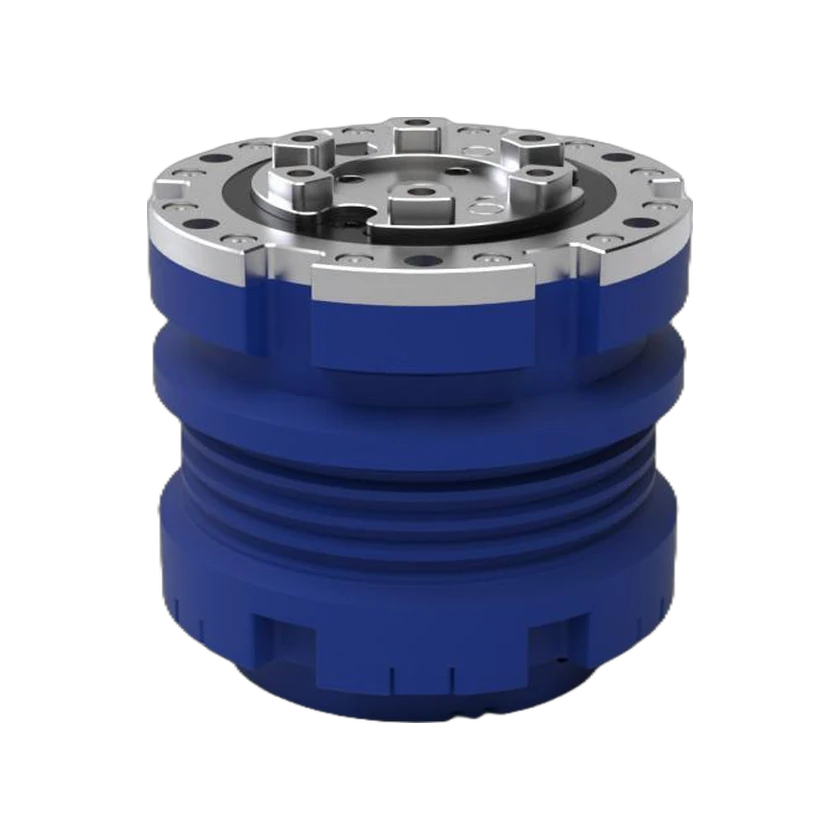
Technical specifications
Output & transmission
- Output torque · Rated
10 N·m
48 V DC
- Output torque · Peak
35 N·m
48 V DC
- Output torque
10.02 N·m
Pending verification
48 V DC
- Output torque
10.04 N·m
Pending verification
48 V DC
- Output torque
37.17 N·m
Pending verification
48 V DC
- Output torque
35.6 N·m
Pending verification
48 V DC
- Output torque
5.3 N·m
Pending verification
48 V DC
- Output speed · Rated
60 rpm
48 V DC
- Output speed · Peak
200 rpm
48 V DC
- Output speed · No load
200 rpm
48 V DC
- Output speed
60.16 rpm
48 V DC
- Output speed
60.15 rpm
48 V DC
- Backlash
≤15 arcmin
Dimensions & installation
- Weight
0.5331 kg
- Outer diameter
65 mm
Scope not bound
- Axial length · Nominal range
60.7–61.7 mm
Scope not bound
- Axial length · Nominal body specification
62 mm
Scope not bound
- Hollow bore diameter
4.5 mm
Scope not bound
Electrical
- Operating voltageDC power input
48 V
- Operating currentDC power input
1.93 A
48 V DC
- Operating current
0.128 A
Scope not bound
48 V DC
- Operating current
0.548 A
Scope not bound
48 V DC
- Operating currentDC power input
1.96 A
48 V DC
- Operating current
0.141 A
Scope not bound
48 V DC
- Operating current
0.517 A
Scope not bound
48 V DC
- Operating current
14.74 A
Scope not bound
48 V DC
- Operating current
24.58 A
Scope not bound
48 V DC
- Electrical power
92.29 W
Scope not bound
48 V DC
- Electrical power
93.84 W
Scope not bound
48 V DC
Encoders & feedback
- Encoder type
Dual magnetic encoders
Scope not bound
- Encoder resolutionmotor_side
17 bit
- Encoder resolutionoutput_side
19 bit
Communication & control
- Communication interface
CAN-FD
- Communication interface
EtherCAT
- Communication protocol
EtherCAT
- Control mode
Position control / Velocity control / Torque control / MIT hybrid control
- Control loop rate
20000 Hz
- Control loop rate
1000 Hz
Braking & environment
- Protection functions
Overcurrent / Overtemperature / Short circuit / Undervoltage
- Cooling method
Passive housing cooling
Scope not bound
Construction & components
- Motor type
Inner-rotor motor
Scope not bound
- Motor integration
Integrated
Scope not bound
- Reducer integration
Integrated
Scope not bound
- Encoder integration
Integrated
Scope not bound
- Driver integration
Integrated
Scope not bound
- Controller integration
Integrated
Scope not bound
Model-level records · configuration applicability unverified
- Mounting interface
- Clamp mounting
- Weight
- ≤0.53 kg
- Weight
- 0.5331 kg
- Gear Ratio
- 19.5:1
- Joint Type
- Rotary integrated joint
- Maximum current
- 16 A
- Operating voltage
- 48 V
- Operating voltage
- 24–60 V
- Rated current
- 2 A
- Rated power
- 62.8 W
- Rated power
- 63.12 W
- Rated power
- 63.21 W
- Reducer Type
- NGW planetary
- Torque Density · Original specification
- 18.798 N·m/kg · Pending verification
- Onboard Compute
- HPM5E3YIGN1
Source · 6
2026-11-19
Weight · 533.1 g
Electrical power · 92.29 W · PDF pp. 2–3
Electrical power · 93.84 W · PDF pp. 2–3
Operating current · 1.93 A · PDF pp. 2–3
Operating current · 0.128 A · PDF pp. 2–3
Operating current · 0.548 A · PDF pp. 2–3
Operating current · 1.96 A · PDF pp. 2–3
Operating current · 0.141 A · PDF pp. 2–3
Operating current · 0.517 A · PDF pp. 2–3
Operating current · 14.74 A · PDF p. 3
Operating current · 24.58 A · PDF p. 3
Output speed · 60.16 rpm · PDF pp. 2–3
Output speed · 60.15 rpm · PDF pp. 2–3
Output torque · 10.02 N·m · PDF pp. 2–3
Output torque · 10.04 N·m · PDF pp. 2–3
Output torque · 37.17 N·m · PDF p. 3
Output torque · 35.6 N·m · PDF p. 3
Output torque · 5.3 N·m · PDF p. 6
Rated power · 63.12 W
Rated power · 63.21 W
Torque Density · 18.798 N·m/kg
2026-11-19
Operating voltage · 48 V DC
Backlash · ≤15 arcmin · Specification table
Encoder resolution · 17 bit · Specification table
Encoder resolution · 19 bit · Specification table
Output speed · 60 rpm · Specification table
Output speed · 200 rpm · Specification table
Output speed · 200±10% rpm · Specification table
Output torque · 10±5% N·m · Specification table
Output torque · 35 N·m · Specification table
Weight · ≤530 g
Gear Ratio · 19.5:1
Maximum current · 16±10% A
Rated current · 2±5% A
Rated power · 62.8±5% W
2026-11-19
Communication interface · CAN-FD · §3.4
Communication interface · EtherCAT · §3.4
Communication protocol · EtherCAT · §3.4
Control loop rate · 20000 Hz · §4
Control loop rate · 1000 Hz · §3.4
Cooling method · Passive housing cooling · §3.1
Encoder type · Dual magnetic encoders · §3.3, §4
Controller integration · Integrated · §1, §3.1
Driver integration · Integrated · §1, §3.1
Encoder integration · Integrated · §1, §3.1
Motor integration · Integrated · §1, §3.1
Reducer integration · Integrated · §1, §3.1
Protection functions · Overcurrent · §3.3, §4
Protection functions · Overtemperature · §3.3, §4
Protection functions · Short circuit · §3.3, §4
Protection functions · Undervoltage · §3.3, §4
Joint Type · Rotary integrated joint
Operating voltage · 24–60 V DC
Onboard Compute · HPM5E3YIGN1
2026-11-19
Control mode · Position control · §2.2
Control mode · Velocity control · §2.2
Control mode · Torque control · §2.2
Control mode · MIT hybrid control · §2.2
2026-11-19
Axial length · 61.2 ±0.5 mm · ROMOMO 6562 / 尺寸与重量
Mounting interface · Clamp mounting
2026-11-19
Axial length · 62 mm · Table 1.6
Hollow bore diameter · 4.5 mm · Table 1.6
Motor type · Inner-rotor motor · §1.4
Outer diameter · 65 mm · Table 1.6
Reducer Type · NGW planetary
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | RMM10062-2EV1.0 · 22:1 | RMM6562-2EV1.0 · 19.5:1 |
|---|---|---|
| Weight | 1.197 kg | — |
| Operating voltage | 48 V | 48 V |
| Operating voltage · Allowed range | 24–60 V | — |
| Communication interface · Manufacturer reported | CAN (CAN-FD) | — |
| Communication interface · Manufacturer reported | Ethernet (EtherCAT) | — |
| Communication protocol | CAN-FDScope not bound | — |
| Communication protocol | EtherCATScope not bound | — |
| Backlash | 11.4 arcminScope not bound | — |
| Operating current | 9.65 A 48 V DC | — |
| Operating current | 9.46 A 48 V DC | — |
| Outer diameter | 100 mmScope not bound | 65 mmScope not bound |
| Output speed · Rated | 80 rpm 48 V DC | 60 rpm 48 V DC |
| Output speed · Peak | 130 rpm | — |
| Output speed | 80.33 rpm 48 V DC | — |
| Output speed | 80.34 rpm 48 V DC | — |
| Output torque · Rated | 44 N·m 48 V DC | 10 N·m 48 V DC |
| Output torque | 40.83 N·m 48 V DC | — |
| Output torque | 44.03 N·m 48 V DC | — |
| Output torque | 44.02 N·m 48 V DC | — |
| Weight | — | 0.5331 kg |
| Communication interface | — | CAN-FD |
| Communication interface | — | EtherCAT |
| Communication protocol | — | EtherCAT |
| Backlash | — | ≤15 arcmin |
| Encoder resolution | — | 17 bit |
| Encoder resolution | — | 19 bit |
| Operating current | — | 1.93 A 48 V DC |
| Operating current | — | 1.96 A 48 V DC |
| Output speed · Peak | — | 200 rpm 48 V DC |
| Output speed · No load | — | 200 rpm 48 V DC |
| Output torque · Peak | — | 35 N·m 48 V DC |
Commercial Status
Related Entities
No related products recorded yet.