
 maxon
High Efficiency Joints (HEJ)
- Output torque · Rated
- 75 N·m
- Weight
- 2.006 kg
- Outer diameter
- ≈108 mm
- Operating voltage · Allowed range
- 30–60 V
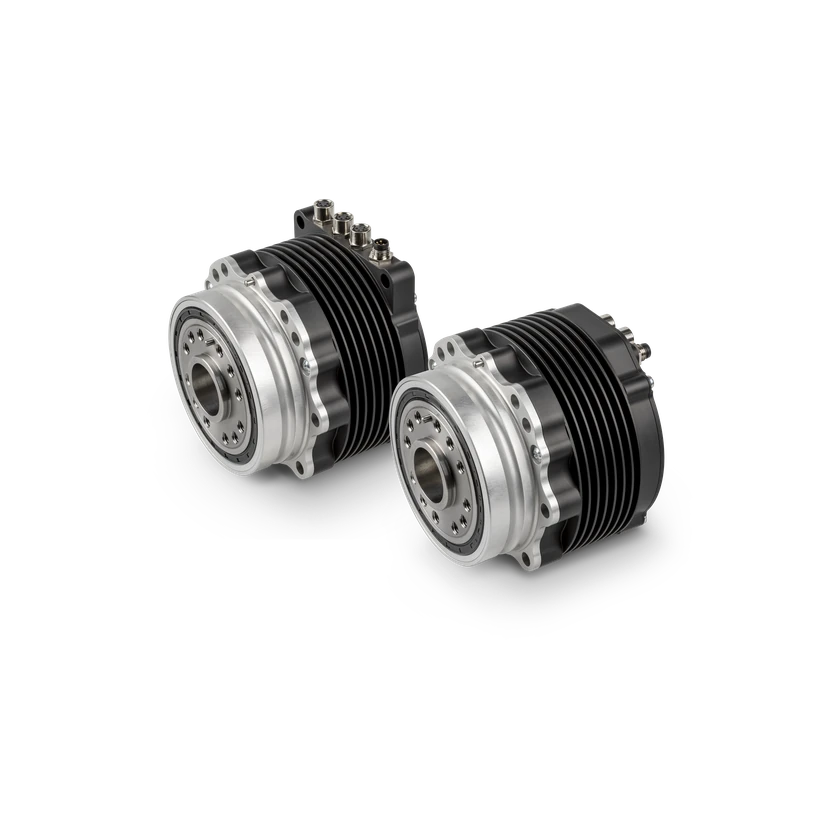
The maxon HEJ 90-48-140 is an integrated joint for robot locomotion and propulsion. It combines a motor, planetary gearing, sensors and control electronics in an IP67 enclosure. It delivers 75 N·m nominal torque and 140 N·m repeatable peak torque, supports EtherCAT, and comes with radial or axial connectors.
Technical specifications
Output & transmission
- Output torque · Rated
75 N·m
48 V DC
- Output torque · Peak
140 N·m
48 V DC
- Output speed
99.3127 rpm
48 V DC
- Output speed
124.1409 rpm
60 V DC
- Backdrive torque · Maximum
≤1.5 N·m
Scope not bound
- Backlash
30 arcmin
Scope not bound
- Output inertia
0.045 kg·m²
Scope not bound
Dimensions & installation
- Weight
2.006 kg
- Rated torque density
37.39 N·m/kg
Based on net joint mass
dc_point · 48–48 V
- Peak torque density
69.79 N·m/kg
Based on net joint mass
dc_point · 48–48 V
- Outer diameter
≈108 mm
Scope not bound
- Axial length
≈90 mm
Scope not bound
Electrical
- Operating voltage · Allowed rangeDC power input
30–60 V
- Operating current · ContinuousDC power input
8 A
- Operating current · MaximumDC power input
≤40 A
- Operating currentDC power input
30.1 A
48 V DC
Encoders & feedback
- Encoder type
Absolute (output)
Scope not bound
- Encoder turn mode
Single-turn
Scope not bound
- Encoder resolution
12 bit
Scope not bound
- Torque feedback method
Compensated motor-current estimation
Scope not bound
Communication & control
- Communication interface
Ethernet
- Communication protocol
EtherCAT
- Control mode
Position / Velocity / Torque / Motor current (FOC) / Impedance
- Command rate · Maximum
1000 Hz
- Control loop rate
25000 Hz
- Control loop rate
2500 Hz
Braking & environment
- Protection functions
Configurable motor i²t protection
Scope not bound
- IP rating
IP67
Scope not bound
- Cooling method
External forced air
Scope not bound
Construction & components
- Ordering code
831220
Scope not bound
- Transmission mechanism
Planetary gearing
Scope not bound
- Motor integration
Integrated
Scope not bound
- Reducer integration
Integrated
Scope not bound
- Encoder integration
Integrated
Scope not bound
- Driver integration
Integrated
Scope not bound
- Controller integration
Integrated
Scope not bound
Other specifications
- Connector type
M8
Scope not bound
- CAD availability
Available on request
Scope not bound
Model-level records · configuration applicability unverified
- Ingress Protection (IP)
- IP67
- Joint Bearing
- Cross-roller output bearing
- Joint Type
- Integrated robotic joint
- Torque Accuracy
- <1.5 N·m (steady state)
- Operating temperature
- -20–60 °C
Source · 2
2026-11-21
Transmission mechanism · Planetary gearing · High Efficiency Joints for mobile robots
2026-11-21
Weight · 2.006 kg (radial connector version) · p. 3
Connector type · Up to 4 × M8; 1 power supply, 2 EtherCAT; fan power/control only on the radial connector configuration · p. 3
Operating voltage · 30–60 V DC. Lower voltage down to 20 V is possible with implications. Contact maxon. · p. 2
Command rate · Max. EtherCAT communication rate 1 kHz · p. 2
Communication interface · Full Duplex, 100 Mbit/s; 2 × EtherCAT · p. 3
Communication protocol · Full Duplex, 100 Mbit/s; 2 × EtherCAT · p. 3
Control loop rate · 25 kHz current controller (FOC) · p. 2
Control loop rate · 2.5 kHz all other controllers · p. 2
Control mode · Position · p. 2
Control mode · Velocity · p. 2
Control mode · Torque · p. 2
Control mode · Motor current (FOC) · p. 2
Control mode · Impedance · p. 2
CAD availability · Available on request · p. 4
IP rating · IP67, also with rotating joint and applied bending moments · p. 3
Axial length · ca. 90 mm, overall axial length excluding connectors · p. 3
Backdrive torque · <1.5 N·m · p. 2
Backlash · 0.5° average · p. 2
Cooling method · Integrated heat sinks for forced air cooling; continuous active heat dissipation up to ca. 250 W · p. 3
Encoder resolution · 12 bit · p. 2
Encoder turn mode · Single-turn · p. 2
Encoder type · Output position after the gear. Absolute angular error: <0.008 rad (0.5°). · p. 2
Controller integration · Integrated · p. 1
Driver integration · Integrated · p. 1
Encoder integration · Integrated · p. 1
Motor integration · Integrated · p. 1
Reducer integration · Integrated · p. 1
Operating current · 8.0 A RMS maximum continuous DC-link supply input current, rev. 2.3 · p. 2
Operating current · <40 A (unloaded transients/accelerations, excluding capacitive inrush) · p. 2
Operating current · 48 V DC | 5 rad/s | 140 N·m | 30.1 A DC-link input | 744.0 W total system loss | 48% efficiency · p. 1
Ordering code · P/N 831220, REV 05 · p. 5
Outer diameter · ca. 108 mm, outside diameter excluding connectors · p. 3
Output inertia · 0.045 kg·m² · p. 2
Output speed · ±10.4 rad/s at 48 V · p. 1
Output speed · ±13.0 rad/s at 60 V · p. 1
Output torque · ±75 Nm nominal joint torque · p. 1
Output torque · ±140 Nm actively controlled and repetitive · p. 1
Protection functions · Configurable motor i²t protection · p. 2
Torque feedback method · Compensated motor-current estimation · p. 2
Rated torque density · 75 N·m
Rated torque density · 2.006 kg
Peak torque density · 140 N·m
Peak torque density · 2.006 kg
Weight · 1.987 kg (axial connector version) · p. 3
Ordering code · P/N 895330, REV 02 · p. 7
Rated torque density · 1.987 kg
Peak torque density · 1.987 kg
Ingress Protection (IP) · IP67, also with rotating joint and applied bending moments
Joint Bearing · THK RA6008 or similar; Ø76 mm, C=5680 N, C0=8680 N
Joint Type · Integrated robotic joint
Torque Accuracy · Absolute error, steady-state: <1.5 Nm
Operating temperature · −20°C to +60°C, might require adequate cooling if the system exhibits losses
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | HEJ 50-48-30922156 rev.01 | HEJ 90-48-140Radial connectors · 831220 |
|---|---|---|
| Weight | 0.53 kg | — |
| Operating voltage · Allowed range | 30–60 V | — |
| Communication interface | EtherCAT | — |
| Backlash | 30 arcmin | — |
| Encoder resolution | 14 bit | — |
| Encoder type | Absolute | — |
| Operating current | 4.7 A | — |
| Operating current · Less than | <40 A | — |
| Operating current | 7.3 A 48 V DC | — |
| Outer diameter | ≈71.5 mm | — |
| Output speed · Maximum | 200.5352 rpm 48 V DC | — |
| Output speed · Maximum | 248.2817 rpm 60 V DC | — |
| Output torque · Rated | 11 N·m 48 V DC | — |
| Output torque · Peak | 28 N·m 48 V DC | — |
| Weight | — | 2.006 kg |
| Operating voltage · Allowed range | — | 30–60 V |
| Communication interface | — | Ethernet |
| Communication protocol | — | EtherCAT |
| IP rating | — | IP67Scope not bound |
| Backlash | — | 30 arcminScope not bound |
| Operating current · Continuous | — | 8 A |
| Operating current · Maximum | — | ≤40 A |
| Operating current | — | 30.1 A 48 V DC |
| Outer diameter | — | ≈108 mmScope not bound |
| Output speed | — | 99.3127 rpm 48 V DC |
| Output speed | — | 124.1409 rpm 60 V DC |
| Output torque · Rated | — | 75 N·m 48 V DC |
| Output torque · Peak | — | 140 N·m 48 V DC |
| Rated torque density | — | 37.39 N·m/kg Based on net joint mass dc_point · 48–48 V |
| Peak torque density | — | 69.79 N·m/kg Based on net joint mass dc_point · 48–48 V |
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseHEJ 90-48-140