GITAI logoGITAI

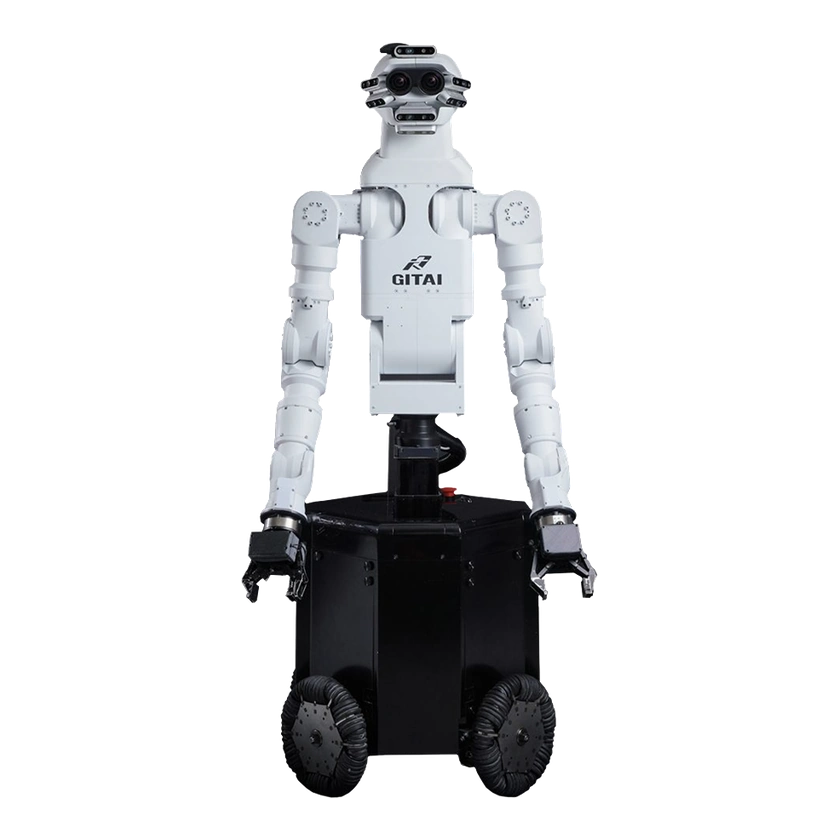
GITAI G1

Price
Unknown
Type
Humanoid Robots · Wheeled Humanoid
Applications
Construction & Field Work · Space Operations
Status
Prototype
Availability
Pilot only
Purchase
Not disclosed
Release Date
2020
Country/Region
Japan
Last Verified
2026-07-30
How classification and status work

Category describes physical structure and function; wheels alone do not determine whether a robot is humanoid. Product stage describes demonstrated maturity. Commercial availability describes current access: a commercial product may still be limited to pilot customers. Neither stage nor availability alone proves that a product can be purchased. Unknown facts remain unknown.

21 DOF
Total degrees of freedom
2 m
Height
120 kg
Weight
1.11 m/s
Walking Speed

GITAI G1 is a humanoid space robot with dual arms, cameras, AI autonomy and teleoperation for space tasks.

1 / 1GITAI G1

Intelligence Profile

Learning ApproachOfficial claim
Teleoperation
Capability Map

ManipulationOfficial claim
Tool use

The government material identifies G1 as a general-purpose space work robot and describes space-station work such as operating switches and cables and assembling panels.

AutonomyOfficial claim
Autonomous operation

The government material describes G1 as a robot for automating general tasks inside and outside space stations and in lunar-base development.

Hardware Specification

Degrees of freedom and drive

Arm Specifications
Dual-arm manipulation; 8 DoF per arm
Materials
Iron, aluminum, and 3D-printed parts
Total degrees of freedom
21 DOF

Mobility & Payload

Peak Joint Output Torque
245 Nm / 47.5 rpm
Walking Speed
1.11 m/s

Mechanical and mounting

Controllable DOF per Arm
8 DoF per arm
Height
2 m
Length
40 cm
Weight
120 kg
Width
40 cm

Mechanical Structure

Actuator Model
GITAI custom actuators; 245 Nm / 47.5 rpm

Sensors

Camera
High-resolution, wide-FOV cameras
Sensors
High-resolution cameras and vision and actuator sensors

Battery and Runtime

Power Supply
Battery or external power, depending on application

Compute Platform

Onboard Compute
NVIDIA Jetson compute module
Software Algorithm
Custom software based on ROS and OpenCV

Development and Expansion

Operating Modes
Autonomous control and teleoperation
Teleoperation
AI autonomy and teleoperation

Commercial Status

Status
Prototype
Price
Unknown
Release Date
2020

Timeline

  1. Robot release
    GITAI G1
Submit a source or correction