
Robot Data Collection Systems
Explore source-backed systems for robot demonstration, teleoperation, motion capture, and training-data collection.
Showing 11 robot data collection systems models
| Component | Organization | Country | Device form factor | Collection method | Captured data | Robot required during capture | Actions |
|---|---|---|---|---|---|---|---|
 Perception Neuron 3Perception Neuron 3 | Noitom | China | Body wearable | Motion capture | Full-body joint motion | Not required | |
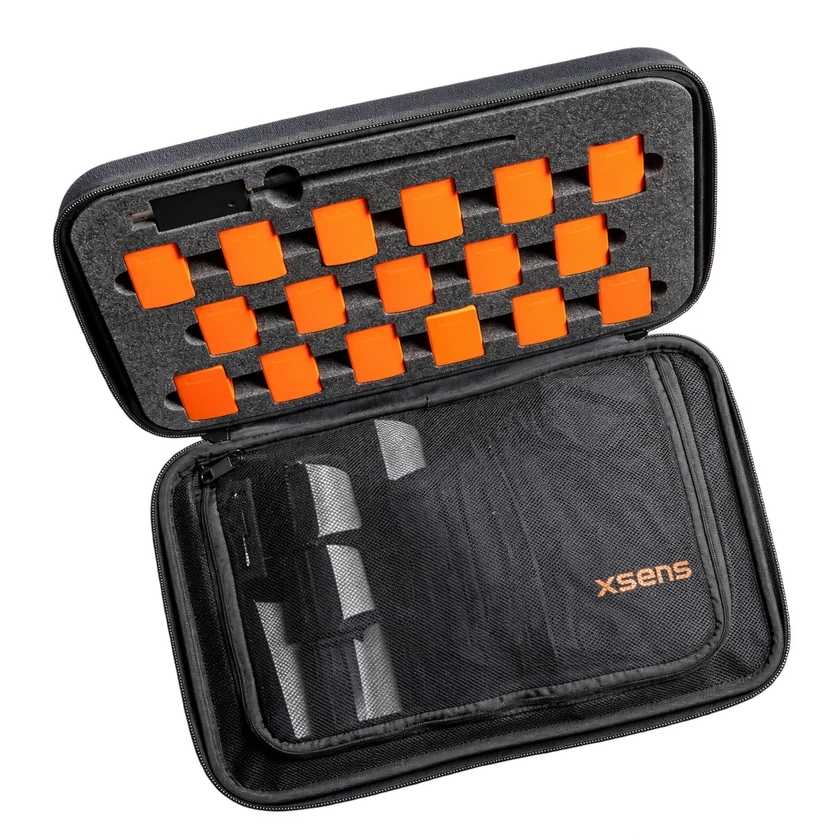 Xsens AwindaXsens Awinda | Xsens(Movella) | Netherlands | Body wearable | Teleoperation · Motion capture | Full-body joint motion | Not required | |
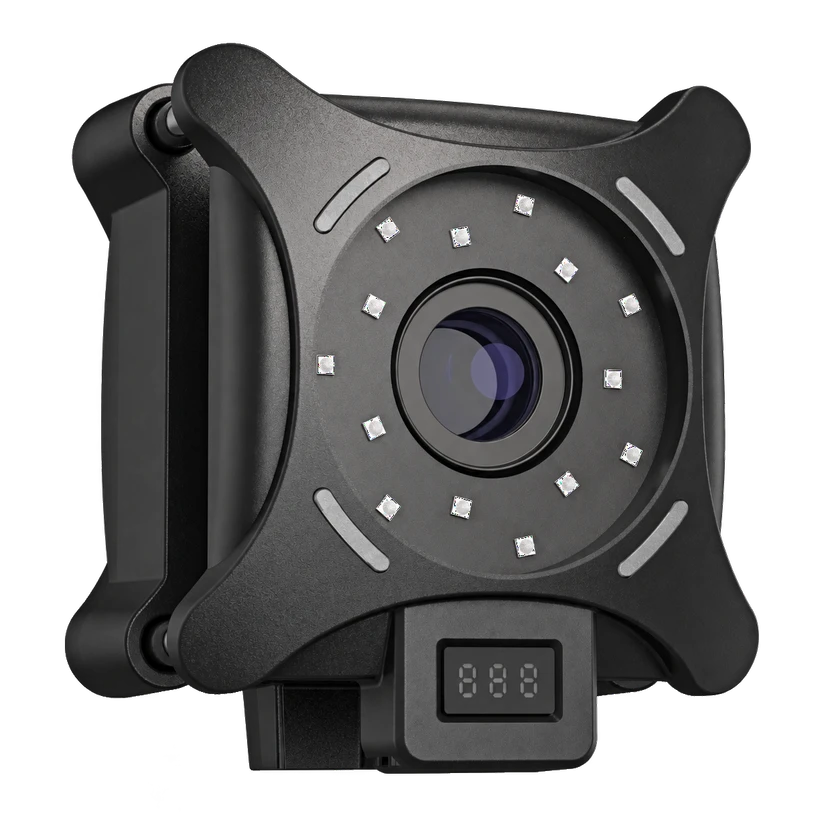 NOKOV MARSNOKOV MARS | NOKOV | China | Motion capture system | Teleoperation · Motion capture | 3D marker pose | Not required | |
| CHINGMU Motion CaptureCHINGMU Motion Capture | CHINGMU | China | Motion capture system | Motion capture · Teleoperation | 3D marker pose · Full-body motion | Not required | |
| Qualisys MiqusQualisys Miqus | Qualisys | Sweden | Motion capture system | Motion capture | 3D marker pose | Not required | |
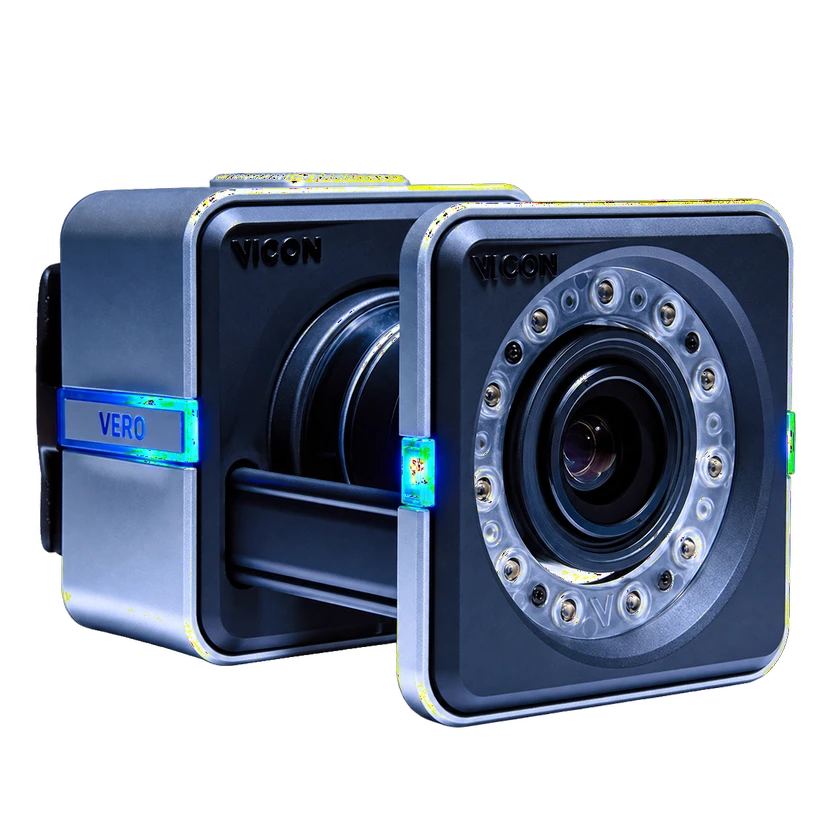 Vicon Vero v2.2Vicon Vero v2.2 | Vicon | United Kingdom | Motion capture system | Motion capture | 3D marker pose | Not required | |
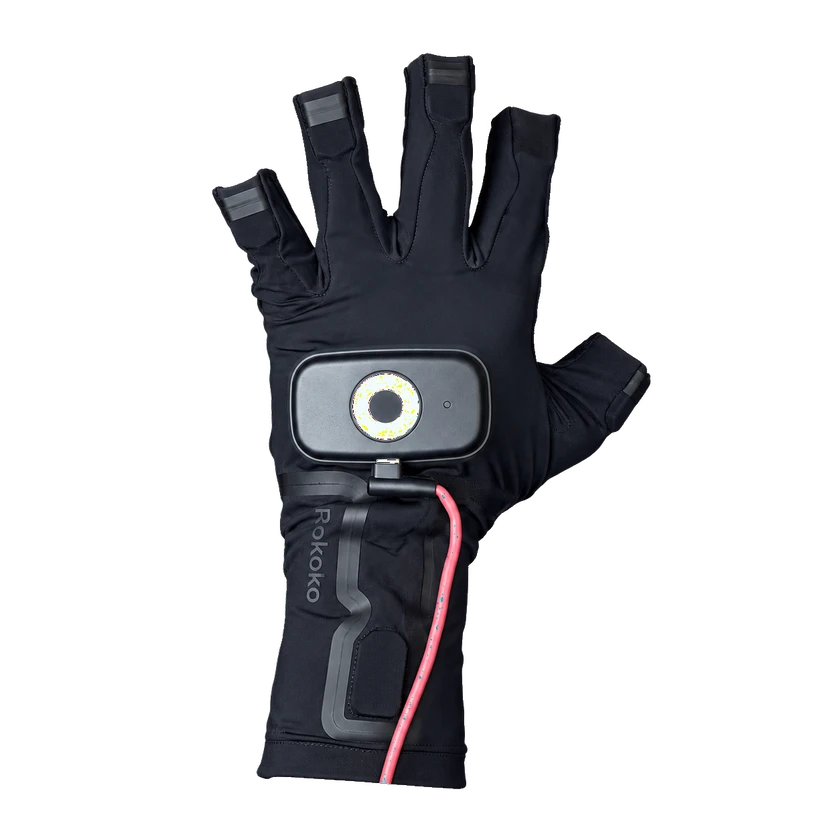 Rokoko Smartgloves IIRokoko Smartgloves II | Rokoko | Denmark | Hand wearable | Motion capture | Wrist position | Not required | |
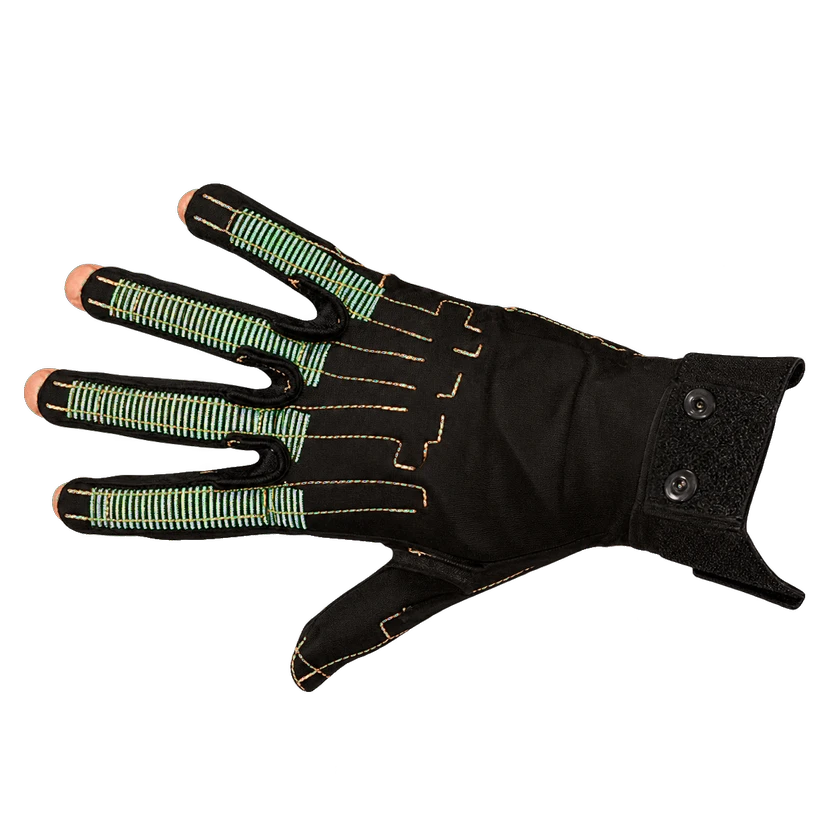 CyberGlove IIICyberGlove III | CyberGlove Systems | United States | Hand wearable | Motion capture | Finger joint angle · Joint angle | Not required | |
| StretchSense Mocap GlovesStretchSense Mocap Gloves | StretchSense | New Zealand | Hand wearable | Motion capture | Hand motion · Full-body motion | Not required | |
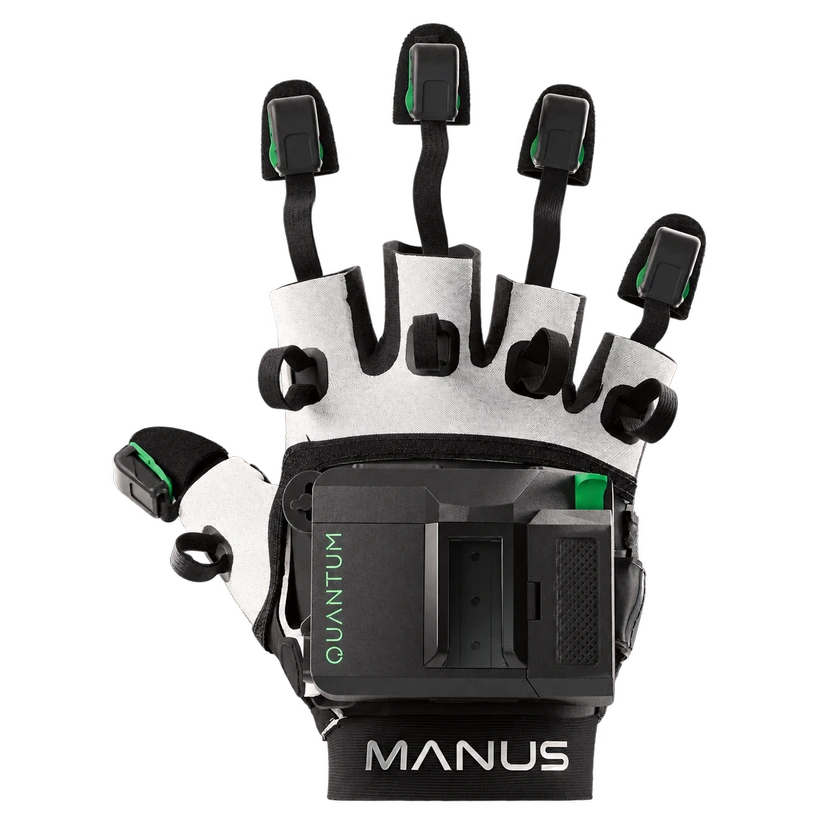 MANUS QuantumMANUS Quantum | MANUS | Netherlands | Hand wearable | Motion capture | Finger pose · Hand skeleton | Not required | |
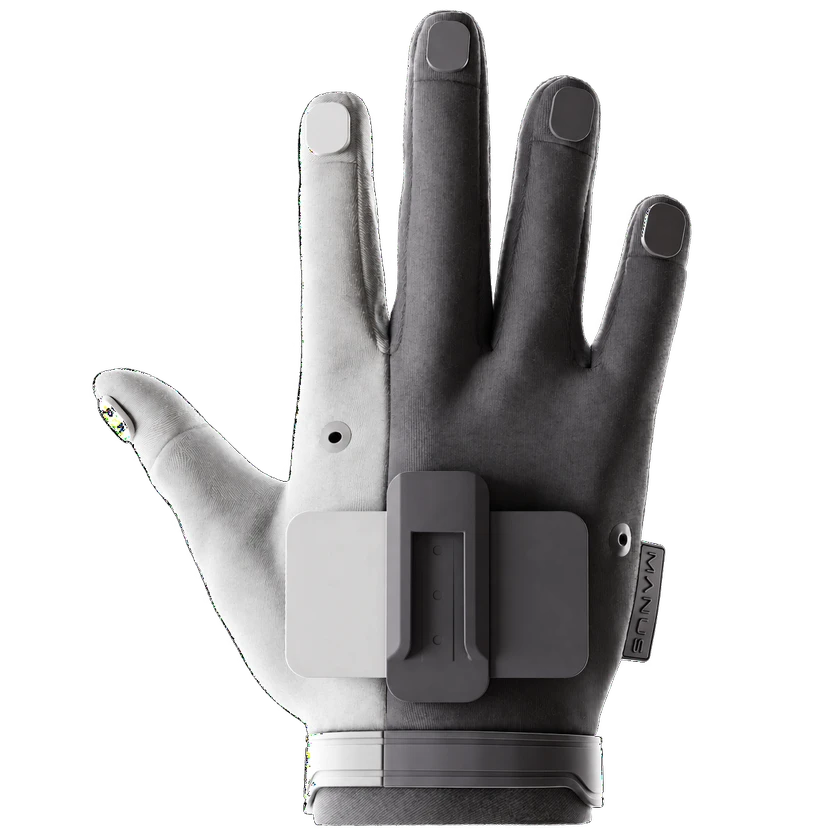 MANUS Metagloves ProMANUS Metagloves Pro | MANUS | Netherlands | Hand wearable | Teleoperation · Motion capture | Finger pose · Wrist orientation · Hand skeleton | Not required |
Submit a source or correction