Unitree Robotics logoUnitree Robotics

G1 EDU

Price
Price not disclosed
Type
Humanoid Robots · Compact Humanoid
Applications
Research & Education · Education Platform
Status
Commercial
Availability
On sale
Purchase
Not disclosed
Release Date
May 13, 2024
Country/Region
China
23–43
Total degrees of freedom
1.32 m
Height
35 kg
Weight
2 h
Runtime

Unitree G1 EDU is the education and development version of the G1 humanoid. It offers 23–43 joint degrees of freedom depending on configuration, depth vision, 3D LiDAR, approximately 3 kg maximum arm payload and about two hours of runtime, with optional computing modules and an 18-month warranty.

G1 EDU

Intelligence Profile

Experiments do not imply factory configuration. Evidence applies only to the named model version.

Learning ApproachOfficial claim
Imitation learning

Learning ApproachOfficial claim
Reinforcement learning
Control ApproachOfficial claim
Hybrid control

Capability Map

ManipulationOfficial claim
Grasping

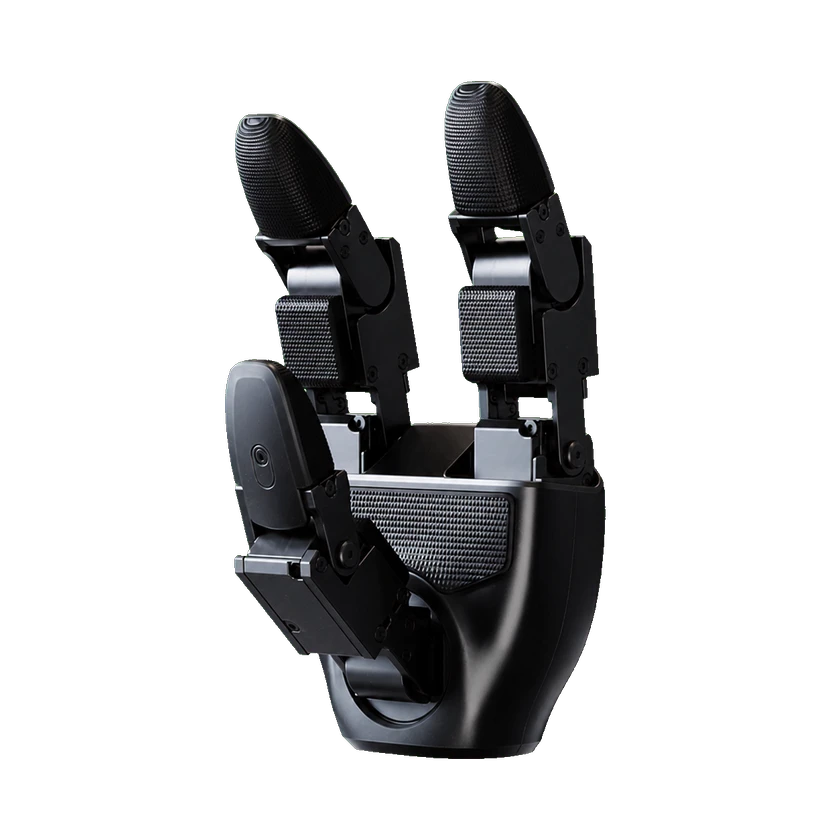
Unitree lists an optional force-control three-finger dexterous hand for G1 EDU and describes force-position hybrid control for precise object operation.

Hardware Specification

Software, export and openness

Companion software
Tobor Harness TH01 teleoperation and Toborverse demonstration data management

Physical Specifications

Arm Span
Approx. 45 cm
Folded Dimensions
690 × 450 × 300 mm
Active degrees of freedom
7 DOF (optional force-control three-fingered hand) + 2 optional wrist DOF
Leg Length (Thigh + Shank)
60 cm
Dimensions (Standing)
1320 × 450 × 200 mm
Total degrees of freedom
23–43

Mobility & Payload

Single-arm Payload
3 kg
Knee Joint Torque
120 N·m

Mechanical and mounting

Controllable DOF per Arm
5 DOF
Depth
20 cm
Height
1.32 m
DOF per Leg
6 DOF
Waist DOF
1 DOF
Waist Rotation Range
-155–155°
Weight
35 kg
Width
45 cm

Mechanical Structure

Cooling System
Local air cooling
Internal Wiring
Full-joint hollow electrical routing
Joint Bearing
Industrial-grade crossed-roller bearings
Joint Encoder
Dual encoder
Joint Motion Range
0–165°
Joint Motion Range
-154–154°
Joint Motion Range
-30–170°
Joint Motion Range
-158–158°
Joint Type
Low-inertia high-speed internal-rotor PMSM

Sensors

Depth Camera
Intel RealSense D435i depth camera
LiDAR
LIVOX MID360 3D LiDAR

Battery and Runtime

Battery Capacity
9 Ah
Battery Swap Support
Smart battery (quick release)
Battery Type
13-string lithium battery
Charger
54 V, 5 A charger
Power Supply
13-string lithium battery
Runtime
2 h

Compute Platform

CPU
8-core high-performance CPU

Interaction and Communication

Communication
Wi-Fi 6, Bluetooth 5.2
Microphone
4-microphone array; noise cancellation and echo cancellation
OTA Update
Supported
Remote Controller
Manual controller
Speaker
5 W speaker

Development and Expansion

Configuration Options
Optional high-computing modules from multiple brands and models, including Orin
Configuration Options
Optional two wrist degrees of freedom; pitch and yaw travel each ±92.5°
Configuration Options
Optional two additional waist degrees of freedom; roll and pitch travel each ±30°
Secondary Development (SDK)
Supported

Commercial Information

Warranty
18 months

Development support

G1

Not open

G1 EDUCurrent model

Open

Development configuration: G1 EDU 29-DOF reference configuration

Exact documented development profile. Hardware, firmware and access conditions are recorded per capability.

Development capabilities

Joint-level controlConditional support
Python SDKConditional support

Model-specific Python SDK2 example. Requires the matching SDK2 firmware, developer access and network setup; disable competing high-level control as documented.

C++ SDKConditional support
ROS 2Conditional support

Official ROS 2 examples; match CycloneDDS, message definitions and the installed firmware.

Position commandsConditional support
Velocity commandsConditional support
PD + feedforward torqueConditional support

Joint-level control, C++ SDK, Position commands, Velocity commands, and PD + feedforward torque · Official C++ low-level example exposes q/dq, PD gains and feedforward torque. Requires the matching hardware and low-level control permissions; not a direct torque-mode claim. The reviewed example targets 29 motors; locked-waist and 23-DOF variants have invalid joints.

Sources · 5

Open source & build resources

Software

Partially available

Examples or supporting tools are available; this does not establish access to the core system.

Hardware design

Not verified

There is not enough verified evidence to establish this dimension.

Build resources

Not verified

There is not enough verified evidence to establish this dimension.

TypeResourceLicenseApplicable versionOpen
CodeUnitree SDK2 Python

GitHub · unitreerobotics/unitree_sdk2_python

Pinned source revision 814556d15970dd2ecf1c9984e845ca02ab07e206. License applies to this repository; hardware, firmware, dependencies and robot access have separate terms.

BSD-3-Clauseg1_edu_29dofOpen GitHub

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
May 13, 2024

Deployment records

Statuses reflect historical reports; subsequent operating conditions are unknown.

Deployment records 1 · Stage unknown 1 · Project actual units · Undisclosed

Partner
Corporación Universitaria del Huila (CORHUILA) · Customer
Primary task
CORHUILA received a Unitree G1 EDU and assigned it to the Mechatronics Engineering program as a platform for engineering education and robotics and AI research. The university describes planned student work on programming routines, computer vision, autonomous systems, and applied robotics; the source does not confirm which activities have begun.Teaching and training support
Location
Huila, Colombia
Started
Undisclosed
Last verified
2026-10-10
Evidence scope

CORHUILA’s own 2026-07-31 report explicitly identifies the received robot as Unitree G1 EDU, says it was officially received on campus, and assigns its coordination to the Mechatronics Engineering program. The source describes planned education and research activities, without confirming their start date or current operating status. The report date is recorded only as publication progress, not as the delivery date. Robot count and payment are undisclosed.
Deployment timeline · 1

  1. CORHUILA reports receiving Unitree G1 EDU
As of the verified evidence; this is not live operating status.2026-10-10

Dataset inclusion

Timeline

  1. Robot release
    G1 EDU
Submit a source or correction