
Unitree Robotics logoUnitree Robotics

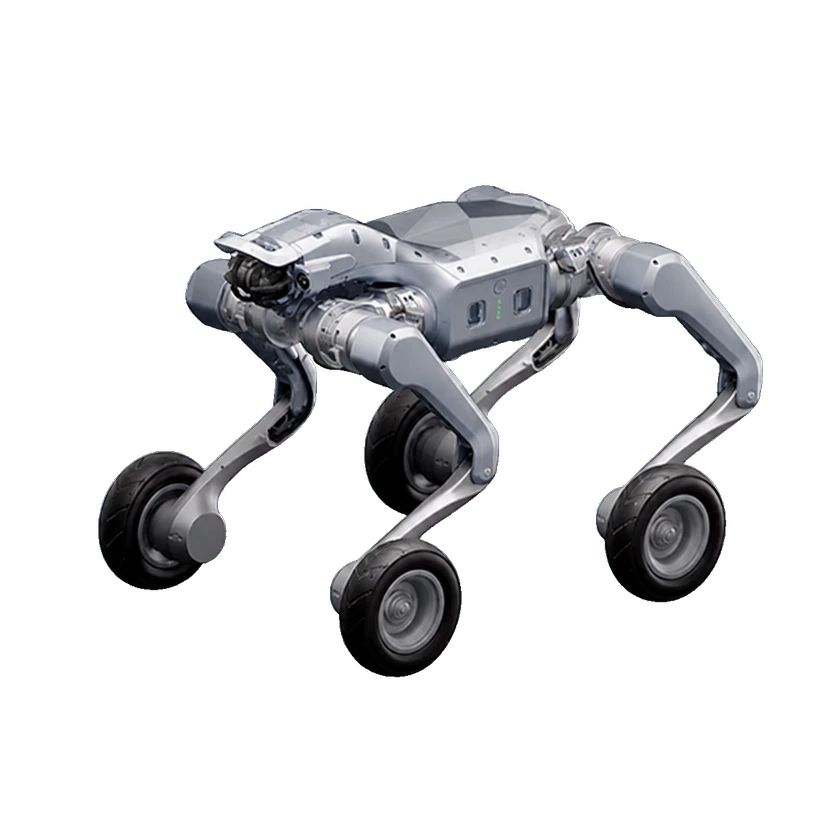
Unitree B1

B1

Price
Price not disclosed
Type
Quadruped Robots
Status
Commercial
Availability
Not disclosed
Purchase
Contact manufacturer
Release Date
Sep 2021
Country/Region
China
50 kg
Weight
0.636 m
Height

B1 is an industrial quadruped robot from Unitree Robotics.

B1

Hardware Specification

Physical Specifications

Folded Dimensions
1202 × 467 × 297 mm
Ingress Protection (IP)
IP68
Dimensions (Standing)
1126 × 467 × 636 mm

Mobility & Payload

Standing Load
80 kg
Step Height
20 cm
Continuous Walking Payload
20 kg

Mechanical and mounting

Height
0.636 m
Weight
50 kg

Sensors

Vision Sensor
Intel RealSense D430 ×5

Battery and Runtime

Battery Capacity
18000 mAh
Battery Capacity
932.4 Wh
Battery Type
Lithium battery
Battery Voltage
51.8 V
Battery Voltage
58.8 V
Battery Total Weight
5 kg
Charging Time
1–2 h
Runtime (No-load)
5 h
Runtime (No-load)
2 h

Compute Platform

Onboard Compute
Intel i5-1135G7
Onboard Compute
Xavier NX ×3

Reliability and environment

Operating temperature
-5–45 °C

Interaction and Communication

External Port
7 ports
External Port
4 ports
External Port
5 ports
External Port
4 ports

Development and Expansion

Expansion Backplane
Supports deployment of multiple sensors for fire-rescue applications.
Payload Power Supply
12 V and 24 V

Development support

B1Current model

Conditional access

The manufacturer explicitly documents developer APIs for B1. Use the model-specific SDK and compatible firmware. Navigation requires the separately delivered navigation stack and applicable sensor configuration.

Development configuration: B1 SDK v3.8.3

Firmware and developer-access prerequisites apply. This SDK profile does not include the optional navigation software.

Development capabilities

Joint-level controlConditional support
Python SDKConditional support
C++ SDKConditional support
Position commandsConditional support
PD + feedforward torqueConditional support
Direct torque commandsConditional support

Only the model-specific SDK revision, compatible firmware/sport package, and authorized low-level developer access. Torque example explicitly sets Kp/Kd=0 and applies commanded torque; no claim about all motor operating ranges or purchased edition.

Documented constraints

  • Navigation interfaces are not part of this public GitHub locomotion SDK; obtain the manufacturer-delivered navigation software and matching LiDAR configuration.
Sources · 4

Open source & build resources

Software

Partially available

Examples or supporting tools are available; this does not establish access to the core system.

Hardware design

Not verified

There is not enough verified evidence to establish this dimension.

Build resources

Not verified

There is not enough verified evidence to establish this dimension.

TypeResourceLicenseApplicable versionOpen
CodeB1 legacy SDK examples and wrappers

GitHub · unitreerobotics/unitree_legged_sdk

Repository license applies to these files. Prebuilt core, dependencies, firmware, hardware and access rights are separate; this link does not assert whole-robot open source.

BSD-3-Clauselegged_sdk_v3_8_3Open GitHub
SimulationB1 ROS robot-description and simulation assets

GitHub · unitreerobotics/unitree_ros

Official ROS repository lists this robot model. These robot-description assets support visualization and simulation; they do not establish published manufacturing drawings or complete onboard software. Match the model configuration before use.

BSD-3-ClauseB1Open GitHub

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Sep 2021

Deployment records

Statuses reflect historical reports; subsequent operating conditions are unknown.

Deployment records 1 · Pilot 1 · Project actual units · Undisclosed

Partner
RobotX AI · Operator
Scenario
Farming
Primary task
Autonomously navigate between almond-tree rows, inspect each canopy, build 3D canopy meshes, and flag possible damage, abnormal fruiting, or broken main branches for review. The source describes a completed field pilot.Unspecified
Location
Undisclosed almond orchard, California, United States
Started
2026-04
Last verified
2026-10-10
Operating sites
1
Evidence scope

RobotX AI reports that it completed a crop-scouting pilot in April 2026 using a Unitree B1 quadruped as the mobile platform. The pilot covered autonomous row navigation, per-tree sensing, 3D canopy reconstruction, and anomaly flagging. The orchard operator and exact site, robot count, payment terms, and any follow-on operation are not disclosed; April 19, 2026 is the report date, not a confirmed activity start date.

Deployment timeline · 1

  1. RobotX AI reports completed Unitree B1 almond-orchard pilot
As of the verified evidence; this is not live operating status.2026-10-10

Timeline

  1. Robot release
    B1
Submit a source or correction