LimX Dynamics logoLimX Dynamics

TRON 1

Price
From USD 15,000
Type
Humanoid Robots · Wheeled Humanoid
Applications
Research & Education · Research Platform
Status
Commercial
Availability
On sale
Purchase
Not disclosed
Release Date
2024
Country/Region
China
Last Verified
2026-08-14
How classification and status work

Category describes physical structure and function; wheels alone do not determine whether a robot is humanoid. Product stage describes demonstrated maturity. Commercial availability describes current access: a commercial product may still be limited to pilot customers. Neither stage nor availability alone proves that a product can be purchased. Unknown facts remain unknown.

0.845 m
Height
20 kg
Weight
10 kg
General Payload
2 h
Runtime

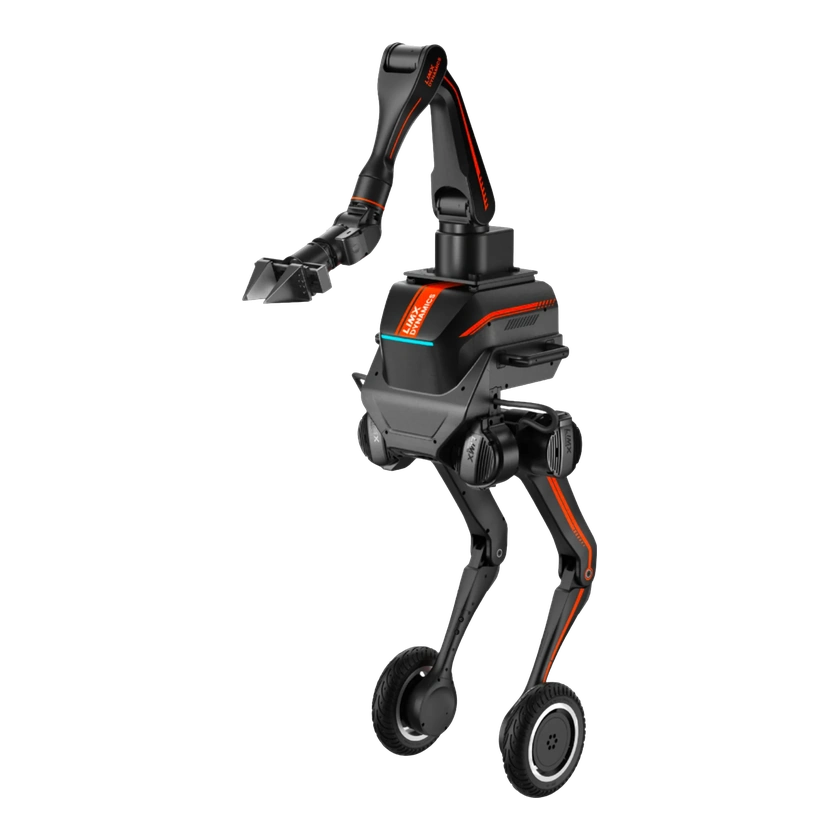
TRON 1 is a LimX Dynamics multi-modal biped research robot edition with interchangeable point-foot, sole, and wheeled configurations. It provides open SDK and hardware interfaces for locomotion control, reinforcement-learning experiments, embodied-intelligence research, and simulation-based development. The compact platform supports Python workflows and common robotics simulators while accepting expansion kits for manipulation, voice interaction, and perception. Its official specifications list a height of 845 mm, maximum payload of 10 kg, and wheeled motion up to 3 m/s.

1 / 1TRON 1

Capability Map

MobilityOfficial claim
Walking

TRON 1 supports point-foot and sole configurations with four-directional movement, turning and stepping.

MobilityOfficial claim
Balance

The sole configuration lists static standing and standing up after a fall.

Hardware Specification

Physical Specifications

Materials
Aluminum Alloy + Industrial Plastic
Dimensions (Standing)
≤ 392mm x 420mm x 845mm

Mobility & Payload

Maximum Grade Angle
≤30°
General Payload
10 kg
Peak Joint Output Torque
Rated 30 N·m; peak 60 N·m
Step Height
≤20 cm
Walking Speed
<1 m/s (point foot)
Walking Speed
<1 m/s (sole)
Walking Speed
Point foot: <1 m/s; sole: <1 m/s; wheeled: ≤3 m/s
Walking Speed
≤3 m/s

Mechanical and mounting

Height
0.845 m
Length
392 mm
Weight
20 kg
Width
420 mm

Mechanical Structure

Actuator Model
6 actuators
Foot
Point-Foot; Sole; Wheeled modular foot ends
Max RPM
15 rad/s
Motor Peak Torque
60 N·m

Sensors

Camera
RGBD Camera
IMU
IMU (provides IMU data)
Sensors
IMU, RGBD camera

Battery and Runtime

Battery Capacity
4.5 Ah
Battery Swap Support
Battery Charging, Quick Battery Swap
Battery Type
Ternary Lithium
Battery Voltage
46.8 V
Charger
Battery Charging Dock
Charging Method
Battery Charging, Quick Battery Swap
Charging Time
<1 h (20%-80%), 1.5 h (100%)
Max Power
1000 W
Runtime
2 h

Compute Platform

CPU
12th Gen Intel i3/16G/512G
Onboard Compute
12th Gen Intel i3 / 16 GB RAM / 512 GB storage

Reliability and environment

Emergency Stop
Remote E-Stop; E-Stop Button
Operating temperature
-5℃ to 40℃

Interaction and Communication

External Port
USB 3.0 *1; GbE *1
Remote Controller
Handheld Remote Controller; communication range 50m

Development and Expansion

Payload Power Supply
24V, Output Power: 100W (Peak 200W)
Secondary Development (SDK)
Secondary Development; SDK; Data Visualization Tools; Data Recording and Playback; Joint Control Algorithm; Simulation Platform

Open source & build resources

Software

Partially available

Examples or supporting tools are available; this does not establish access to the core system.

Hardware design

Not verified

There is not enough verified evidence to establish this dimension.

Build resources

Not verified

There is not enough verified evidence to establish this dimension.

TypeResourceLicenseApplicable versionOpen
SimulationTRON 1 official robot-description and simulation assets

GitHub · limxdynamics/tron1-robot-description

Official robot model files for visualization and simulation. Select the matching variant and configuration; model assets do not establish that manufacturing drawings or the complete onboard system are published.

Apache-2.0TRON 1Open GitHub

Commercial Status

Status
Commercial
Price
From USD 15,000
Release Date
2024

Deployment records

Progress, changes and sources from real-world projects.

Partner
The University of Hong Kong · Integrator
Scenario
Tourism & Culture
Primary task
Provide guided tours to visitors in the Innovation Wing during HKU Information Day.
Location
Tam Wing Fan Innovation Wing, The University of Hong Kong, Hong Kong
Started
Undisclosed
Last verified
2026-10-11

Deployment timeline · 1

  1. CLIO provides guided tours at HKU Information Day
As of the verified evidence; this is not live operating status.2026-10-11
Partner
Refined Robotics · Integrator
Scenario
Warehouse & Logistics
Primary task
Test a TRON 1-powered biped working with Kiki to deliver a package through snow and up stairs to a doorstep for a New Year barbecue.
Location
Undisclosed
Started
Undisclosed
Last verified
2026-10-11

Deployment timeline · 1

  1. LimX reports a TRON 1 and Kiki winter delivery field test
As of the verified evidence; this is not live operating status.2026-10-11
Partner
The University of Hong Kong · Integrator
Scenario
Recreation & Entertainment
Primary task
Test a TRON 1-powered AI photography robot across grass, slopes, and stairs to explore a public robot photography experience.
Location
Shenzhen Bay Talent Park, Shenzhen, China
Started
Undisclosed
Last verified
2026-10-11

Deployment timeline · 1

  1. LimX publishes an update on HKU FotoBot field testing
As of the verified evidence; this is not live operating status.2026-10-11

Timeline

  1. Robot release
    TRON 1
Submit a source or correction