
 Stanford University
Stanford Pupper
Stanford Pupper v1
Price
Unknown
Type
Quadruped Robots
Status
Unknown
Open-source status
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
United States
Last Verified
2026-10-29
Stanford Pupper v1 uses a Raspberry Pi 4, twelve servos, a custom frame and PCB, and a PS4 controller. Follow the 2020 v1 parts, assembly, software and calibration guides.
1 / 1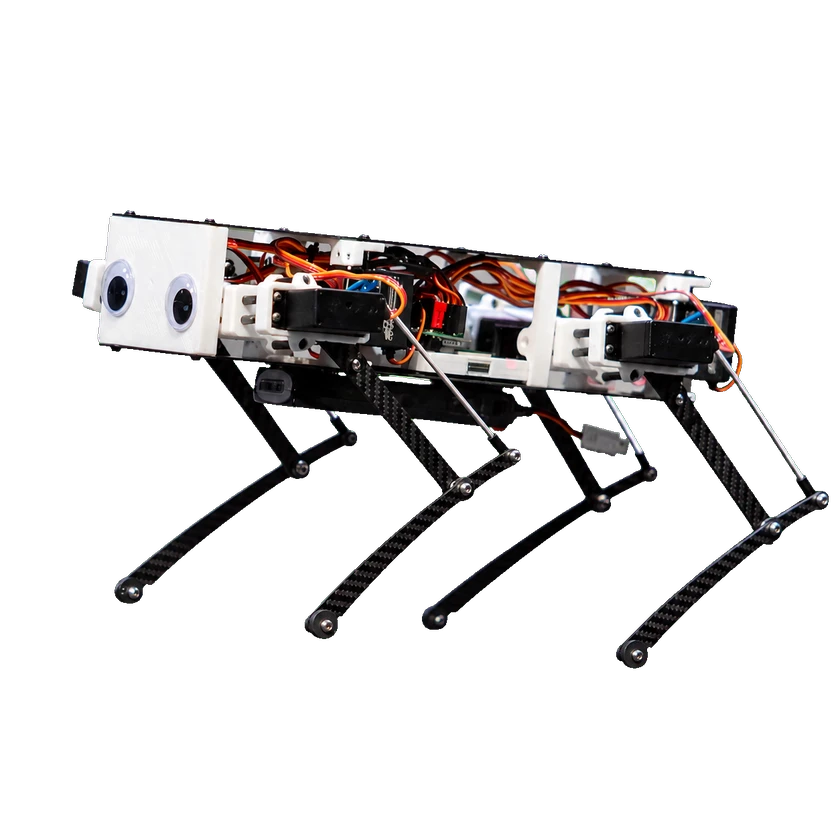
Hardware Specification
Mechanical Structure
Actuator Model
Three servo motors per leg
Compute Platform
Onboard Compute
Raspberry Pi 4
Interaction and Communication
Remote Controller
Wireless PS4 controller
Open source & build resources
Stanford Pupper v1 — assembly guide
Applicable version: Stanford Pupper v1 / 2020Source parts and assemble3D printing: RequiredSoldering: Required
SoftwarePartially available
Examples or supporting tools are available; this does not establish access to the core system.
Hardware designPublicly available
Resources can be accessed; publication alone does not grant reuse rights.
Build resourcesComplete
BOM, structure files and assembly instructions are available for the same version. Check each license before reuse.
Related resources
Featured in: DIY Robots
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Dexterous hands
No specific dexterous hand model confirmed.
Submit a source or correction