
 RealMan Robotics
RealMan RM Series
Price
JPY 2,698,000 · MonotaRO Japan listing, excluding tax and shipping
Type
Robot Arms
Status
Commercial
Availability
On sale
Purchase
Release Date
Unknown
Country/Region
Unknown
63.85 cm
Reach
±0.05 mm
Repeatability
7.3 kg
Weight
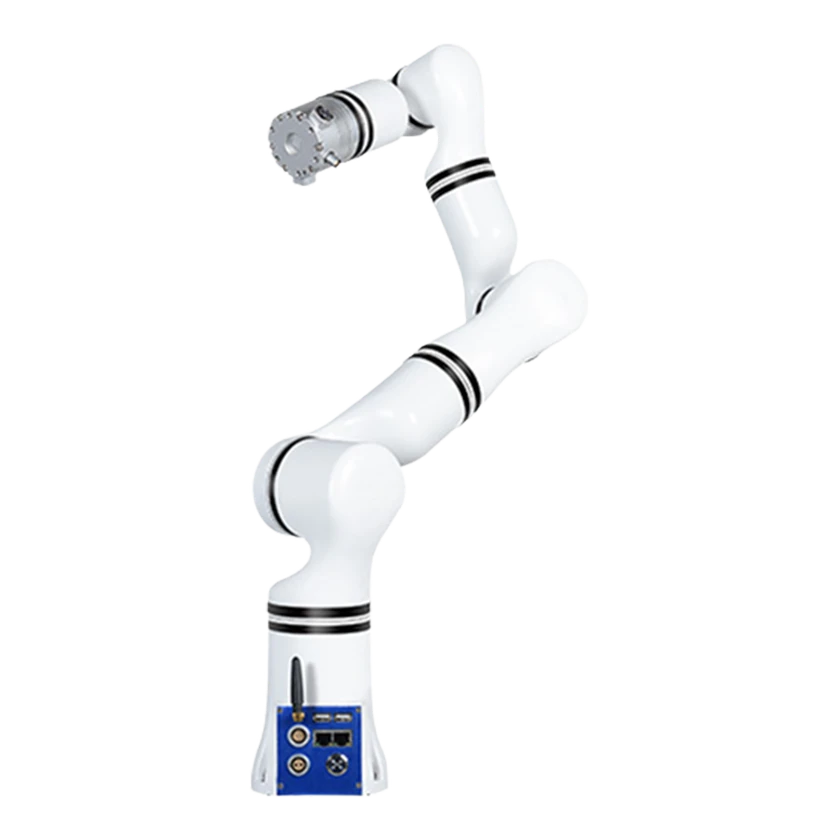
The RM65-6F is RealMan’s six-axis arm with a separate wrist-mounted force/torque sensor. It weighs 7.3 kg and has a 5 kg rated payload, a 638.5 mm reach and ±0.05 mm repeatability. The sensor measures forces and torques for contact-sensitive tasks.
Hardware Specification
Physical specifications and power
Mounting or wearing method
Any installation angle per manufacturer specifications
Typical power consumption
≤150 W
Force, touch and feedback
Force measurement range
200 N
Torque measurement range
7 N·m
Degrees of freedom and drive
Arm Specifications
Humanoid configuration
Arm Specifications
J1–J3 hard brakes, J4–J6 soft brakes
Mechanical joint count
6
Materials
Aluminium alloy and ABS
Mobility & Payload
Single-arm Payload
5 kg
Max Speed
≤1.8 m/s
Reach
63.85 cm
Degrees of Freedom
Controllable DOF per Arm
6 DOF
Weight
7.3 kg
Electrical and integration
Joint Motion Range
-178 … 178 °
Joint Motion Range
-130 … 130 °
Joint Motion Range
-135 … 135 °
Joint Motion Range
-178 … 178 °
Joint Motion Range
-128 … 128 °
Joint Motion Range
-360 … 360 °
Operating voltage
24 V
Peak power
≤600 W
Sensors
Force/Torque Sensor
Separate six-axis force/torque sensor
Battery and Runtime
Max Power
≤200 W
Performance and tasks
Repeatability
±0.05 mm
Reliability and environment
Operating humidity
25–85 %RH
Operating temperature
0–45 °C
Interaction and Communication
External Port
Six-pin tool port: RS485, two digital I/O channels and programmable 0/12/24 V output
Development and Expansion
Mounting Dimensions
11 cm
Commercial Status
Status
Commercial
Price
JPY 2,698,000 · MonotaRO Japan listing, excluding tax and shipping
Release Date
Unknown
Related Entities
No related products recorded yet.
Submit a source or correction