
 RealMan Robotics
RealMan RM Series
Price
Price not disclosed
Type
Robot Arms
Status
Commercial
Availability
Not disclosed
Purchase
Release Date
Unknown
Country/Region
Unknown
62.7 cm
Reach
±0.05 mm
Repeatability
7.3 kg
Weight
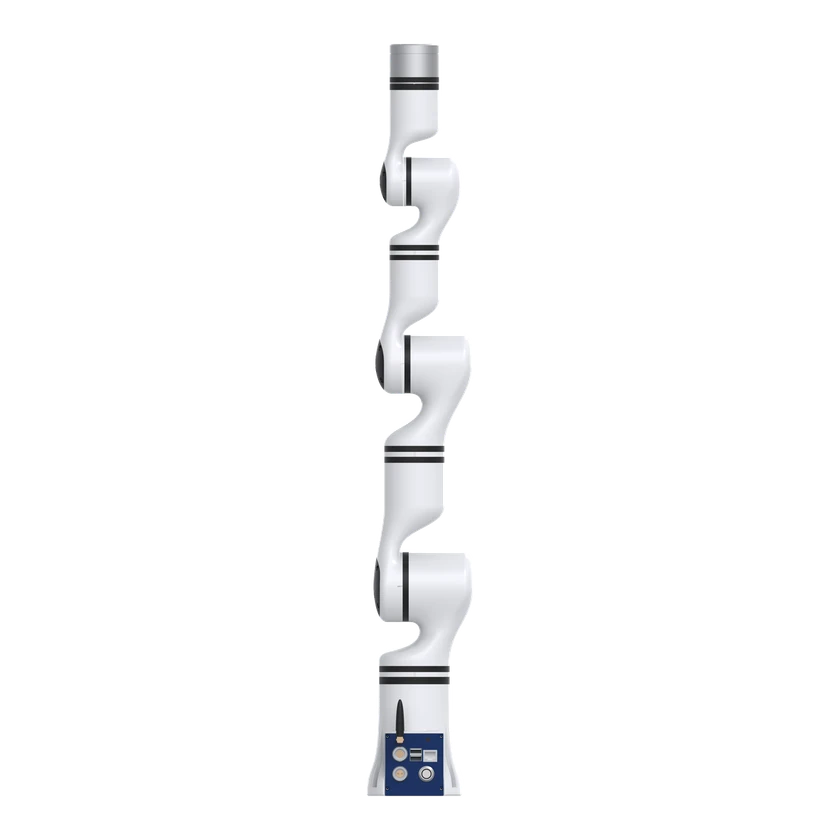
The RM65-6FB is RealMan’s six-axis arm with an integrated end-link force/torque sensor. It weighs 7.3 kg and has a 5 kg rated payload, a 627 mm reach and ±0.05 mm repeatability. It is designed for tasks that require force feedback on contact.
Hardware Specification
Physical specifications and power
Mounting or wearing method
Any installation angle per manufacturer specifications
Force, touch and feedback
Force measurement range
200 N
Torque measurement range
7 N·m
Degrees of freedom and drive
Arm Specifications
Humanoid configuration
Arm Specifications
J1–J3 hard brakes, J4–J6 soft brakes
Mechanical joint count
6
Materials
Aluminium alloy and ABS
Mobility & Payload
Single-arm Payload
5 kg
Max Speed
≤1.8 m/s
Reach
62.7 cm
Degrees of Freedom
Controllable DOF per Arm
6 DOF
Weight
7.3 kg
Electrical and integration
Joint Motion Range
-178 … 178 °
Joint Motion Range
-130 … 130 °
Joint Motion Range
-135 … 135 °
Joint Motion Range
-178 … 178 °
Joint Motion Range
-128 … 128 °
Joint Motion Range
-360 … 360 °
Operating voltage
24 V
Peak power
≤600 W
Rated power
≤150 W
Sensors
Force/Torque Sensor
Integrated six-axis force/torque sensor
Performance and tasks
Repeatability
±0.05 mm
Reliability and environment
Operating humidity
25–85 %RH
Operating temperature
0–45 °C
Interaction and Communication
External Port
Six-pin tool port: RS485, two digital I/O channels and programmable 0/12/24 V output
Development and Expansion
Mounting Dimensions
10.7 cm
Commercial Status
Status
Commercial
Price
Price not disclosed
Release Date
Unknown
Related Entities
No related products recorded yet.
Submit a source or correction