RealMan Robotics logoRealMan Robotics

RealMan RM Series

Price
Price not disclosed
Type
Robot Arms
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
Unknown
63.85 cm
Reach
±0.05 mm
Repeatability
7.9 kg
Weight

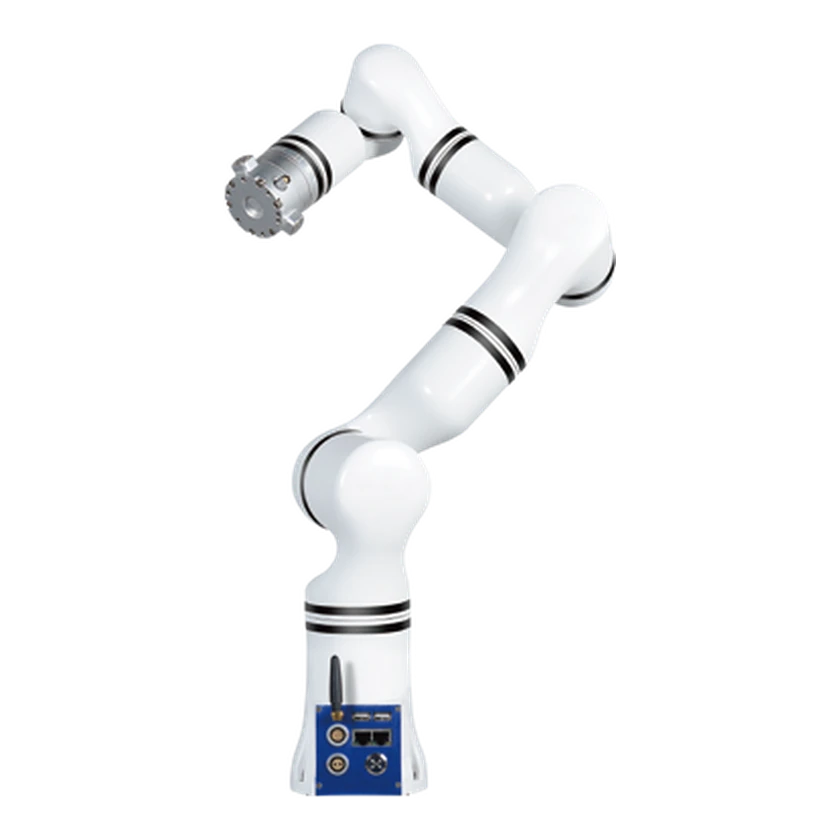
The RM75-6F is a seven-axis standalone arm in RealMan’s RM series, with a separate six-axis force/torque sensor at the wrist. It has a 5 kg rated payload, a 638.5 mm reach and a 7.9 kg arm weight.

RM75-6F

Configurations

Separate six-axis force/torque sensor

Communication and control

Communication interface
Ethernet
Communication interface
Wi-Fi
Communication interface
RS485
Communication interface
Bluetooth
Communication interface
USB
Control mode
Hand-guided teaching

Software and resources

ROS compatibility
ROS 1 Melodic
ROS compatibility
ROS 1 Noetic
ROS compatibility
ROS 2 Humble

Joint specifications

Controller integration
Integrated controller

Hardware Specification

Physical specifications and power

Mounting or wearing method
Any mounting angle

Software, export and openness

License and usage terms
Apache-2.0 (ROS 1 / ROS 2)
SDK versions and download links
ROS 1 Melodic / Noetic · ROS 2 Humble

Force, touch and feedback

Force measurement range
200 N
Torque measurement range
7 N·m

Physical Specifications

Materials
Aluminium alloy

Mobility & Payload

Single-arm Payload
5 kg
Max Speed
≤1.8 m/s
Reach
63.85 cm

Degrees of Freedom

Controllable DOF per Arm
7 DOF
Weight
7.9 kg

Mechanical Structure

Joint Motion Range
-178–178 °
Joint Motion Range
-130–130 °
Joint Motion Range
-178–178 °
Joint Motion Range
-135–135 °
Joint Motion Range
-178–178 °
Joint Motion Range
-128–128 °
Joint Motion Range
-360–360 °
Operating voltage
24 V

Sensors

Force/Torque Sensor
Separate six-axis force/torque sensor

Performance and tasks

Repeatability
±0.05 mm

Reliability and environment

IP rating
IP54
Operating humidity
25–85 %RH
Operating temperature
0–45 °C

Development and Expansion

Secondary Development (SDK)
RM_API2

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction